
Price
Unknown
Type
Mobile Manipulators · Research Mobile Manipulator
Applications
Research & Education · Developer Kit / Research & Education · Research Platform
Status
Prototype
Availability
Discontinued
Purchase
Not disclosed
Release Date
2008
Country/Region
United States
Last Verified
2026-07-02
4–8 h
Runtime
2 m/s
Walking Speed
98 kg
Weight
1.2 m
Height

PR1 is Stanford's mobile manipulation platform with differential wheels and an inactive status.
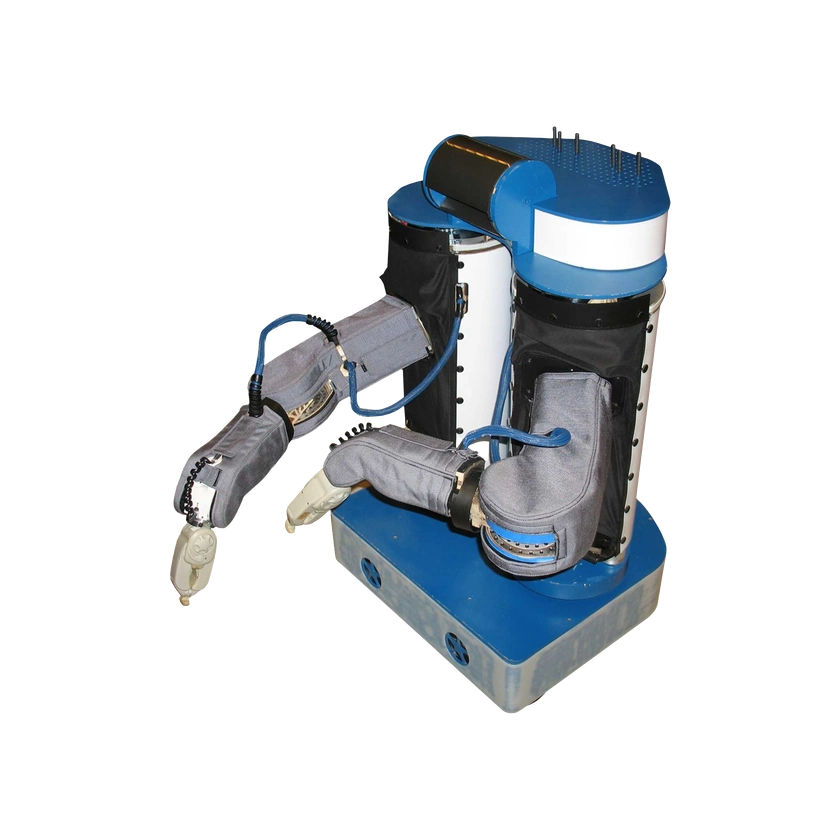
1 / 1PR1

Capability Map

ManipulationDemonstrated
Pick and place

Stanford's PR1 project page documents a PR1 video unloading a dishwasher, providing an observed pick-and-place task demonstration.

Hardware Specification

Degrees of freedom and drive

Arm Specifications
4-DOF arm + 3-DOF wrist + 1-DOF gripper
Active degrees of freedom
1 DOF per gripper

Mobility & Payload

Single-arm Payload
5 kg per arm
Max Speed
7.2 km/h
Walking Speed
2 m/s

Mechanical and mounting

Controllable DOF per Arm
7 DOF per arm
Head DOF
1 DOF
Height
1.2 m
Length
60 cm
Waist DOF
2 DOF
Weight
98 kg
Width
64 cm

Electrical and integration

Rated power
1 kW continuous

Battery and Runtime

Max Power
2 kW peak
Power Supply
2 kW peak; 1 kW continuous
Runtime
4–8 h

Compute Platform

Onboard Compute
Two Pentium M small form-factor computers

Commercial Status

Status
Prototype
Price
Unknown
Release Date
2008

Timeline

  1. Robot release
    PR1
Submit a source or correction