HeymanDex logoHeymanDex

Dasheng 1

Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Commercial
Availability
On sale
Release Date
Sep 4, 2026
Country/Region
China
Latest parameter verification
2026-10-30
11 DOF
Active degrees of freedom
Approximately 1 kg
Hand weight
4
Finger count

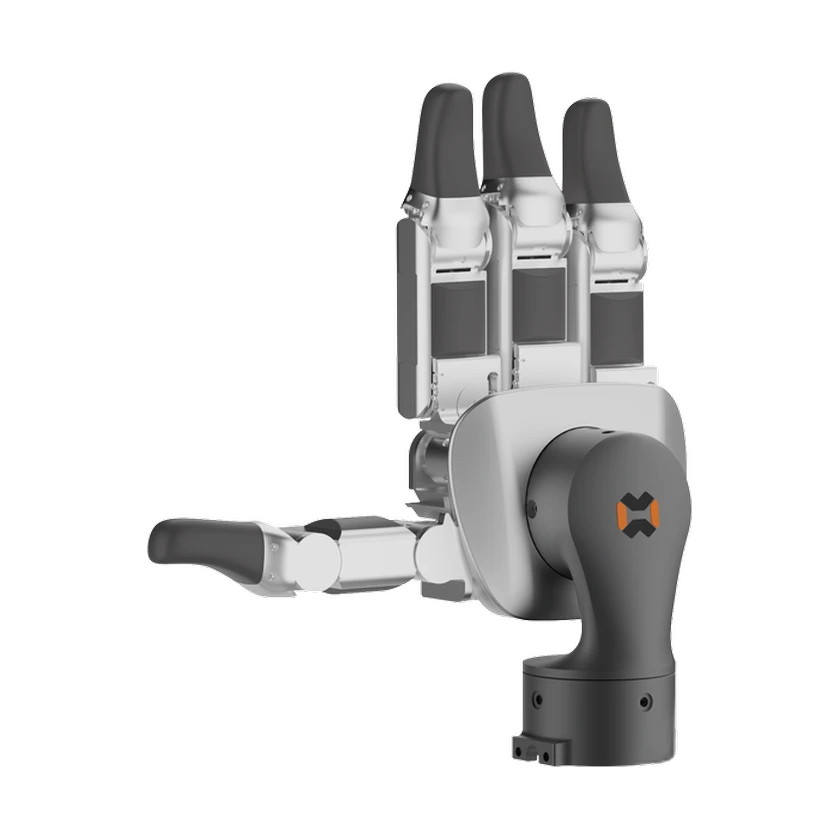
Dasheng 1 (SG100) is a four-finger industrial reconfigurable dexterous hand from HeymanDex for humanoid robots and robotic arms. Its fingers can rotate through a wide range and change their relative positions: fingertips pinch small parts, opposing fingers clamp irregular workpieces, and an extended-stroke configuration grasps larger objects. The official product page lists 11 active degrees of freedom, a maximum grip stroke of 15 cm, and a single-hand hook-grip payload of at least 24 kg. The four-finger approach aims to cover common five-finger grasping tasks while controlling cost.

1 / 1Dasheng 1

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
4
Active degrees of freedom
11 DOF

Motion and coordination

Coordination architecture
Independent control of all joints

Mechanical and mounting

Grip stroke
15 cm
Hand weight
Approximately 1 kg

Electrical and integration

Operating voltage
24–80 V
Peak power
Approximately 180 W

Sensors

Tactile Sensor
Optional tactile sensors

Software and resources

Teleoperation support
Supported

Performance and tasks

Repeatability
≤ 0.03 mm

Development and Expansion

Integration Interface
Supports hardware and software integration with robot arms, humanoid robots, and other robot platforms.
Operating Modes
Dexterous-hand mode; opposing-finger mode; long-stroke mode; four-finger mode
Workflow Integration
Supports integration with robot simulation and real-world control systems for simulation validation, real-data collection, and policy deployment.

Configurations

SG100

Communication and control

Communication interface
RS485

Variant not bound

RS485 / CAN FD 根据配置;官方未披露具体配置与接口的对应关系。

Communication interface
CAN FD

Variant not bound

RS485 / CAN FD 根据配置;官方未披露具体配置与接口的对应关系。

Software and resources

SDK languages
Python
SDK languages
C++
Simulation formats
URDF
Simulation formats
MuJoCo

Dasheng 1 — optional tactile sensing

Sensing

Has tactile sensing
Supported (optional)

Commercial Status

Status
Commercial
Price
Price not disclosed
Release Date
Sep 4, 2026
Submit a source or correction