Osaka University logoOsaka University

Geminoid HI

Geminoid HI-1

Price
Unknown
Type
Humanoid Robots · Compact Humanoid
Applications
Research & Education · Research Platform
Status
Development ended
Availability
Discontinued
Purchase
Not disclosed
Release Date
2006
Country/Region
Japan
50 DOF
Total degrees of freedom
1.4 m
Height
60 kg
Weight

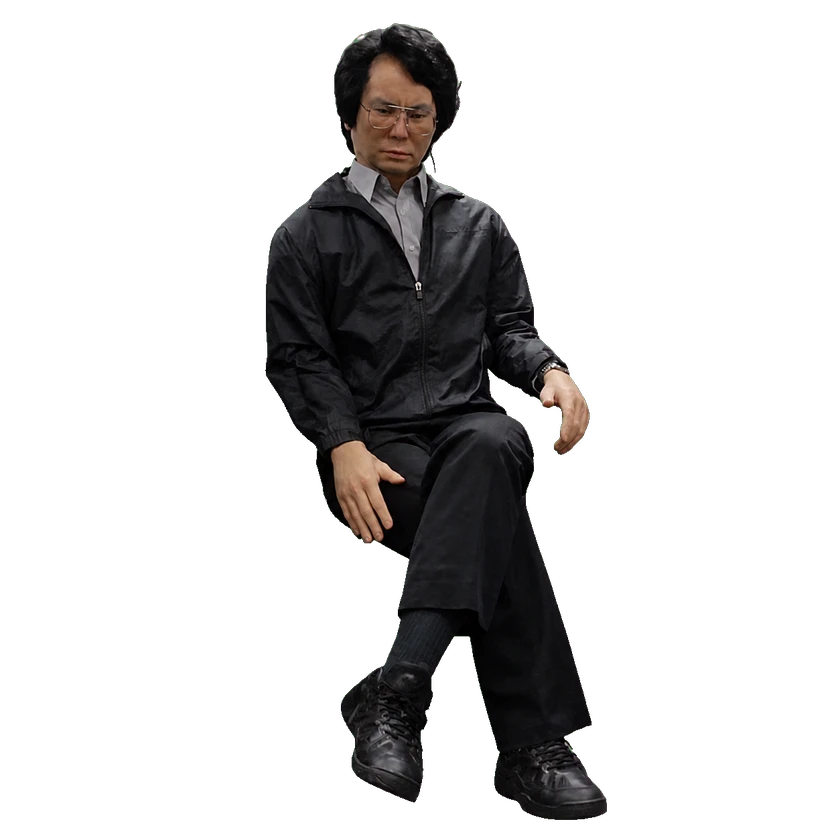
Geminoid HI-1 is a teleoperated android modeled on Hiroshi Ishiguro. Developed for research on human presence and human-robot interaction, it reproduces the operator’s voice, head movements, facial appearance, and selected human behaviors through an external control system.

Geminoid HI-1

Intelligence Profile

Experiments do not imply factory configuration. Evidence applies only to the named model version.

Learning ApproachOfficial claim
Teleoperation
Capability Map

InteractionOfficial claim
Human collaboration

Hardware Specification

Physical Specifications

Materials
Silicone rubber for skin. Fiber-reinforced plastic for skull. Metal and plastic for internal frame and mechanisms. Urethane foam for shape support. Natural and synthetic hair.
Posture Height
140 cm sitting posture height
Total degrees of freedom
50 DOF

Mechanical and mounting

Head DOF
13 DoF head
Height
1.4 m
Waist DOF
15 DoF torso
Weight
60 kg
Width
100 cm

Mechanical Structure

Actuator Model
50 pneumatic actuators

Sensors

Sensors
Tactile sensors
Tactile Sensor
Tactile sensors

Battery and Runtime

Power Supply
External air compressor and valve power system

Compute Platform

Onboard Compute
External teleoperation control unit and air valve system
Operating System
Windows OS
Software Algorithm
Custom robot control and teleoperation software

Interaction and Communication

Remote Controller
External teleoperation control unit
Voice Interaction
Voice reproduction through teleoperation

Development and Expansion

Teleoperation
Remote teleoperation

Commercial Status

Status
Development ended
Price
Unknown
Release Date
2006

Deployment activity

Deployment started

Geminoid HI-1 begins a public café field study

The peer-reviewed study reports that Geminoid HI-1 was placed in Café CUBUS at the Ars Electronica Center from 2009-08-10 to 2009-08-30. The robot was observed in a natural public setting under different interaction conditions, including teleoperation, to study visitors’ unscripted responses. The recorded date is the documented installation start, not the paper’s publication date.

Deployment records

Statuses reflect historical reports; subsequent operating conditions are unknown.

Deployment records 1 · Pilot 1

Partner
Ars Electronica Futurelab · Operator
Primary task
Place Geminoid HI-1 in the Café CUBUS public café and later the Ars Electronica Center exhibition space; use remote operation and observed visitor interactions to study human–android responses in an everyday public setting.Companionship and social interaction
Location
Café CUBUS and exhibition space, Ars Electronica Center, Linz, Austria.
Started
2009-08-10
Last verified
2026-10-14
Robots deployed
1
Operating sites
1
Evidence scope

Ars Electronica Futurelab identifies the exact Geminoid HI-1 and says it was installed as a guest in Café CUBUS and in the exhibition space, remotely operated to study reactions of visitors and café guests. A peer-reviewed field-study paper dates the café installation to 2009-08-10 through 2009-08-30. This was a public-space research field study, not a commercial customer service deployment. One exact robot and one facility are documented; payment and current operating status are unknown.

Deployment timeline · 1

  1. Geminoid HI-1 begins a public café field study
As of the verified evidence; this is not live operating status.2026-10-14

Timeline

  1. Robot release
    Geminoid HI-1
Submit a source or correction