
 Festo
BionicSoftHand
Price
Unknown
Type
Components · Dexterous Hands
Status
Prototype
Availability
Not released
Purchase
Not disclosed
Release Date
Jul 23, 2020
Country/Region
Germany
Last Verified
2026-09-12
1.295 kg
Weight
5
Finger count
Pneumatic gripper for the BionicMobileAssistant, combining compact valve technology, sensors, electronics and mechanical components with tactile force sensing, a two-degree-of-freedom wrist, depth vision and a neural network.
1 / 1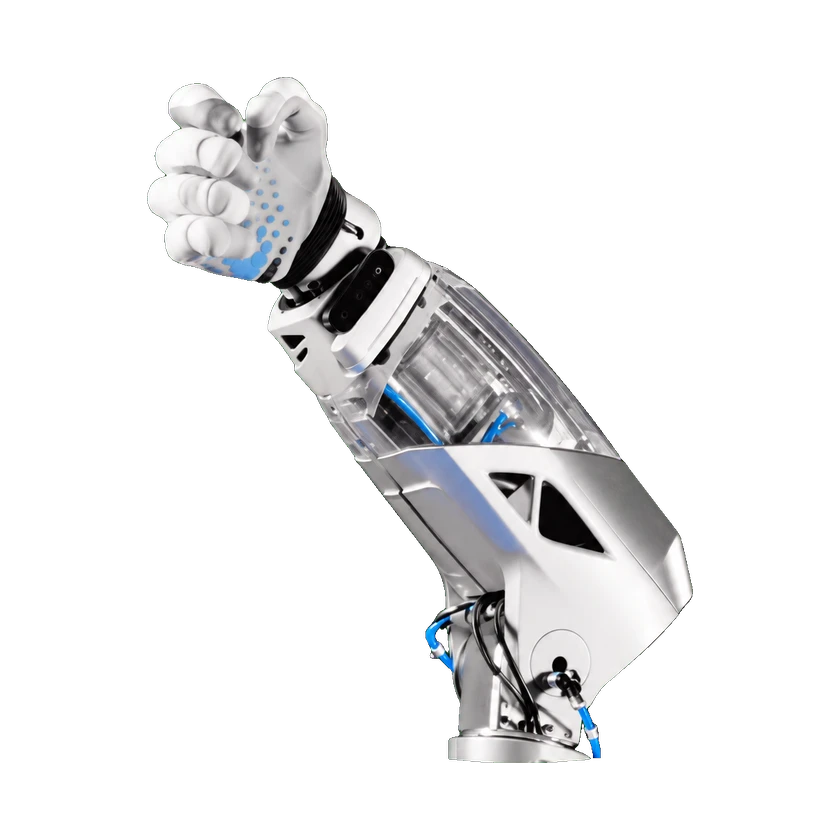
Hardware Specification
Physical Specifications
Actuator technology
Pneumatic
Frame Material
3D-printed polyamide housing and wrist
Materials
Flexible bellows and 3D textile coat
Materials
EPDM bellows, approximate Shore hardness 45
Materials
Epoxy resin airflow plate
Surface Fabric
Technical 3D-knitted textile fingers
Total degrees of freedom
Including wrist: 11
Transmission mechanism
Pneumatic bellows
Motion and coordination
Coordination architecture
Twelve VTEM piezo cartridges, twenty-four proportional piezo valves
Energy domain
Pneumatic energy
Hand Payload
Orientation dependent: ≤4 kg
Mechanical and mounting
Weight
1.295 kg
Mechanical Structure
Actuator Model
One DRVS semi-rotary drive and three DSNU/DSNU-S cylinders
Dexterous Hand
BionicSoftHand dexterous hand
Dexterous Hand Model
BionicSoftHand
End-Effector
Pneumatic gripper
Joint Motion Range
Index lateral swivel: ≈45 °
Joint Motion Range
Thumb lateral swivel: ≈90 °
Joint Sensor Type
Ten finger-position bending sensors, two segments per finger
Sensors
Attitude Sensor
One inertial sensor
Camera
One Intel RealSense depth camera inside wrist for object detection
Depth Camera
Inside the wrist for object detection
Force/Torque Sensor
Fingertips, palm and outer sides
Sensors
Fourteen pressure sensors in airflow plate
Tactile Sensor
Glove with 113 tactile force sensors distributed over fingertips, palm and outside of hand
Vision Sensor
Depth vision for partially obscured objects
Battery and Runtime
Power Supply
Compressed air: 5 bar for hand, 6 bar for swivel modules
Compute Platform
AI Model
Neural network
Software Algorithm
Neural-network object detection trained with data augmentation
Safety and Protection
Human-Robot Safety
Direct human-robot interaction
Safety System
Pneumatic operation for safe interaction
Interaction and Communication
Tactile Feedback
Adapts gripping force to the object
Visual Recognition
Detects partially obscured objects
Development and Expansion
Integration Interface
BionicMobileAssistant
Operating Modes
Adaptive grasping with tactile and visual feedback
Workflow Integration
Assembly and intralogistics
Commercial Status
Status
Prototype
Price
Unknown
Release Date
Jul 23, 2020
Related Entities
Submit a source or correction