
BionicSoftHand
Sensing
Has tactile sensing
Supported
 Festo
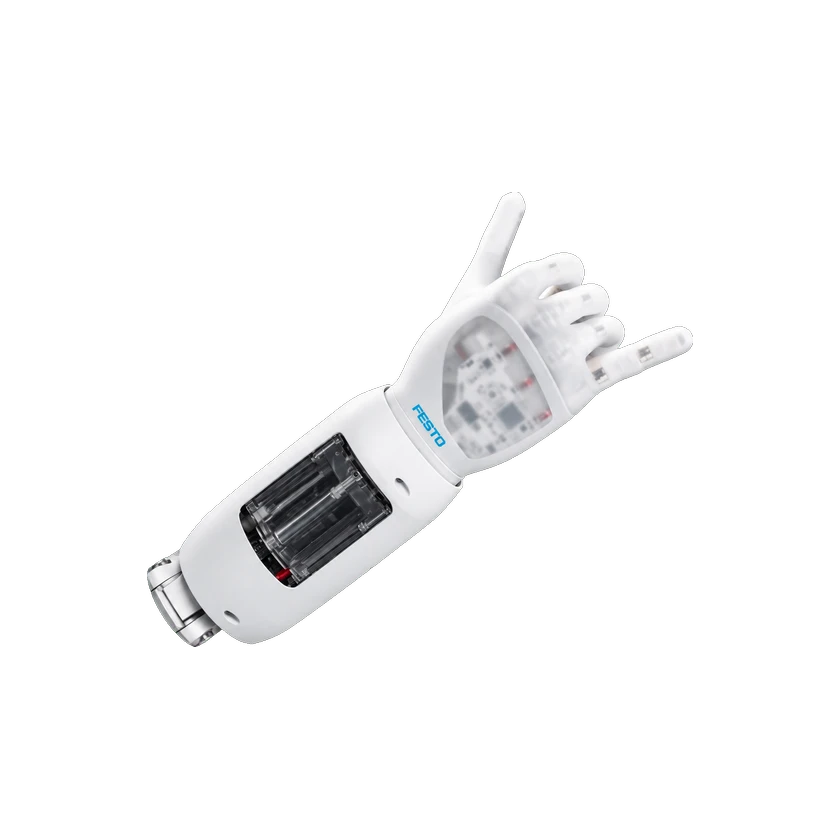
BionicSoftHand is a pneumatic soft robotic hand developed by Festo with air-chamber bellows fingers enclosed in a 3D textile of elastic and high-strength threads to direct expansion and motion. Festo’s research describes reinforcement learning in a digital-twin virtual environment for rotating a twelve-sided object until a specified face points upward, combining soft mechanics with learned control.
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
Version-specific official brochure; v2 total includes wrist
No related products recorded yet.