
 Festo
BionicSoftHand
가격
알 수 없음
유형
구성 요소 · 다관절 손
상태
Prototype
구매 가능 여부
미출시
구매 방식
미공개
공개일
2019년
국가/지역
독일
최근 확인
2026-09-12
5
손가락 수
Pneumatic robot hand with artificial intelligence. Festo presented the earlier version in 2019 for human-robot collaboration and reinforcement-learning research.
1 / 1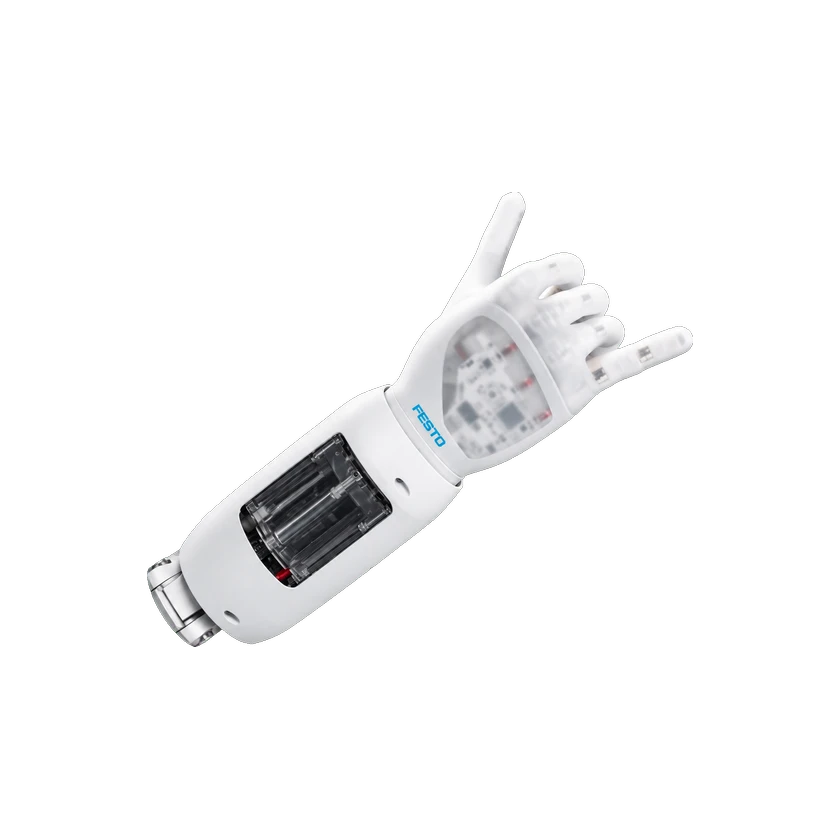
하드웨어 사양
물리적 사양
액추에이터 기술
Pneumatic
프레임 소재
Housing made from 3D printing material
소재
Flexible bellows and 3D textile coat
소재
EPDM bellows, approximate Shore hardness 45
소재
Silicone skin
소재
Stereolithography resin airflow plate
표면 소재
Dyneema textile covering
총 자유도
12 DOF
전달 메커니즘
Pneumatic bellows
동작 및 협응
협응 아키텍처
Twelve VTEM piezo cartridges, twenty-four proportional piezo valves
에너지 영역
Pneumatic energy
손 적재량
Orientation dependent: ≤4 kg
기계 및 장착
길이
Each long finger: 9.8 cm
길이
Little finger: 7.9 cm
장착 인터페이스
Digital valve terminal mounted directly on the hand
기계 구조
액추에이터 모델
Two EV pneumatic swivel modules for thumb and index lateral motion
다관절 손
BionicSoftHand dexterous hand
다관절 손 모델
BionicSoftHand
엔드 이펙터
Pneumatic gripper
관절 센서 유형
Ten inertial sensors in fingers
센서
자세 센서
One inertial sensor on back of hand
카메라
One Leap Motion depth-sensing camera for computer vision
깊이 카메라
Depth-sensing camera for computer vision
센서
Fourteen pressure sensors in airflow plate
촉각 센서
Fifteen tactile force sensors in fingers
배터리 및 작동 시간
전원 공급
Compressed air: 3.5 bar for fingers, 6.0 bar for swivel modules
컴퓨팅 플랫폼
AI 모델
Reinforcement learning
소프트웨어 알고리즘
Reinforcement learning in parallel digital-twin simulations, transferred to physical hand
안전 및 보호
인간-로봇 안전
Direct human-robot interaction
안전 시스템
Pneumatic operation for safe interaction
상호작용 및 통신
외부 포트
One supply-air tube and one exhaust-air tube
시각 인식
Computer vision from a depth camera
개발 및 확장
통합 인터페이스
BionicSoftArm
작동 모드
Goal-directed reinforcement learning
상용화 상태
상태
Prototype
가격
알 수 없음
공개일
2019년
관련 항목
출처 또는 수정 제안 보내기