
Price
Price not disclosed
Type
Quadruped Robots
Status
Commercial
Availability
Not disclosed
Purchase
Contact manufacturer
Release Date
2019
Country/Region
China
13 kg
General Payload
2.5–4.6 h
Runtime
0.6 m
Height

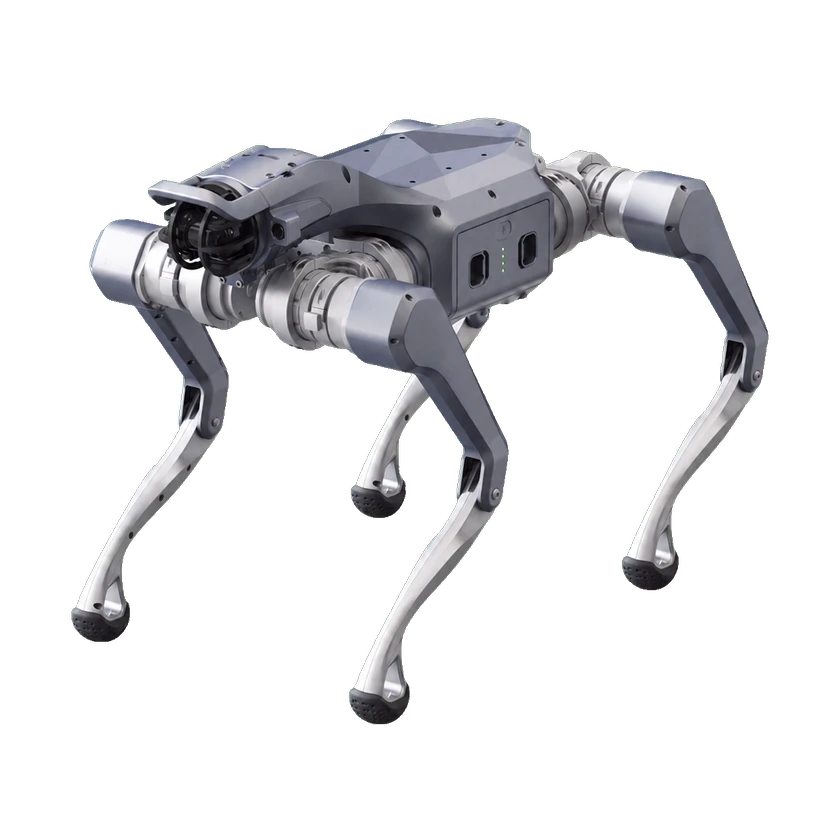
Aliengo is an industrial multifunctional quadruped robot from Unitree Robotics.

Aliengo

Hardware Specification

Physical Specifications

Folded Dimensions
0.6 × 0.31 × 0.15 m
Dimensions (Standing)
0.65 × 0.31 × 0.6 m
Total degrees of freedom
12 DOF

Mobility & Payload

Maximum Grade Angle
25 °
Max Speed
1.5 m/s
General Payload
13 kg

Mechanical and mounting

Height
0.6 m

Mechanical Structure

Joint Encoder
One motor encoder and one output-end encoder per joint

Sensors

Camera
One visual-odometer camera set with fisheye lens
Depth Camera
Two depth-camera sets; 1280 × 720 maximum depth resolution and 0.11 m minimum sensing depth.
Foot Force Sensor
4 count
LiDAR
Single-line or multi-line LiDAR optional

Battery and Runtime

Battery Capacity
12600 mAh
Battery Capacity
317.52 Wh
Battery Voltage
25.2 V
Battery Voltage
29.4 V
Battery Total Weight
2740 g
Charging Power
352.8 W
Runtime
2.5–4.6 h

Compute Platform

Operating System
Ubuntu
Operating System
Ubuntu-ROS

Safety and Protection

Safety System
Wireless emergency-stop protection and fall protection.
Safety System
Low-voltage, over-temperature, short-circuit, and overcharge alarms.

Interaction and Communication

External Port
2 × Ethernet, 2 × USB 3.0, 1 × USB 2.0, and 1 × RS485
Video Transmission
HD real-time image transmission supported.

Development and Expansion

Operating Modes
Low-level interface permits sensor-data reading and single-motor or single-leg control.
Payload Power Supply
5 V, 12 V, 19 V, and battery output (24–30 V)
Secondary Development (SDK)
High-level software control interface supports C/C++ and ROS.
Secondary Development (SDK)
Walking, running, and other high-performance gait development supported.

Commercial Information

Availability
Official store lists Aliengo as ready to ship/contact for pricing; stock wording may vary.

Development support

AliengoCurrent model

Conditional access

The manufacturer explicitly documents developer APIs for AlienGo. Use the model-specific SDK and compatible firmware. Navigation requires the separately delivered navigation stack and applicable sensor configuration.

Development configuration: AlienGo SDK v3.8.4

Firmware and developer-access prerequisites apply. This SDK profile does not include the optional navigation software.

Development capabilities

Joint-level controlConditional support
Python SDKConditional support
C++ SDKConditional support
Position commandsConditional support
PD + feedforward torqueConditional support
Direct torque commandsConditional support

Only the model-specific SDK revision, compatible firmware/sport package, and authorized low-level developer access. Torque example explicitly sets Kp/Kd=0 and applies commanded torque; no claim about all motor operating ranges or purchased edition.

Documented constraints

  • Navigation interfaces are not part of this public GitHub locomotion SDK; obtain the manufacturer-delivered navigation software and matching LiDAR configuration.
Sources · 4

Open source & build resources

Software

Partially available

Examples or supporting tools are available; this does not establish access to the core system.

Hardware design

Not verified

There is not enough verified evidence to establish this dimension.

Build resources

Not verified

There is not enough verified evidence to establish this dimension.

TypeResourceLicenseApplicable versionOpen
CodeAlienGo legacy SDK examples and wrappers

GitHub · unitreerobotics/unitree_legged_sdk

Repository license applies to these files. Prebuilt core, dependencies, firmware, hardware and access rights are separate; this link does not assert whole-robot open source.

BSD-3-Clauselegged_sdk_v3_8_4Open GitHub
SimulationAlienGo ROS robot-description and simulation assets

GitHub · unitreerobotics/unitree_ros

Official ROS repository lists this robot model. These robot-description assets support visualization and simulation; they do not establish published manufacturing drawings or complete onboard software. Match the model configuration before use.

BSD-3-ClauseAlienGoOpen GitHub

Commercial Status

Status
Commercial
Price
Price not disclosed
Release Date
2019

Deployment records

Statuses reflect historical reports; subsequent operating conditions are unknown.

Deployment records 1 · Customer test 1 · Project actual units · Undisclosed

Partner
Birmingham City University · Operator
Primary task
Conduct semi-autonomous under-canopy surveys and collect location-tagged imagery for forest-health monitoring, including deadwood and burrows. The study reports field experiments, not routine forest-service operation.Locomotion testing
Location
Sherwood Forest, Nottinghamshire, England, United Kingdom
Started
Undisclosed
Last verified
2026-10-11
Operating sites
1
Evidence scope

The study identifies the Unitree Aliengo as its ground robot and documents field trials in Sherwood Forest. Publication on 2022-07-23 is recorded as a report milestone, not the deployment start. The exact trial dates, customer procurement, payment, robot count and current operating status are not stated.

Deployment timeline · 1

  1. Sherwood Forest field-trial results published
As of the verified evidence; this is not live operating status.2026-10-11

Timeline

  1. Robot release
    Aliengo
Submit a source or correction