
MobilitätOffizielle Angabe
Gehen
The official DARwIn-OP page lists a default walking speed and user-modifiable gait.
 Robotis
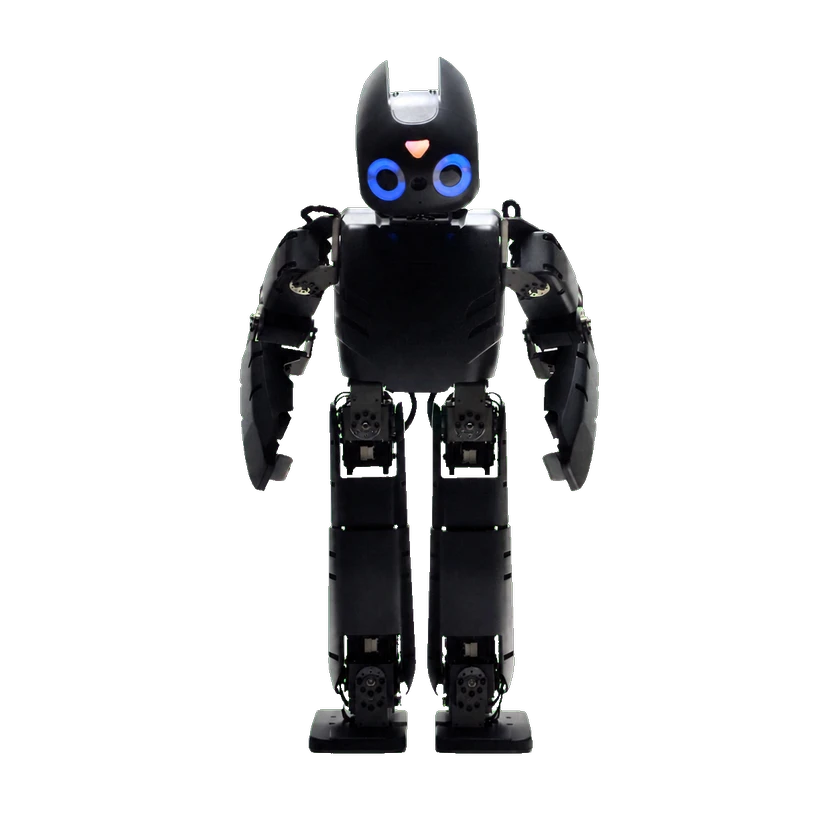
Darwin-OP ist eine kompakte humanoide Plattform mit zwei Beinen für Robotikforschung und Bildung. Sie kombiniert 20 Dynamixel-MX-28-Aktuatoren, einen Intel-Atom-Z530-Computer, Open-Source-Software, Kameras, Trägheitssensoren, Mikrofone und einen herausnehmbaren Akku. Die Plattform unterstützt Gehen, dynamische Bewegung, Selbstwartung sowie offene Hardware- und Softwareentwicklung.
The official DARwIn-OP page lists a default walking speed and user-modifiable gait.
Classic DARWIN-OP/ROBOTIS OP has manufacturer-preserved Linux C++ Framework and Webots documentation. The old rendered manual URLs now redirect to the new documentation home, so this batch uses pinned manufacturer-authored source documents. Match the original CM730/MX28 platform, framework/toolchain and simulator version; do not inherit OP2/OP3 features, modern bindings or unreviewed software/hardware licenses.
Manufacturer classic OP Framework documents g++ development, CM730/MotionManager integration and JointData SetAngle/SetRadian goal setters. Position control is through the matching framework/motion-timer path and MX28 firmware; SetRadian values are radians while raw actuator values and degree-based SetAngle must not be confused. Left/right arm ID groups establish two execution arms. No independent torque/velocity mode, Cartesian API, Python/ROS binding or full software license is established by this documentation review.
Materialien sind zugänglich; daraus folgt keine Berechtigung zur Weiterverwendung.
Für diesen Bereich liegen noch keine ausreichenden verifizierten Belege vor.
Für diesen Bereich liegen noch keine ausreichenden verifizierten Belege vor.
Statusangaben stammen aus früheren Berichten; der weitere Betrieb ist unbekannt.
Einsatzberichte 1 · Pilot 1
National Yunlin Special School
The IEEE conference paper identifies the robot as ROBOTIS DARwIn-OP, names National Yunlin Special School in its acknowledgements, and reports seven weeks of sessions involving two students, a teacher, and the research team. This is a school-based research pilot; it is not evidence of routine clinical service, a paid purchase, or continuing operation. The study start date and exact school address are not reported.
Noch keine verwandten Produkte erfasst.

