
Komponenten
Komponenten, Modelle oder Unternehmen suchen
221 komponenten-Modelle werden angezeigt
| Komponente | Organisation | Land | Produktstatus | Verfügbarkeit | Fingeranzahl | Anzahl der Gelenke | Aktive Freiheitsgrade | Maximalgewicht | Kommunikationsschnittstelle | Tastsensorik | Aktionen | ||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
 MS-GelenkmoduleMS14 | Elephant Robotics | China | Kommerziell | Nicht veröffentlicht | — | — | — | 1,7 kg | — | — | Preis nicht veröffentlicht | — | |
 BSJ Integrierte GelenkmoduleBSJ11 | DUCO Robots | China | Kommerziell | Im Verkauf | — | — | — | 0,45 kg | — | — | Nicht veröffentlicht | — | |
 RHURHU20L-70 | EYOU Robotics | China | Kommerziell | Im Verkauf | — | — | — | — | — | — | — | 2026-09-15 | |
 GelenkmotorenBXI5014-19 | BXI Robotics | China | Kommerziell | Nicht veröffentlicht | — | — | — | — | — | — | — | 2026-09-15 | |
 Pantheon HandPantheon Hand 20 | Shenzhen Stellar Robot Technology Co., Limited | China | Kommerziell | Nicht veröffentlicht | — | — | — | 0,29 kg | — | — | — | 2026-09-15 | |
 Pantheon Hand 01Pantheon Hand 01 | Shenzhen Stellar Robot Technology Co., Limited | China | Pilotphase | Nur Pilotbetrieb | 5 Finger | — | 15 FG | ≤0.35 kg | — | — | — | 2026-09-15 | |
 X SeriesX5-1 | HEBI Robotics | Vereinigte Staaten | Kommerziell | Nicht veröffentlicht | — | — | — | — | — | — | — | 2026-09-15 | |
 Gaia Hand 20Gaia Hand 20 | Shenzhen Stellar Robot Technology Co., Limited | China | Kommerziell | Nicht veröffentlicht | 5 Finger | — | 20 FG | — | — | — | — | 2026-09-15 | |
| OSOR HandOSOR Hand | Southern University of Science and Technology | China | Prototyp | Nicht veröffentlicht | 5 Finger | 12 Gelenke | 12 FG | — | — | — | — | 2026-09-15 | |
| PDSR3-Tac HandPDSR3-Tac Hand | Southeast University | China | Prototyp | Nicht veröffentlicht | 3 Finger | — | — | — | — | — | — | 2026-09-15 | |
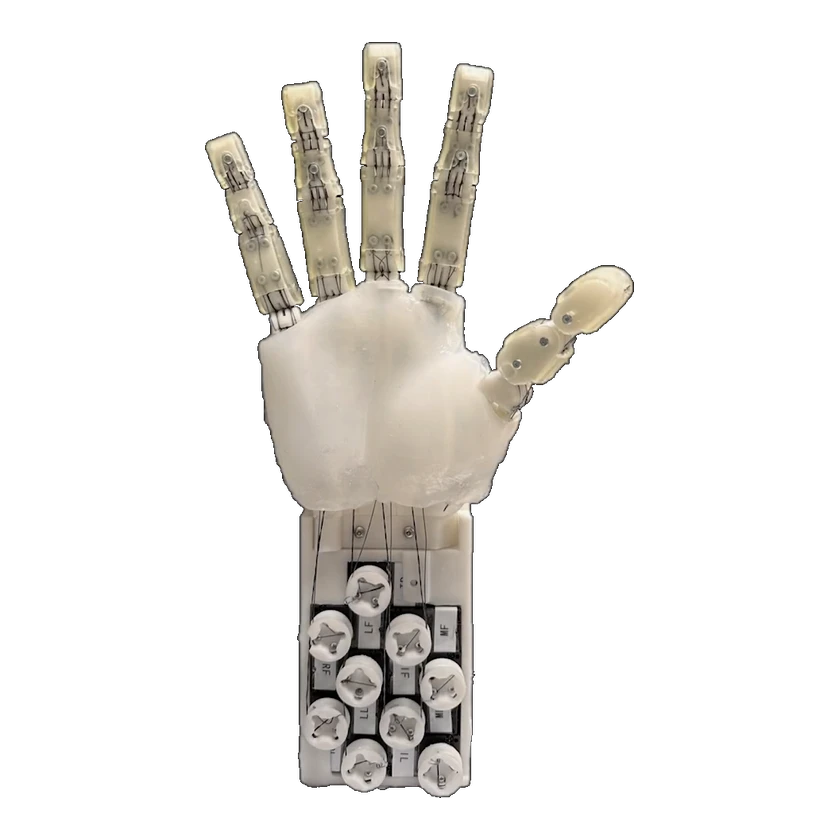 RIM HandRIM Hand | Sogang University | Südkorea | Prototyp | Nicht veröffentlicht | 5 Finger | — | — | 0,74 kg · 0,34 kg | — | — | — | 2026-09-15 | |
 DYNAMIXEL YYM070-210-A051-RH | Robotis | Südkorea | Kommerziell | Im Verkauf | — | — | — | — | — | — | USD 2,978.39 | 2026-09-15 |
Quelle oder Korrektur einreichen