
학습 방식공식 발표
원격 조작
 Petoi
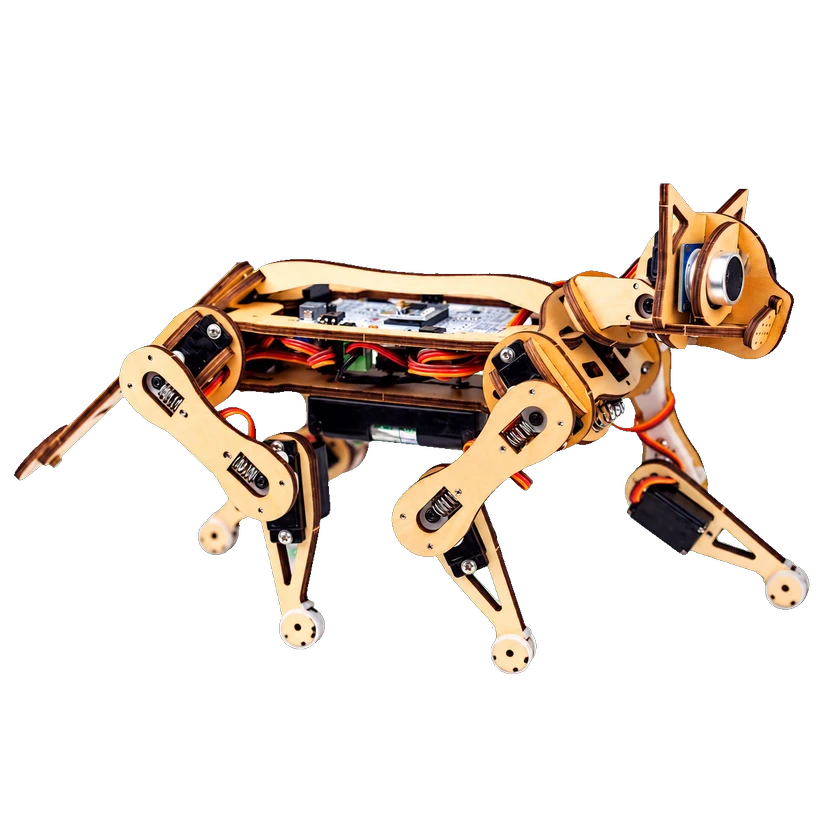
Nybble은 다족 로봇공학 학습을 위한 Petoi의 오픈 소스 목재 로봇 고양이 키트입니다. 서보 관절 11개, 초음파 센싱, IMU, 적외선 제어, 모바일·데스크톱 앱 및 OpenCat 프로그래밍을 결합합니다. 모듈형 플랫폼은 학생, 취미 사용자, 메이커 및 로봇공학 교육자를 위해 Arduino, Python, 블록 코딩과 Raspberry Pi 확장을 지원합니다.
실험은 기본 탑재를 의미하지 않습니다. 근거는 명시된 모델 버전에만 적용됩니다.
Petoi's official FAQ lists balancing among Nybble's available robot-cat actions.
The official page states that Nybble can be controlled with the included infrared remote or Petoi mobile and desktop apps.
Nybble has model-scoped manufacturer programming documentation and serial Python/C++ interfaces. This is the legacy NyBoard model, using the NyBoard OpenCat build; the newer ESP32 Nybble Q/Bittle X V2 hardware is separate. Match the delivered board revision, servo variant, firmware model/calibration and host library. The reviewed body is the standard quadruped without an optional manipulation-arm add-on; legs are not counted as execution arms. Open source firmware/API code does not by itself license all hardware, dependencies or hosted assets.
Use the model-specific board firmware: NyBoard/ATmega328P, selecting the actual Bittle or Nybble model; NyBoard revisions may require different serial baud rates. Manufacturer Python docs specify Python>=3.6 and pyserial3.5; use the dependency versions of the matching checkout. The C++ CMake serial client exposes joint sequences/simultaneous targets, while Python m/M use calibrated degree targets and ASCII/binary framing. Configure actual port, power, servo offsets and active-index map: the logical16-slot packet is not16physical actuators. Native serial motion does not establish joint-velocity/torque/FF or map-navigation APIs. Distinguish commanded angle reporting from actual feedback; ESP32 f-feedback requires supported servo hardware.
소스 코드와 오픈 소스 라이선스가 확인되었습니다. 각 자료의 이용 조건을 따르세요.
NyBoard V1.0 논리 구성, 부품 및 전기 인터페이스 자료입니다. 해당 보드 탑재 키트에 적용되며 전체 제조 파일과 하드웨어 라이선스는 미확인입니다.
설명 보기OpenCat-Quadruped-Robot · pinned MIT primary software files
코드적용 버전: petoi_nybble_native_serialMIT
opencat_serial_cpp · pinned MIT primary software files
코드적용 버전: petoi_nybble_native_serialMIT
ros_opencat · pinned MIT primary software files
코드적용 버전: petoi_nybble_ros1_noetic_85962928MIT
ros_opencat ROS2 branch · pinned MIT code
코드적용 버전: petoi_nybble_ros2_bdec9d34MIT
OpenCat 펌웨어 (NyBoard)
코드MIT
NyBoard V1.0 제어 보드 인터페이스
하드웨어
Petoi 데스크톱: 설정·보정
도구
OpenCat Python 직렬 제어 안내
안내
등록된 관련 제품이 없습니다.

