
학습 방식공식 발표
원격 조작
 Petoi
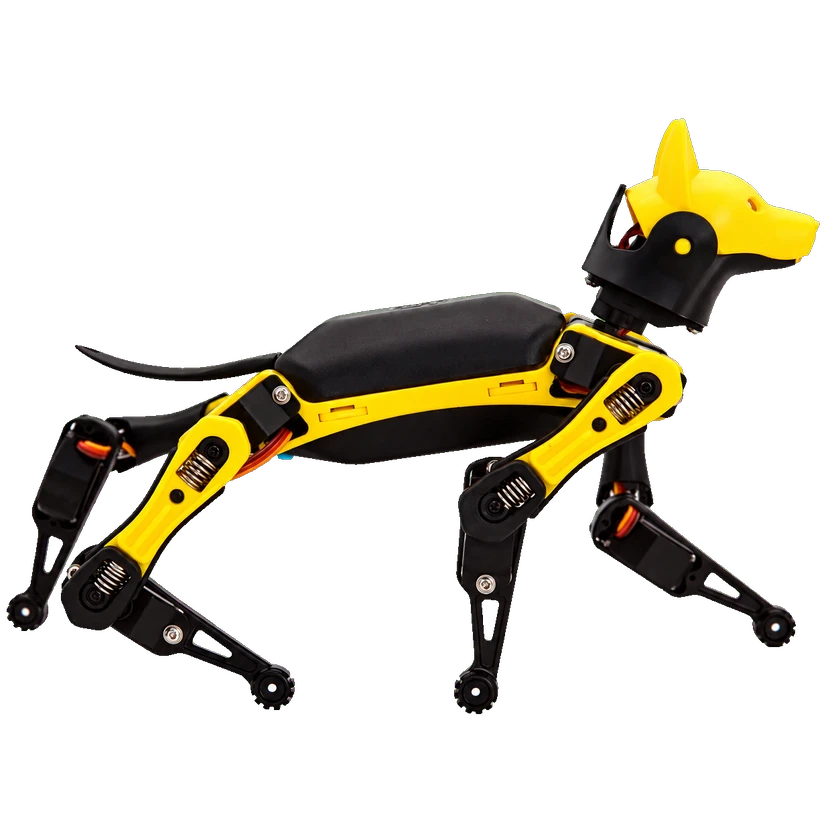
Bittle은 취미 사용자, 학생 및 교육자를 위한 Petoi의 손바닥 크기 4족 보행 로봇 강아지입니다. 9개의 디지털 서보 관절과 오픈소스 OpenCat 시스템은 보행, 달리기, 묘기 및 로보틱스 학습을 위한 블록 코딩, Python, Arduino 및 앱 제어를 지원합니다.
실험은 기본 탑재를 의미하지 않습니다. 근거는 명시된 모델 버전에만 적용됩니다.
Petoi describes Bittle as a four-legged robot dog and states that its battery supports about one hour of continuous walking.
The official Bittle FAQ states that the robot processes voice commands locally and does not send voice to a server.
Petoi describes 35+ lifelike interactive movements, remote or app control, and use in team coding and social-interaction learning.
Bittle has model-scoped manufacturer programming documentation and serial Python/C++ interfaces. This is the legacy NyBoard model, using the NyBoard OpenCat build; the newer ESP32 Nybble Q/Bittle X V2 hardware is separate. Match the delivered board revision, servo variant, firmware model/calibration and host library. The reviewed body is the standard quadruped without an optional manipulation-arm add-on; legs are not counted as execution arms. Open source firmware/API code does not by itself license all hardware, dependencies or hosted assets.
Bittle X V2 has model-scoped manufacturer programming documentation and serial Python/C++ interfaces. The current guide explicitly identifies this V2 model with BiBoard V1/ESP32; legacy docs explicitly exclude Bittle X V2. Match the delivered board revision, servo variant, firmware model/calibration and host library. The reviewed body is the standard quadruped without an optional manipulation-arm add-on; legs are not counted as execution arms. Open source firmware/API code does not by itself license all hardware, dependencies or hosted assets.
Bittle X V2+Arm has model-scoped manufacturer programming documentation and serial Python/C++ interfaces. The current guide explicitly identifies this V2 model with BiBoard V1/ESP32; legacy docs explicitly exclude Bittle X V2. Match the delivered board revision, servo variant, firmware model/calibration and host library. The reviewed body is a quadruped with one attached execution arm/gripper. Open source firmware/API code does not by itself license all hardware, dependencies or hosted assets.
Use the model-specific board firmware: NyBoard/ATmega328P, selecting the actual Bittle or Nybble model; NyBoard revisions may require different serial baud rates. Manufacturer Python docs specify Python>=3.6 and pyserial3.5; use the dependency versions of the matching checkout. The C++ CMake serial client exposes joint sequences/simultaneous targets, while Python m/M use calibrated degree targets and ASCII/binary framing. Configure actual port, power, servo offsets and active-index map: the logical16-slot packet is not16physical actuators. Native serial motion does not establish joint-velocity/torque/FF or map-navigation APIs. Distinguish commanded angle reporting from actual feedback; ESP32 f-feedback requires supported servo hardware.
소스 코드와 오픈 소스 라이선스가 확인되었습니다. 각 자료의 이용 조건을 따르세요.
NyBoard V1.0 논리 구성, 부품 및 전기 인터페이스 자료입니다. 해당 보드 탑재 키트에 적용되며 전체 제조 파일과 하드웨어 라이선스는 미확인입니다.
설명 보기OpenCat-Quadruped-Robot · pinned MIT primary software files
코드적용 버전: petoi_bittle_native_serialMIT
opencat_serial_cpp · pinned MIT primary software files
코드적용 버전: petoi_bittle_native_serialMIT
ros_opencat · pinned MIT primary software files
코드적용 버전: petoi_bittle_ros1_noetic_85962928MIT
ros_opencat ROS2 branch · pinned MIT code
코드적용 버전: petoi_bittle_ros2_bdec9d34MIT
OpenCat 펌웨어 (NyBoard)
코드MIT
NyBoard V1.0 제어 보드 인터페이스
하드웨어
Petoi 데스크톱: 설정·보정
도구
OpenCat Python 직렬 제어 안내
안내
상태는 과거 자료에 기반하며 이후 운영 상황은 알 수 없습니다.
배치 기록 1 · 시범 운영 1 · 프로젝트 실제 대수 · 미공개
Bluefield State University
Petoi reports that its exact Bittle quadruped was featured in the inaugural one-week President’s Emerging Scholars Academy program at Bluefield State University. Students assembled the robots, used Scratch block-based coding, and programmed movement behaviors. Petoi says the academy began in summer 2023; WVVA’s June 19, 2023 report independently confirms that the academy launched that year and its students built robotic dogs on campus. The exact camp start day, robot count, payment, and current use are not disclosed.
등록된 관련 제품이 없습니다.

