
移動公式発表
歩行
The official DARwIn-OP page lists a default walking speed and user-modifiable gait.
 株式会社ロボティズ
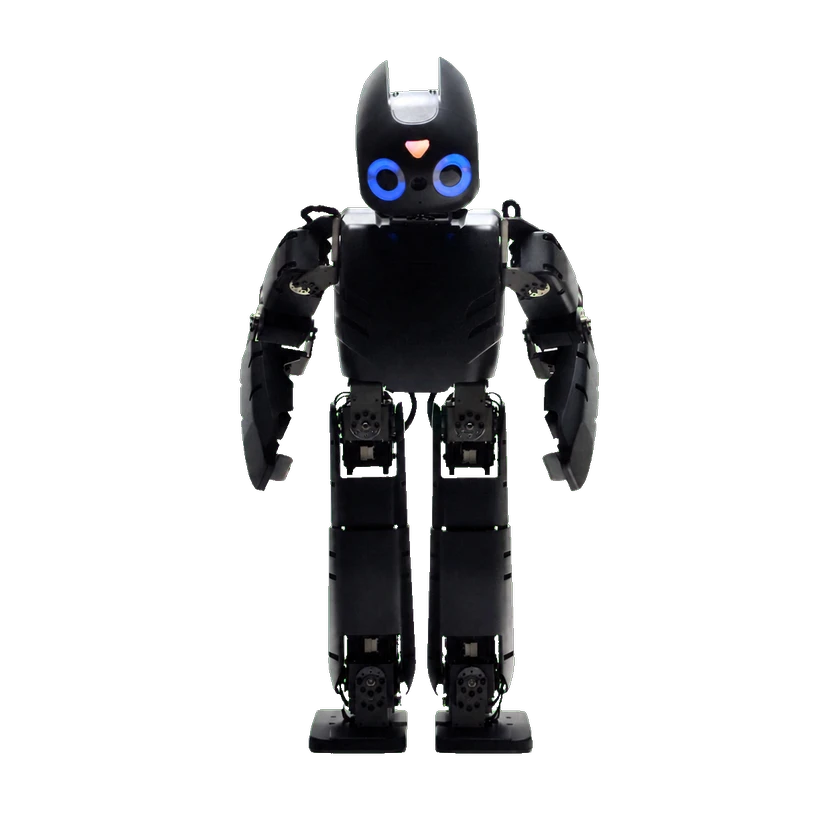
Darwin-OPはロボット研究と教育向けの小型二足歩行ヒューマノイドプラットフォームです。20個のDynamixel MX-28アクチュエータ、Intel Atom Z530、オープンソースソフトウェア、カメラ、慣性センサー、マイクを備え、歩行、動的運動、保守、オープンな開発に対応します。
The official DARwIn-OP page lists a default walking speed and user-modifiable gait.
旧 DARWIN-OP/ROBOTIS OP は公式保存 Linux C++ Framework/Webots 資料がある。旧 URL は現在 home へ転送されるため固定公式 source 文書を採用。元 CM730/MX28・framework/toolchain・simulator を整合し OP2/OP3/現代 binding/license を継承しない。
Manufacturer classic OP Framework documents g++ development, CM730/MotionManager integration and JointData SetAngle/SetRadian goal setters. Position control is through the matching framework/motion-timer path and MX28 firmware; SetRadian values are radians while raw actuator values and degree-based SetAngle must not be confused. Left/right arm ID groups establish two execution arms. No independent torque/velocity mode, Cartesian API, Python/ROS binding or full software license is established by this documentation review.
旧 OP Framework は g++・CM730/MotionManager・JointData SetAngle/SetRadian target を記載。対応 timer/framework/MX28 firmware が条件。SetRadian は rad、raw actuator/degree と区別。左右 arm ID group で実行腕2。独立 torque/velocity・Cartesian・Python/ROS・全 license は未確定。
資料を入手できますが、公開だけで再利用の権利が付与されるわけではありません。
この項目について十分な検証済みの根拠がありません。
この項目について十分な検証済みの根拠がありません。
状態は過去の資料に基づき、その後の稼働状況は不明です。
導入記録 1 · 試験導入 1
National Yunlin Special School
The IEEE conference paper identifies the robot as ROBOTIS DARwIn-OP, names National Yunlin Special School in its acknowledgements, and reports seven weeks of sessions involving two students, a teacher, and the research team. This is a school-based research pilot; it is not evidence of routine clinical service, a paid purchase, or continuing operation. The study start date and exact school address are not reported.
関連製品はまだ登録されていません。

