
学習方法公式発表
遠隔操作
 Petoi
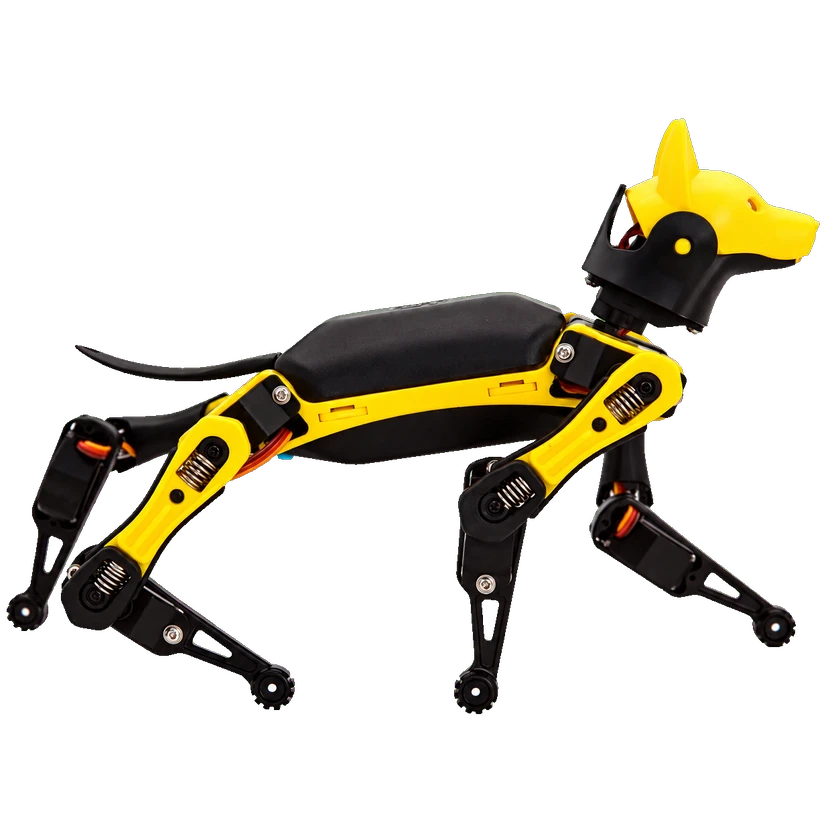
Bittleは、ホビイスト、学生、教育者向けのPetoi製手のひらサイズ四足ロボット犬です。9個のデジタルサーボ関節とオープンソースのOpenCatにより、ブロック、Python、Arduino、アプリで歩行や芸、ロボット学習を行えます。
実験は標準搭載を意味しません。根拠は記載されたモデルバージョンにのみ適用されます。
Petoi describes Bittle as a four-legged robot dog and states that its battery supports about one hour of continuous walking.
The official Bittle FAQ states that the robot processes voice commands locally and does not send voice to a server.
Petoi describes 35+ lifelike interactive movements, remote or app control, and use in team coding and social-interaction learning.
Bittle 専用 docs と serial Python/C++ を確認。legacy NyBoard と新 ESP32 世代を分離。board/servo/firmware/model/校正/library を整合。標準四足・任意腕なし0。software grant と他資産を区別。
Bittle X V2 専用 docs と serial Python/C++ を確認。V2 は BiBoardV1/ESP32、旧 docs 対象外。board/servo/firmware/model/校正/library を整合。標準四足・任意腕なし0。software grant と他資産を区別。
Bittle X V2+Arm 専用 docs と serial Python/C++ を確認。V2 は BiBoardV1/ESP32、旧 docs 対象外。board/servo/firmware/model/校正/library を整合。標準四足+実行腕1。software grant と他資産を区別。
Use the model-specific board firmware: NyBoard/ATmega328P, selecting the actual Bittle or Nybble model; NyBoard revisions may require different serial baud rates. Manufacturer Python docs specify Python>=3.6 and pyserial3.5; use the dependency versions of the matching checkout. The C++ CMake serial client exposes joint sequences/simultaneous targets, while Python m/M use calibrated degree targets and ASCII/binary framing. Configure actual port, power, servo offsets and active-index map: the logical16-slot packet is not16physical actuators. Native serial motion does not establish joint-velocity/torque/FF or map-navigation APIs. Distinguish commanded angle reporting from actual feedback; ESP32 f-feedback requires supported servo hardware.
専用 board/model firmware・baud/port/power/zero/active map を整合。Python>=3.6/pyserial3.5 は docs の条件で checkout 依存を優先。C++ sequence/simultaneous と Python m/M は校正 degree target。16 logical slot を実16軸とせず velocity/torque/FF/navigation/実測 feedback を推測しない。
ソースコードとライセンスを検証済みです。各資料の利用条件に従ってください。
OpenCat-Quadruped-Robot · pinned MIT primary software files
コード対象バージョン: petoi_bittle_native_serialMIT
opencat_serial_cpp · pinned MIT primary software files
コード対象バージョン: petoi_bittle_native_serialMIT
ros_opencat · pinned MIT primary software files
コード対象バージョン: petoi_bittle_ros1_noetic_85962928MIT
ros_opencat ROS2 branch · pinned MIT code
コード対象バージョン: petoi_bittle_ros2_bdec9d34MIT
OpenCat ファームウェア(NyBoard)
コードMIT
NyBoard V1.0 制御基板インターフェース
ハードウェア
Petoi デスクトップ:設定・校正
ツール
OpenCat Python シリアル制御ガイド
ガイド
状態は過去の資料に基づき、その後の稼働状況は不明です。
導入記録 1 · 試験導入 1 · 案件の実績台数 · 非公開
Bluefield State University
Petoi reports that its exact Bittle quadruped was featured in the inaugural one-week President’s Emerging Scholars Academy program at Bluefield State University. Students assembled the robots, used Scratch block-based coding, and programmed movement behaviors. Petoi says the academy began in summer 2023; WVVA’s June 19, 2023 report independently confirms that the academy launched that year and its students built robotic dogs on campus. The exact camp start day, robot count, payment, and current use are not disclosed.
関連製品はまだ登録されていません。

