
 Sharpa
Wave
Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Purchase
Contact manufacturer
Release Date
Unknown
Country/Region
Singapore
Last Verified
Unknown
22 DOF
Active degrees of freedom
1.3 kg
Weight
5
Finger count
Wave W01 SE is Sharpa’s human-scale, five-finger dexterous hand with 22 active degrees of freedom. It weighs 1.3 kg, carries 24 kg and uses a 60×60 Dynamic Tactile Array with 30 fps on-board inference, supporting physical AI research, robot integration and precise manipulation.
1 / 1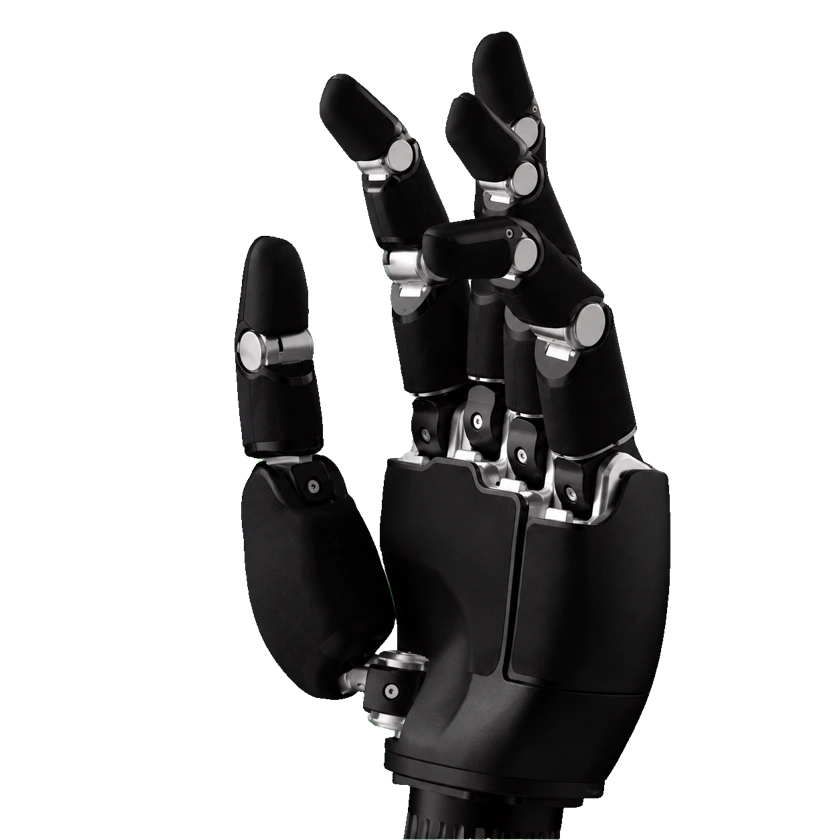
Hardware Specification
Sensing and data flow
Communication frame rate
500 Hz
Degrees of freedom and drive
Active degrees of freedom
22 DOF
Mobility & Payload
Hand Payload
24 kg
Mechanical and mounting
Minimum grip diameter
1 cm
Weight
1.3 kg
Electrical and integration
Actuator Model
22 proprietary actuation modules
Joint Motion Range
-20–20 °
Operating voltage
18–28 V
Static current
0.75 A
Sensors
Force/Torque Sensor
Six-dimensional force/torque sensing: Fx, Fy, Fz, Mx, My, Mz.
Tactile Sensor
Dynamic Tactile Array: 60×60 resolution; 0.05 N force resolution; 2 mm spatial resolution; 30 fps; 50 N maximum load; 0–30 N force detection range. On-board inference; no raw image output.
Performance and tasks
Repeatability
±1 mm fingertip position repeatability
Software Algorithm
Sharpa Pilot
Reliability and environment
Operating temperature
0–45 °C
Interaction and Communication
Communication
1000 BASE-T Ethernet
Tactile Feedback
Detects pressure, slip, force changes and fingertip contact location; adjusts grip, pose and force in real time.
Development and Expansion
Integration Interface
ROS 2 integration; MuJoCo and Isaac Sim simulation; SharpaPilot SDK deployment.
Secondary Development (SDK)
Sharpa Wave SDK
Commercial Status
Status
Unknown
Price
Price not disclosed
Release Date
Unknown
Related Entities
Submit a source or correction