Price
Unknown
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Release Date
Oct 15, 2026
Country/Region
China
Latest parameter verification
2026-10-19
21 DOF
Active degrees of freedom
5
Finger count

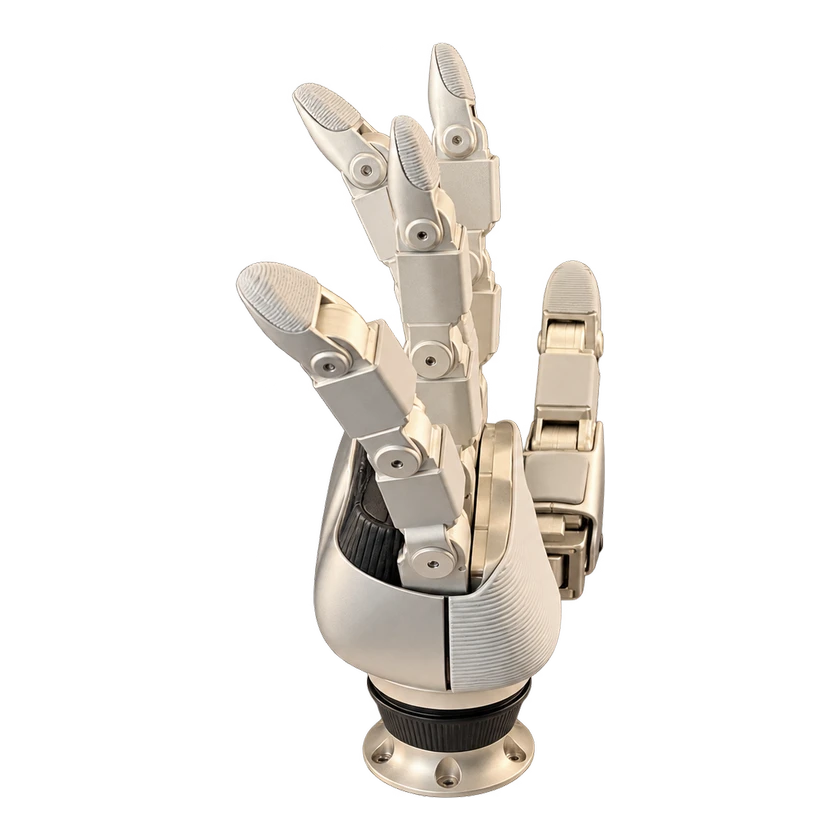
NOVA21 is a five-finger dexterous hand for research and development. Its 21 active rotary direct-drive degrees of freedom combine with three-axis fingertip and finger-pad sensing and a palm force array. Force control, backdrivability, OTA updates and a quick-change wrist support manipulation experiments.

1 / 1NOVA21

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
5
Actuator technology
In-house direct-drive rotary actuators
Active degrees of freedom
21 DOF
Transmission mechanism
Rotary direct drive

Motion and coordination

Coordination architecture
Thumb: 5 active DOF; each other finger: 4 active DOF

Mechanical and mounting

Mounting interface
Quick-change wrist

Performance and tasks

Repeatability
±0.2 mm

Configurations

NOVA21

Communication and control

Communication interface
RS485
Communication interface
CAN-FD
Communication interface
EtherCAT
Communication interface
TCP/IP
Control mode
Force control

Sensing

Has tactile sensing
Supported
Proprioceptive feedback
Dual encoders
Tactile configuration
16 force sensors; three-axis fingertip and finger-pad sensing; palm normal-force array; normal 0–25 N; tangential ±10 N; resolution 0.1 N

Commercial Status

Status
Unknown
Price
Unknown
Release Date
Oct 15, 2026
Submit a source or correction