
 Sharpa
Wave W01 SE
Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Commercial
Availability
Pre-order available
Purchase
Contact manufacturer
Release Date
Aug 18, 2026
Country/Region
Singapore
Last Verified
2026-10-12
22 DOF
Active degrees of freedom
1.3 kg
Weight
5
Finger count
Wave W01 SE is Sharpa’s human-scale, five-finger dexterous hand with 22 active degrees of freedom. It weighs 1.3 kg, carries 24 kg and uses a 60×60 Dynamic Tactile Array with 30 fps on-board inference, supporting physical AI research, robot integration and precise manipulation.
1 / 1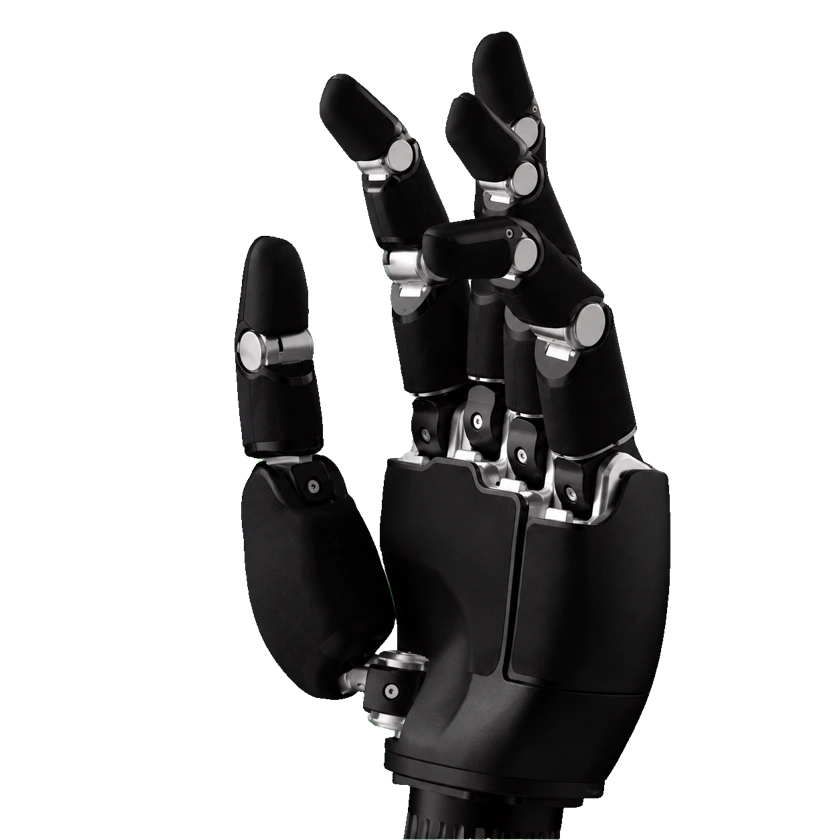
Hardware Specification
Sensing and data flow
Communication frame rate
500 Hz
Measurement resolution
DTA 60×60; force resolution 0.05 N; spatial resolution 2 mm
Sensing and data flow
Motion-to-data latency
20 ms tactile sensing latency
Sensor sample rate
30 Hz tactile deformation-image acquisition
Versions and commercial status
Public contact link
Official W01 / W01 SE product and sales inquiry page
Use cases and capture workflow
Use cases
Physical AI research, robot integration, large-scale manipulation-data collection, model training, and whole-robot development
Software, export and openness
SDK versions and download links
Sharpa Wave SDK v5.0.10 added Wave SE support on 2026-09-11
Force, touch and feedback
Force measurement range
0–30 N tactile force detection range
Force and torque sensor setup
Six-dimensional force/torque sensing: Fx, Fy, Fz, Mx, My, Mz
Tactile measurements
Pressure, slip, force changes, fingertip contact location, and six-dimensional force/torque
Degrees of freedom and drive
Color
Matte black
Active degrees of freedom
22 DOF
Mobility & Payload
Hand Payload
24 kg
Mechanical and mounting
Minimum grip diameter
1 cm
Weight
1.3 kg
Electrical and integration
Actuator Model
22 proprietary actuation modules
Joint Motion Range
-20–20 °
Operating voltage
18–28 V
Static current
0.75 A
Sensors
Force/Torque Sensor
Six-dimensional force/torque sensing: Fx, Fy, Fz, Mx, My, Mz.
Tactile Sensor
Dynamic Tactile Array: 60×60 resolution; 0.05 N force resolution; 2 mm spatial resolution; 30 fps; 50 N maximum load; 0–30 N force detection range. On-board inference; no raw image output.
Performance and tasks
Repeatability
±1 mm fingertip position repeatability
Software Algorithm
Sharpa Pilot
Reliability and environment
Operating temperature
0–45 °C
Interaction and Communication
Communication
1000 BASE-T Ethernet
System Response Time
0.10 s
Tactile Feedback
Detects pressure, slip, force changes and fingertip contact location; adjusts grip, pose and force in real time.
Development and Expansion
Integration Interface
ROS 2 integration; MuJoCo and Isaac Sim simulation; SharpaPilot SDK deployment.
Secondary Development (SDK)
Sharpa Wave SDK
Commercial Status
Status
Commercial
Price
Price not disclosed
Release Date
Aug 18, 2026
Related Entities
Submit a source or correction