Price
Unknown
Type
Mobile Manipulators · Home Mobile Manipulator
Applications
Household · Domestic Assistance / Research & Education · Research Platform
Status
Prototype
Availability
Not released
Purchase
Not disclosed
Release Date
2007
Country/Region
Japan
Last Verified
2026-08-14
Approx. 22 kg at both hands
General Payload
30 min
Runtime
0.75 m/s
Walking Speed
111 kg
Weight

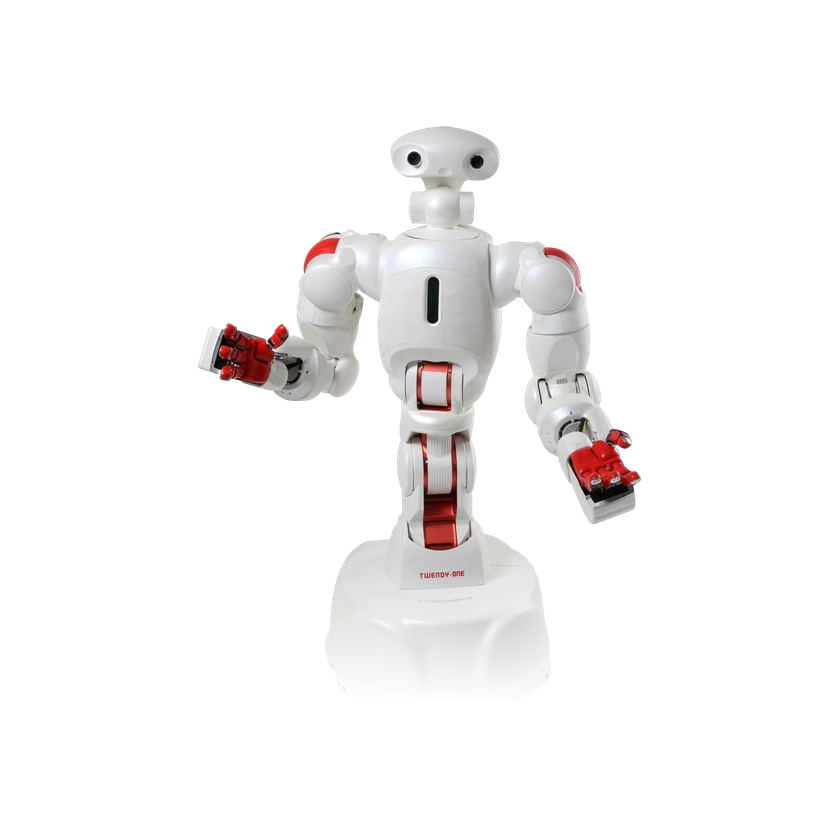
Twendy One is a human-symbiotic mobile manipulator developed by Waseda University for elderly home assistance research. It combines a humanoid body, powerful dual arms, dexterous anthropomorphic hands, an omni-wheeled base, stereo cameras and force sensors to study safe support for standing, mobility and household tasks.

1 / 1Twendy One

Capability Map

MobilityOfficial claim
Navigation
ManipulationDemonstrated
Grasping
ManipulationDemonstrated
Pick and place
InteractionDemonstrated
Human collaboration

Hardware Specification

Physical Specifications

Arm Specifications
Dual high-power arms
Locomotion Type
Omni-wheeled mobile base
Materials
Silicone, plastic, and metal
Dimensions (Standing)
Height 1.467 m; width 73.4 cm
Total degrees of freedom
47 DOF

Mobility & Payload

General Payload
Approx. 22 kg at both hands
Walking Speed
0.75 m/s

Mechanical and mounting

Height
1.467 m
Weight
111 kg
Width
73.4 cm

Mechanical Structure

Actuator Model
51 AC servomotors
Chassis
Omni-wheeled vehicle
Dexterous Hand
Anthropomorphic dexterous hands

Sensors

Camera
Stereo cameras
Sensors
Stereo cameras; five six-axis force sensors; 60 position sensors; over 600 distributed force sensors

Battery and Runtime

Runtime
30 min

Compute Platform

Onboard Compute
Seven Pentium processors

Commercial Status

Status
Prototype
Price
Unknown
Release Date
2007

Timeline

  1. Robot release
    Twendy One
Submit a source or correction