
 Source Robotics
PAROL6
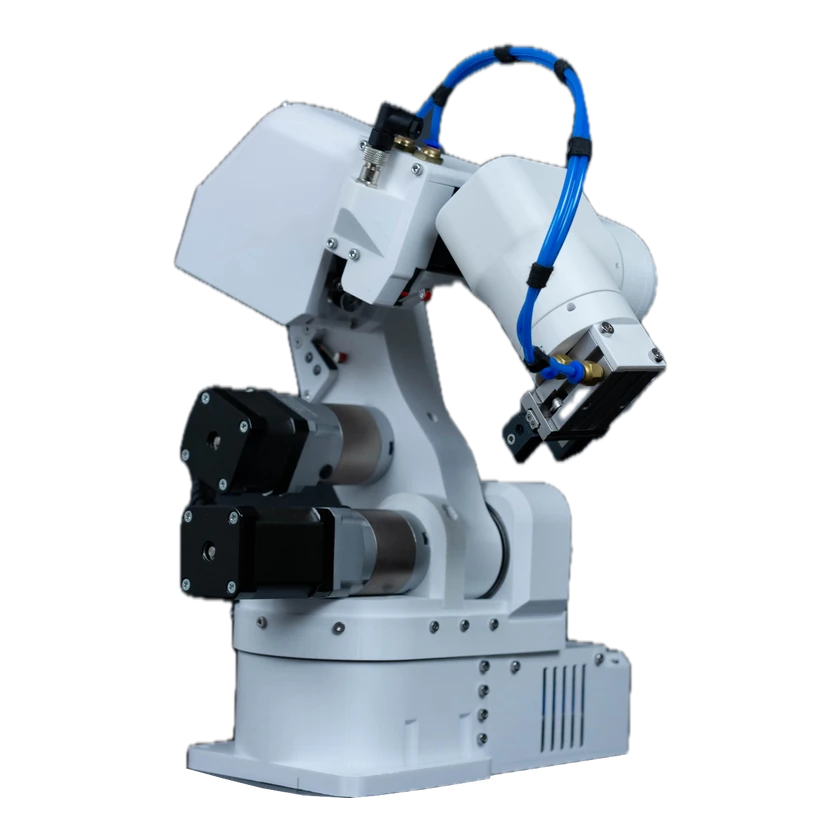
PAROL6 is a six-axis desktop robot arm for research, teaching and small automation projects. It uses 3D-printed PETG parts and stepper motors. The manufacturer offers an assembled arm and kits, and publishes mechanical files, a bill of materials and assembly instructions for self-builders. A Python API and pneumatic, electric and vacuum gripper options support experimentation.
Hardware Specification
Physical specifications and power
Software, export and openness
Degrees of freedom and drive
Mobility & Payload
Degrees of Freedom
Mechanical Structure
Battery and Runtime
Performance and tasks
Safety and Protection
Interaction and Communication
Development and Expansion
Open source & build resources
Software
Publicly availableResources can be accessed; publication alone does not grant reuse rights.
Hardware design
Open sourceDesign files and a verified open license are available. Follow the terms of each resource.
Build resources
CompleteBOM, structure files and assembly instructions are available for the same version. Check each license before reuse.
| Type | Resource | License | Applicable version | Open |
|---|---|---|---|---|
| Hardware | PAROL6 V1.1 STL files GitHub · Source-Robotics/PAROL6-Desktop-robot-arm | CERN-OHL-S-2.0 | V1.1 | Open GitHub |
| BOM | PAROL6 V1.1 bill of materials GitHub · Source-Robotics/PAROL6-Desktop-robot-arm | — | V1.1 | Open GitHub |
| Guide | PAROL6 V1.1 assembly instructions GitHub · Source-Robotics/PAROL6-Desktop-robot-arm | — | V1.1 | Open GitHub |
| Code | PAROL6 control board firmware 1 GitHub · Source-Robotics/PAROL6-Desktop-robot-arm | — | V1.1 | Open GitHub |
Commercial Status
Related Entities
No related products recorded yet.
Timeline
- Robot releasePAROL6