Price
EUR 3,570 (German storefront list price)
Type
Robot Arms
Applications
Research & Education · Research Platform / Research & Education · Education Platform
Status
Commercial
Availability
Not disclosed
Release Date
Jul 2023
Country/Region
Croatia
43.4 cm
Reach
0.1 mm
Repeatability
5.5 kg
Weight

PAROL6 is a six-axis desktop robot arm for research, teaching and small automation projects. It uses 3D-printed PETG parts and stepper motors. The manufacturer offers an assembled arm and kits, and publishes mechanical files, a bill of materials and assembly instructions for self-builders. A Python API and pneumatic, electric and vacuum gripper options support experimentation.
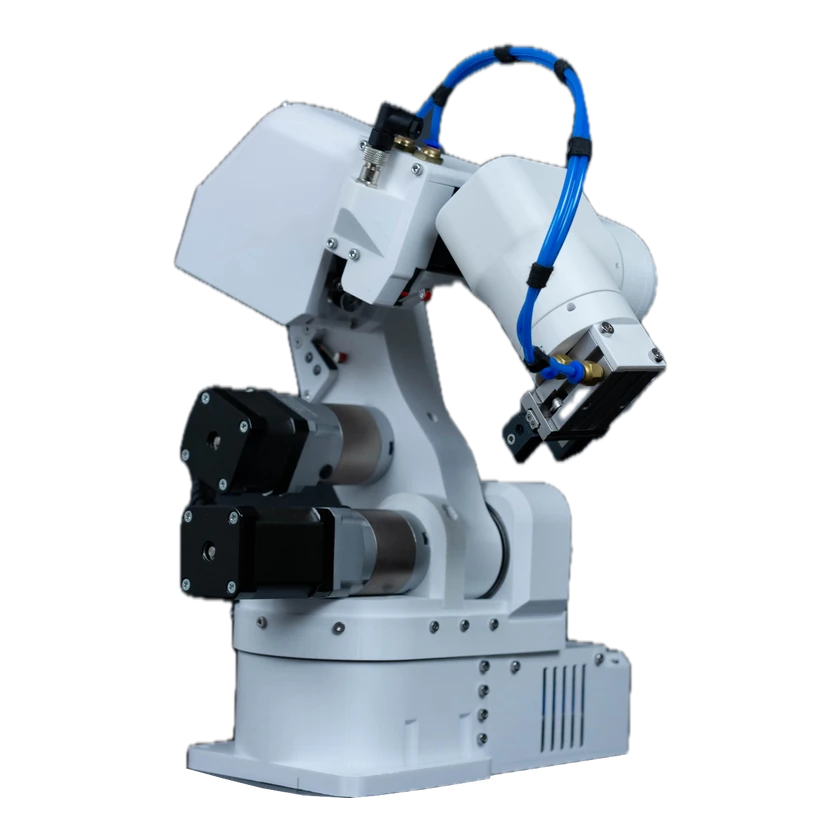
PAROL6

Hardware Specification

Physical specifications and power

Mounting or wearing method
Upright base, bolted or clamped
Typical power consumption
40 W

Software, export and openness

Companion software
PAROL6 Commander (main)
Firmware versions and updates
Control board firmware 1
Hardware openness
V1.1 mechanical files: STL, BOM, assembly instructions, URDF and MuJoCo models, pneumatic gripper holders
License and usage terms
Hardware: CERN-OHL-S-2.0 / Firmware: GPL-3.0
SDK versions and download links
0.9.1

Degrees of freedom and drive

Actuator count
6
Actuator technology
Stepper motor
Arm Specifications
J1 to bare flange: 408 mm. J1 to standard pneumatic gripper TCP: 434 mm. Payload near base: 1 kg. Payload at full reach: 0.5 kg. Both payloads include the tool.
Mechanical joint count
6
Materials
3D-printed PETG, steel shafts and bearings

Mobility & Payload

Single-arm Payload
1 kg
Max Speed
0.2 m/s
Reach
43.4 cm

Degrees of Freedom

Controllable DOF per Arm
6 DOF
Mounting flange standard
Ø8 mm J6 output shaft, Ø8 mm bore clamp coupler with M4 set screws
Mounting interface
Six M5 mounting holes for 30 × 30 mm aluminium profiles
Weight
5.5 kg

Mechanical Structure

Actuator Model
NEMA 17
End-Effector
SSG-48: coupler_connector_PAROL6 + 24 V/CAN. MSG: ring_cover-PAROL6 + 24 V/CAN. SMC MHZ2-16D: printed holder, two air lines and 24 V 5/2 valve (5–7 bar within component ratings). Vacuum: printed holder, ejector and one air line on the same valve, other outlet blocked.
Joint Encoder
No joint encoders
Joint Limit
J1 194.8° / J2 113.4° / J3 189.1° / J4 229.2° / J5 240.6° / J6 360° (software)
Joint Sensor Type
Limit switches (J2, J3, J5), inductive sensors (J1, J4, J6)
Joint Type
Revolute
Operating voltage
24 V
Reducer Type
Planetary gearboxes (J2, J3, J6) and HTD3 belts (J1, J3, J4, J5)

Battery and Runtime

Power Supply
24 V DC, 5 A

Performance and tasks

Onboard Compute
PAROL6 control board v2.0. Functionally equivalent: v1.2.
Processor
STM32F446 with six TMC5160 stepper drivers
Repeatability
0.1 mm

Safety and Protection

Emergency Stop
Dedicated emergency-stop input

Interaction and Communication

External Port
Forearm: M8, 4 pins (24 V, GND, CAN H, CAN L) and two 4 mm air lines

Development and Expansion

Configuration Options
Assembled and tested arm (power supply, gripper and programming adapter per order). Assembly kit (printed parts and power supply separate). Partial kit (printed parts, power supply, gearboxes and motors separate per V1.1 manual). Open self-build files.
Integration Interface
USB serial at 3 Mbaud, 100 Hz host command cycle; CAN for electric grippers; two isolated inputs and two isolated outputs
Secondary Development (SDK)
Python API v0.9.1 reference, Python 3.11 or later

Open source & build resources

Software

Publicly available

Resources can be accessed; publication alone does not grant reuse rights.

Hardware design

Open source

Design files and a verified open license are available. Follow the terms of each resource.

Build resources

Complete

BOM, structure files and assembly instructions are available for the same version. Check each license before reuse.

TypeResourceLicenseApplicable versionOpen
HardwarePAROL6 V1.1 STL files

GitHub · Source-Robotics/PAROL6-Desktop-robot-arm

CERN-OHL-S-2.0V1.1Open GitHub
BOMPAROL6 V1.1 bill of materials

GitHub · Source-Robotics/PAROL6-Desktop-robot-arm

—V1.1Open GitHub
GuidePAROL6 V1.1 assembly instructions

GitHub · Source-Robotics/PAROL6-Desktop-robot-arm

—V1.1Open GitHub
CodePAROL6 control board firmware 1

GitHub · Source-Robotics/PAROL6-Desktop-robot-arm

—V1.1Open GitHub

Commercial Status

Status
Commercial
Price
EUR 3,570 (German storefront list price)
Release Date
Jul 2023

Timeline

  1. Robot release
    PAROL6
Submit a source or correction