Cyan Robotics logoCyan Robotics

ORCA

Orca I

Price
Unknown
Type
Humanoid Robots · Human-scale Humanoid
Status
Prototype
Availability
Not released
Purchase
Not disclosed
Release Date
Oct 30, 2024
Country/Region
China
Last Verified
2026-08-14
How classification and status work

Category describes physical structure and function; wheels alone do not determine whether a robot is humanoid. Product stage describes demonstrated maturity. Commercial availability describes current access: a commercial product may still be limited to pilot customers. Neither stage nor availability alone proves that a product can be purchased. Unknown facts remain unknown.

28 DOF
Total degrees of freedom
1.51 m
Height
42 kg
Weight
Approx. 5 kg per arm
General Payload

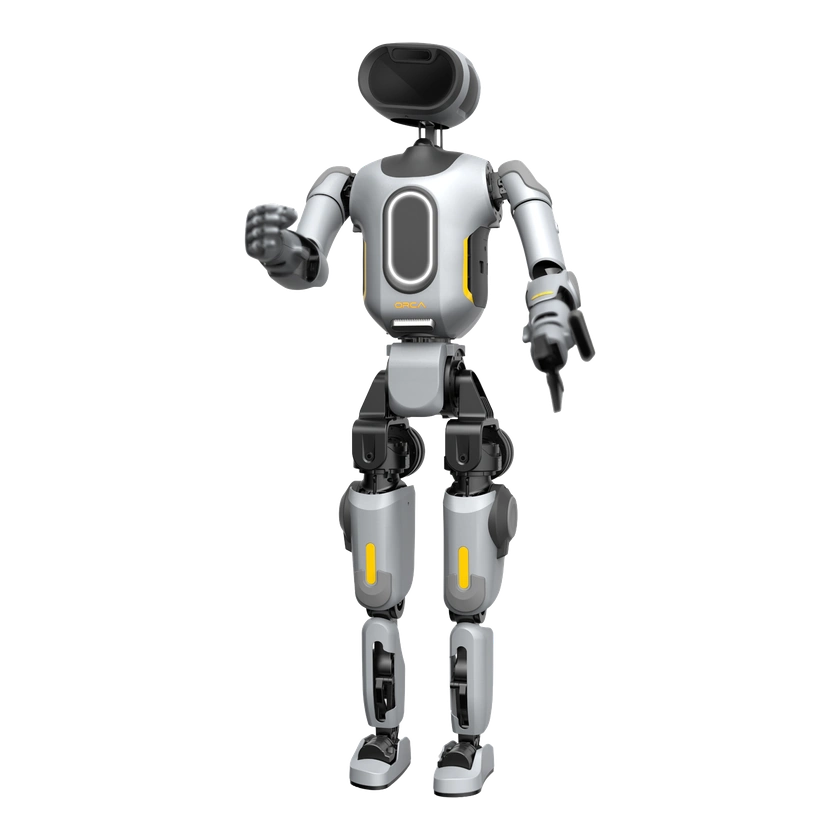
Orca I is Cyan Robotics’ humanoid robot with straight-knee bipedal motion, expressive gait and an external emotional display. It supports optional dexterous hands, open interfaces and whole-body teleoperation; specifications list 1.51 m height, 42 kg mass and 28 degrees of freedom.

1 / 1Orca I

Capability Map

MobilityDemonstrated
Walking

Cyan documents an Orca I dynamic video demonstrating walking, slope climbing, turning, gait recovery, and outdoor-road walking.
MobilityDemonstrated
Balance

Cyan documents Orca I gait recovery in walking and standing states in its dynamic video.

ManipulationDemonstrated
Grasping

Cyan documents precise, smooth dual-arm manipulation for Orca I in its official dynamic-video release.

InteractionDemonstrated
Speech interaction

Cyan documents natural-language interaction with emotional expression for Orca I in its official dynamic-video release.

Hardware Specification

Physical Specifications

Leg Length (Thigh + Shank)
0.84 m
Total degrees of freedom
28 DOF

Mobility & Payload

Single-arm Payload
5 kg per arm
Knee Joint Torque
150 N·m
General Payload
Approx. 5 kg per arm

Mechanical and mounting

Controllable DOF per Arm
6 DOF per arm
Depth
280 mm
Head DOF
3 DOF
Height
1.51 m
DOF per Leg
4 DOF per leg
Waist DOF
1 DOF
Weight
42 kg
Width
520 mm

Mechanical Structure

Cooling System
Local air cooling
Dexterous Hand
Optional dexterous hand
End-Effector
Dexterous hand with adaptive soft gripper
Joint Encoder
Dual encoders

Sensors

Depth Camera
Supported
IMU
Supported
LiDAR
3D LiDAR

Battery and Runtime

Hot-swap Support
5000 mAh × 2 fast-removable smart batteries
Power Supply
Dual lithium batteries
Runtime
1 h walking; 2 h standing
Runtime (Moving)
1 h

Compute Platform

CPU
14-core high-performance CPU
CPU Cores
14 cores
GPU
NVIDIA Jetson Orin Nano Super
Onboard Compute
14-core high-performance CPU; NVIDIA Jetson Orin Nano Super

Interaction and Communication

Communication
Wi‑Fi 6; Bluetooth 5.2
External Port
USB 3.0; Ethernet; 48 V
Microphone
Six-microphone circular array
Remote Controller
Supported
Speaker
Supported

Development and Expansion

Teleoperation
Open whole-body teleoperation interface

Commercial Information

Availability
Prototype

Commercial Status

Status
Prototype
Price
Unknown
Release Date
Oct 30, 2024

Timeline

  1. Robot release
    Orca I
Submit a source or correction