
Learning ApproachOfficial claim
Teleoperation
 Petoi
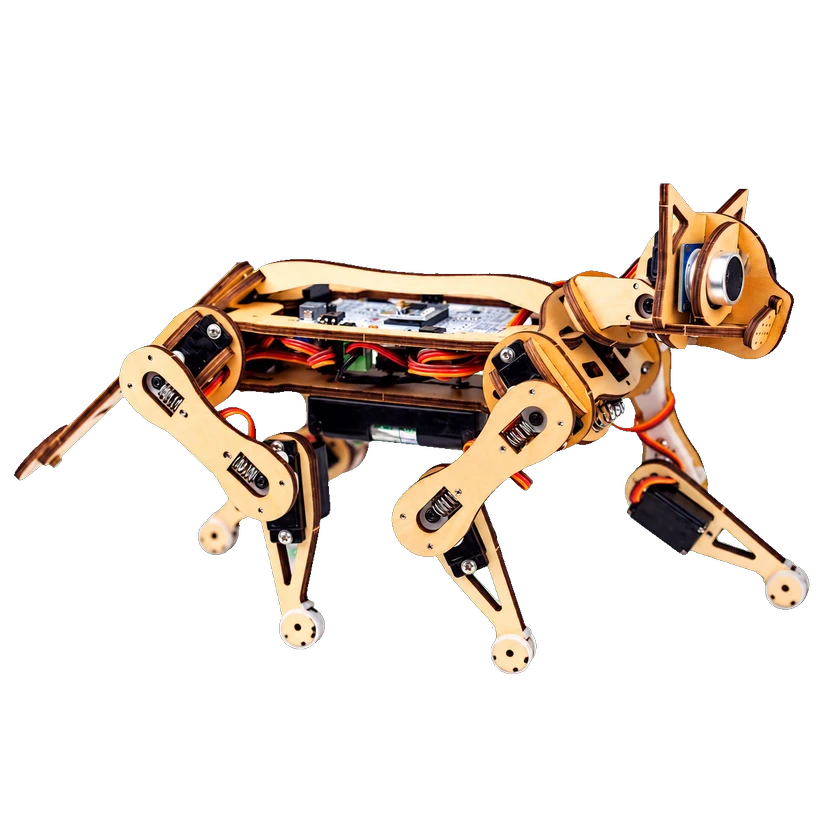
Nybble is Petoi’s open-source wooden robot cat kit for learning legged robotics. It combines 11 servo joints, ultrasonic sensing, an IMU, infrared control, mobile and desktop apps, and OpenCat programming. The modular platform supports Arduino, Python, block coding, and Raspberry Pi expansion for students, hobbyists, makers, and robotics educators.
Experiments do not imply factory configuration. Evidence applies only to the named model version.
Petoi's official FAQ lists balancing among Nybble's available robot-cat actions.
The official page states that Nybble can be controlled with the included infrared remote or Petoi mobile and desktop apps.
Nybble has model-scoped manufacturer programming documentation and serial Python/C++ interfaces. This is the legacy NyBoard model, using the NyBoard OpenCat build; the newer ESP32 Nybble Q/Bittle X V2 hardware is separate. Match the delivered board revision, servo variant, firmware model/calibration and host library. The reviewed body is the standard quadruped without an optional manipulation-arm add-on; legs are not counted as execution arms. Open source firmware/API code does not by itself license all hardware, dependencies or hosted assets.
Use the model-specific board firmware: NyBoard/ATmega328P, selecting the actual Bittle or Nybble model; NyBoard revisions may require different serial baud rates. Manufacturer Python docs specify Python>=3.6 and pyserial3.5; use the dependency versions of the matching checkout. The C++ CMake serial client exposes joint sequences/simultaneous targets, while Python m/M use calibrated degree targets and ASCII/binary framing. Configure actual port, power, servo offsets and active-index map: the logical16-slot packet is not16physical actuators. Native serial motion does not establish joint-velocity/torque/FF or map-navigation APIs. Distinguish commanded angle reporting from actual feedback; ESP32 f-feedback requires supported servo hardware.
Source and a verified open-source license are available. Follow the terms of each resource.
Official NyBoard V1.0 logic diagram, components and electrical interfaces. Applies to kits fitted with this board; complete robot fabrication files and hardware licensing remain unverified.
View explanationOfficial Nybble kit assembly steps with illustrations and video. Requires the kit parts; a complete independently sourced BOM and fabrication files remain unverified.
View explanationOpenCat-Quadruped-Robot · pinned MIT primary software files
CodeApplicable version: petoi_nybble_native_serialMIT
opencat_serial_cpp · pinned MIT primary software files
CodeApplicable version: petoi_nybble_native_serialMIT
ros_opencat · pinned MIT primary software files
CodeApplicable version: petoi_nybble_ros1_noetic_85962928MIT
ros_opencat ROS2 branch · pinned MIT code
CodeApplicable version: petoi_nybble_ros2_bdec9d34MIT
OpenCat firmware (NyBoard)
CodeMIT
NyBoard V1.0 controller interfaces
Hardware
Petoi Desktop App: setup and calibration
Tool
OpenCat Python serial-control guide
Guide
No related products recorded yet.

