
 Elephant Robotics
MS Joint Modules
- Output speed
- 16 rpm
- Outer diameter
- 162 mm
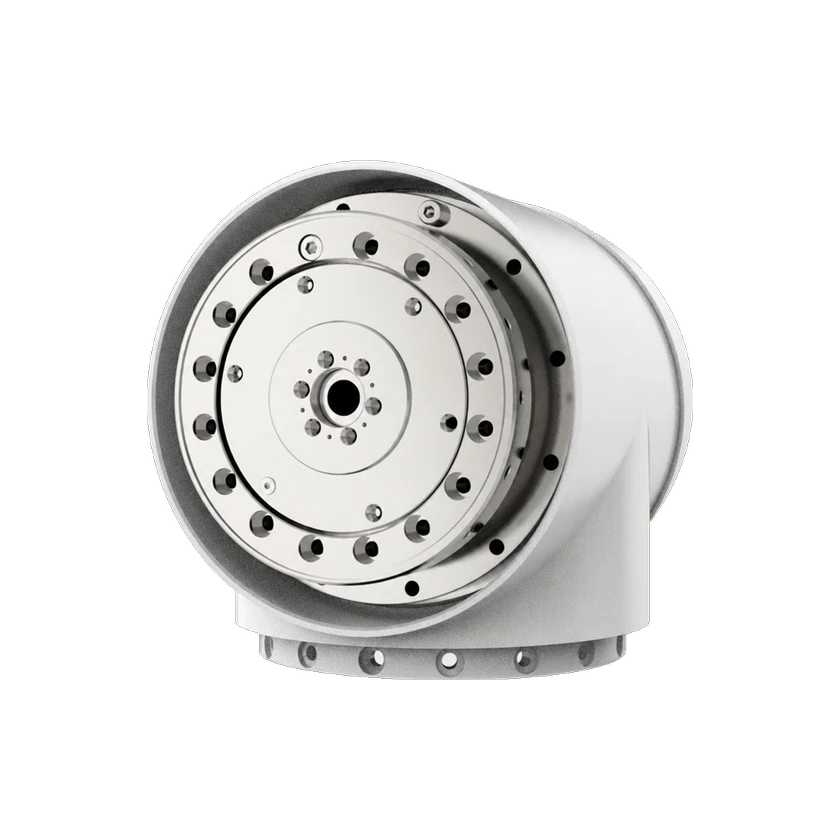
MS32 is Elephant Robotics’ official-shell integrated joint module for customizable collaborative robots. It uses CoE communication, delivers 243 N·m continuous torque with a 161 reduction ratio, and carries IP54 protection. Price and stock availability are not disclosed.
Technical specifications
Values use consistent engineering units.
Output & transmission
- Output torque
243 N·m
- Output torque
610.85 N·m
- Output speed
16 rpm
Dimensions & installation
- Outer diameter
162 mm
- Hollow bore diameter
12 mm
- Tilting moment
460 N·m
- Tilting moment
900 N·m
Electrical
- Operating current
21 A
- Operating current
50 A
Encoders & feedback
- Encoder resolution
19 bit
- Encoder counts per revolution
Not reported
Not reported
Communication & control
- Communication protocol
CoE (CANopen over EtherCAT)
Braking & environment
- Brake type
Electromagnetic friction disc brake
Construction & components
- Motor integration
Integrated
- Reducer integration
Integrated
- Encoder integration
Integrated
- Brake integration
Integrated
Open source & build resources
Software
Not verifiedThere is not enough verified evidence to establish this dimension.
Hardware design
Partial hardware documentationThe official page provides “MS Module User Manual” V1.0 in Downloads. Covers MS14/17/20/25/32 mounting dimensions, drive connectors and module integration. Match the delivered driver/configuration. Copyright is reserved; copying or translation requires written permission. Not module manufacturing CAD, firmware or a complete robot-build package.
View explanationBuild resources
Not verifiedThere is not enough verified evidence to establish this dimension.
| Type | Resource | License | Applicable version | Open |
|---|---|---|---|---|
| Hardware | MS-series installation, wiring and dimension manual elephantrobotics.com The official page provides “MS Module User Manual” V1.0 in Downloads. Covers MS14/17/20/25/32 mounting dimensions, drive connectors and module integration. Match the delivered driver/configuration. Copyright is reserved; copying or translation requires written permission. Not module manufacturing CAD, firmware or a complete robot-build package. | — | MS32 (MS-series user manual V1.0) | Open documentation |
Commercial Status
Related Entities
No related products recorded yet.