
Robot experiments / deployment
OpenVLA 7B
Vision-language-action model · 2024-06-13
 Trossen Robotics
A six-degree-of-freedom Interbotix robot arm with a 250 g working payload.
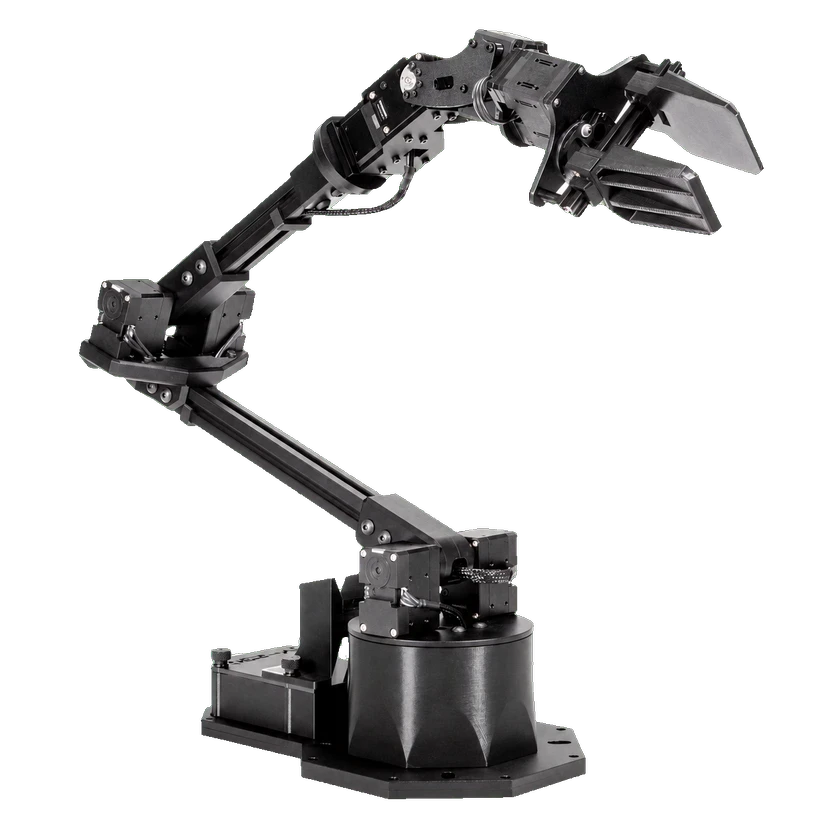
Experiments do not imply factory configuration. Evidence applies only to the named model version.
Development configuration: wx250s with Interbotix ROS interface
Exact documented development profile. Hardware, firmware and access conditions are recorded per capability.
Requires the Interbotix ROS interface. This Python API does not support Gazebo simulation robots.
Cartesian control and Position commands · Interbotix Python-ROS pose/trajectory functions with a valid IK solution and model joint limits. This Python API does not support Gazebo simulation robots.
Examples or supporting tools are available; this does not establish access to the core system.
There is not enough verified evidence to establish this dimension.
There is not enough verified evidence to establish this dimension.
Experiments do not imply factory configuration. Evidence applies only to the named model version.

