
 Fairino (Suzhou) Robot Technology Co., Ltd.
FM-B General-Purpose Humanoid Joint Modules
- Output torque · Rated
- 24 N·m
- Output speed · Rated
- 25 rpm
- Weight
- 1.054 kg
- Outer diameter
- 80 mm
The FAIRINO FM-17-B is a non-force-controlled integrated joint for humanoid robots and robotic arms. It runs on 48 V with EtherCAT, supports a brake, and has a 12 mm hollow bore for routing cables. It uses dual 18-bit absolute encoders. Rated torque is 24 N·m and rated output speed is 25 rpm.
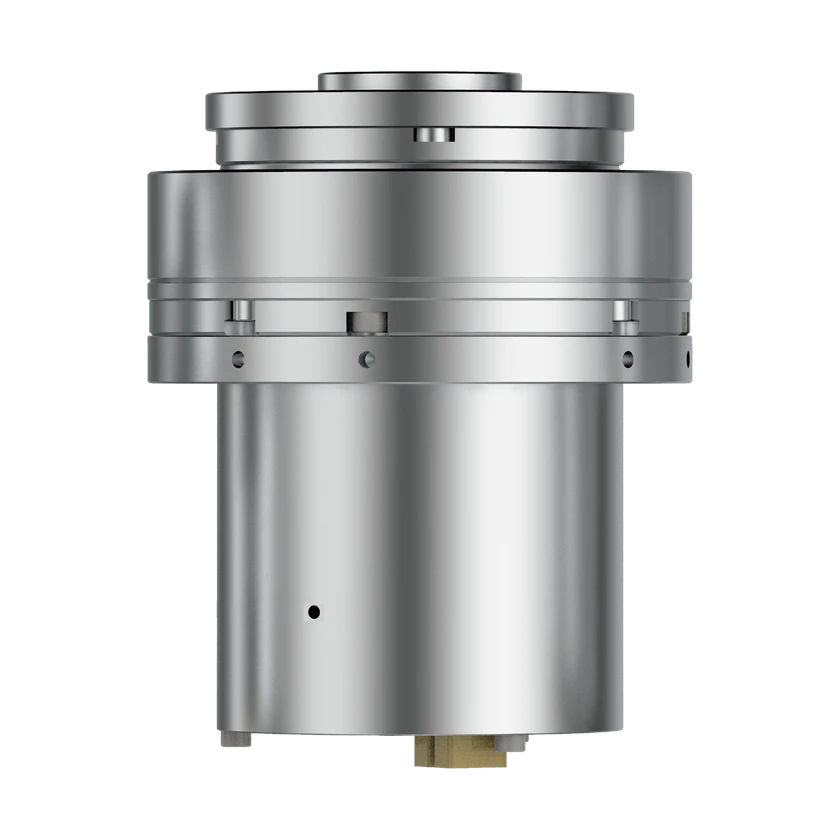
Technical specifications
Output & transmission
- Output torque · Rated
24 N·m
- Output torque · Average load
39 N·m
- Output torque · Maximum
86 N·m
- Output speed · Rated
25 rpm
Scope not bound
Dimensions & installation
- Weight
1.054 kg
- Rated torque density
22.77 N·m/kg
Based on net joint mass
- Outer diameter
80 mm
Scope not bound
- Axial length
97.4 mm
Scope not bound
- Hollow bore diameter
12 mm
Scope not bound
Electrical
- Operating voltageDC power input
48 V
Encoders & feedback
- Encoder type
Dual absolute encoders
Scope not bound
- Encoder resolution
18 bit
Scope not bound
Communication & control
- Communication interface
EtherCAT
- Communication protocol
CiA 402 control word
Scope not bound
- Control mode
Cyclic synchronous position / Speed mode via the RS-485 debug interface
Scope not bound
Other specifications
- Connector type
GHR-04V-S (EtherCAT harness)
Scope not bound
- Connector type
XT30 series (power harness)
Scope not bound
Model-level records · configuration applicability unverified
- Position error
- Repeat positioning accuracy ±15″
- Lead time
- 6 weeks
- Public contact link
- FAIRINO Europe sales inquiries
- Companion software
- DynamicLAB
- Ingress Protection (IP)
- Standard IP testing not performed
- Mounting interface
- 12 × M3 on Ø54 mm and 12 × Ø3.5 mm on Ø74 mm
- Gear Ratio
- 120:1
- Operating voltage · Rated
- 48 V
- Rated power
- 200 W
- Torque Density · Rated · Original specification
- 22.77 N·m/kg · Pending verification
- Operating humidity
- 20–90 %RH
- Operating temperature
- 0–45 °C
Source · 10
2026-11-22
Weight · 1054 g · 3.3
Communication interface · EtherCAT · 3.3
Axial length · φ80*97.4 · 3.3
Hollow bore diameter · 12 mm · 3.3
Outer diameter · φ80 · 3.3
Output speed · 25 rpm · 3.3
Output torque · Rated Torque · 24 N·m · 3.3
Output torque · Average Load Torque · 39 N·m · 3.3
Output torque · Maximum Torque · 86 N·m · 3.3
Rated torque density · 24 N·m
Rated torque density · 1.054 kg
Position error · Repeat Positioning Accuracy: ±15 arcsec
Gear Ratio · 120
Operating voltage · Rated Voltage: 48 V
Rated power · Rated Power: 200 W
Torque Density · 24 N·m ÷ (1054 g ÷ 1000) = 22.770398… N·m/kg
Operating temperature · 0–45 °C
2026-11-22
Connector type · GHR-04V-S; drawing: 2.0 mm pitch · 5.3, Figure 5-3-2
Connector type · XT30UPB30-M. G. * · 5.3, Figure 5-3-1
2026-11-22
Operating voltage · Power Supply: 48 V · 2. Product and Delivery Information
Lead time · 6 weeks
Public contact link · FAIRINO Europe sales inquiries
Ingress Protection (IP) · Standard IP testing not performed
2026-11-22
Control mode · Speed mode via the RS-485 debug interface · 7.5
2026-11-22
Encoder resolution · Encoder Accuracy (bit): 18 · PDF p. 2, non-force-controlled FM-17-B
Encoder type · Dual absolute encoders · PDF p. 2, non-force-controlled FM-17-B
2026-11-22
Mounting interface · 12 × M3 on Ø54 mm and 12 × Ø3.5 mm on Ø74 mm
Compare family models
Choose 2–4 configurations
Compare selected configurations| Technical specifications | FM-11-BFM-11-B | FM-14-BFM-14-B |
|---|---|---|
| Weight | 0.42 kg | — |
| Operating voltage | 48 V | — |
| Communication interface | EtherCAT | — |
| Communication protocol | CiA 402 | — |
| Outer diameter | 52 mmScope not bound | 70 mmScope not bound |
| Output speed · Rated | 30 rpm | — |
| Output torque · Rated | 3.7 N·m | — |
| Output torque · Average load | 6.2 N·m | — |
| Output torque · Maximum | 17.5 N·m | — |
| Rated torque density | 8.81 N·m/kg Based on net joint mass | — |
| Communication interface | — | EtherCATScope not bound |
| Communication protocol | — | CiA 402 control wordScope not bound |
Commercial Status
Related Entities
No related products recorded yet.
Timeline
- Robot releaseFM-17-B