Fairino (Suzhou) Robot Technology Co., Ltd.
FM-11-B · FM-11-B
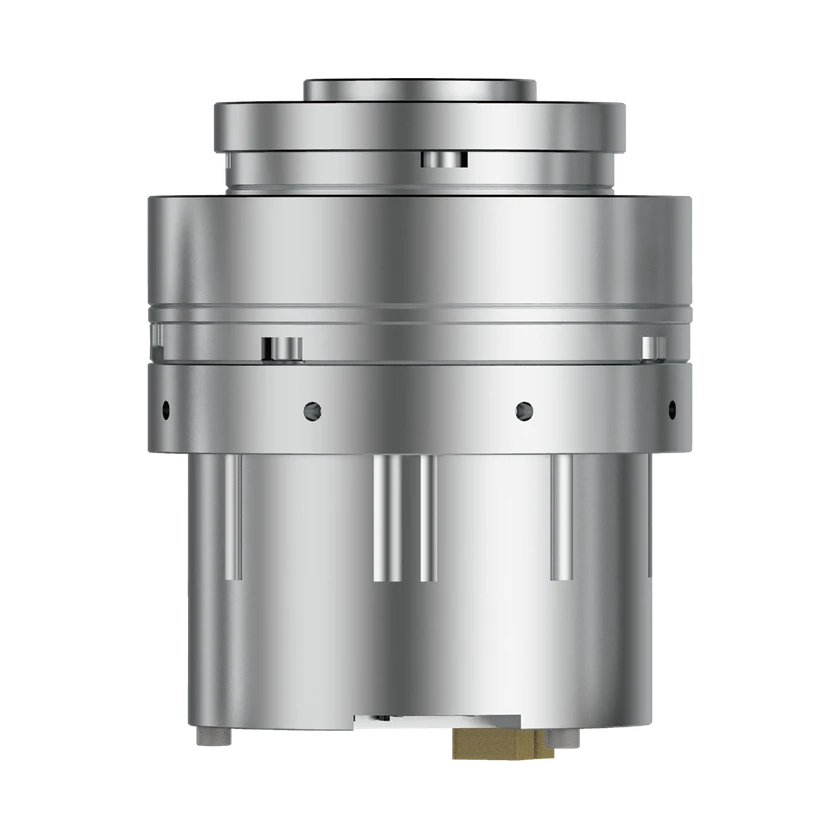
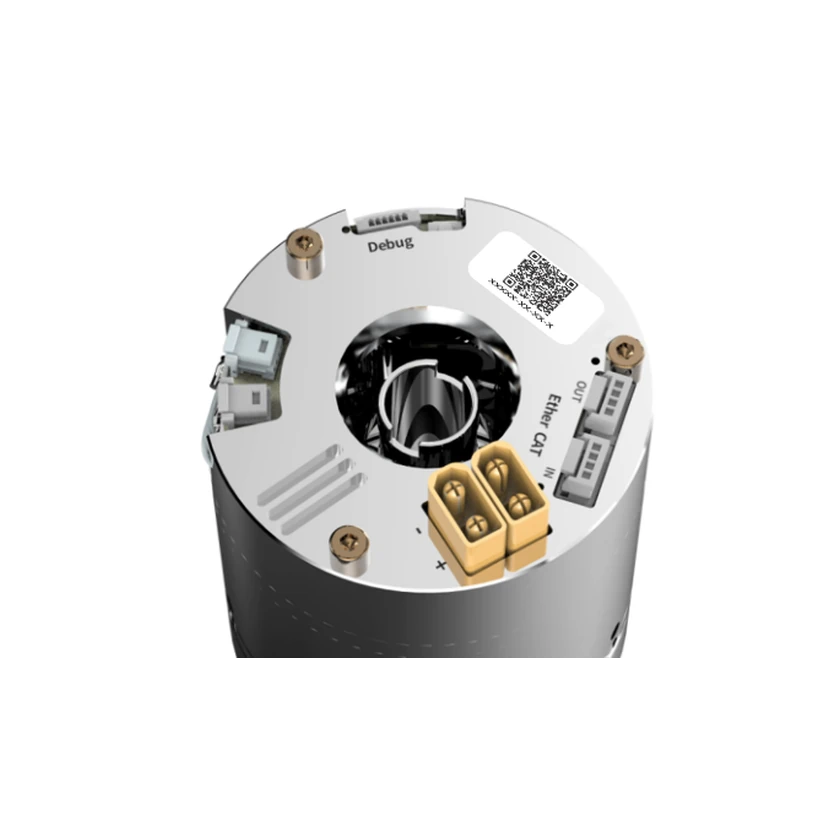
FM-B General-Purpose Humanoid Joint Modules
- Status
- Commercial
- Release
- Oct 15, 2026
- Price
- Price not disclosed
- Warranty
- 1 year
Compare 2–4 models or configurations. Rated, continuous and peak values use different conditions; check the sources before comparing.
Experiments do not imply factory configuration. Evidence applies only to the named model version.
FM-B General-Purpose Humanoid Joint Modules · FM-11-B · FM-11-B
Rated torque density / Weight / Operating voltage · nominal / Communication interface / Axial length / Outer diameter / Hollow bore diameter / Output torque · Average load / Output torque · Maximum / Output torque · Rated / Output speed · Rated
Verified · 2026-11-22
FM-B General-Purpose Humanoid Joint Modules · FM-11-B · FM-11-B
Communication protocol
Verified · 2026-11-22
FM-B General-Purpose Humanoid Joint Modules · FM-11-B · FM-11-B
Control mode
Verified · 2026-11-22
FM-B General-Purpose Humanoid Joint Modules · FM-14-B · FM-14-B
Control mode
Verified · 2026-11-22
FM-B General-Purpose Humanoid Joint Modules · FM-11-B · FM-11-B
Control mode
Verified · 2026-11-22
FM-B General-Purpose Humanoid Joint Modules · FM-14-B · FM-14-B
Control mode
Verified · 2026-11-22
FM-B General-Purpose Humanoid Joint Modules · FM-14-B · FM-14-B
Model-level weight · configuration applicability unverified / Communication interface / Axial length / Outer diameter / Hollow bore diameter
Verified · 2026-11-22
FM-B General-Purpose Humanoid Joint Modules · FM-14-B · FM-14-B
Connector type
Verified · 2026-11-22
FM-B General-Purpose Humanoid Joint Modules · FM-14-B · FM-14-B
Communication protocol
Verified · 2026-11-22
FM-B General-Purpose Humanoid Joint Modules · FM-14-B · FM-14-B
Reducer integration
Verified · 2026-11-22
FM-B General-Purpose Humanoid Joint Modules · FM-14-B · FM-14-B
Encoder integration
Verified · 2026-11-22