
 Tsinghua University
9DTact
Price
Unknown
Type
Components · Tactile sensors
Status
Prototype
Availability
Not disclosed
Purchase
Not disclosed
Release Date
Unknown
Country/Region
China
- Signal frequency · image
- 90 Hz
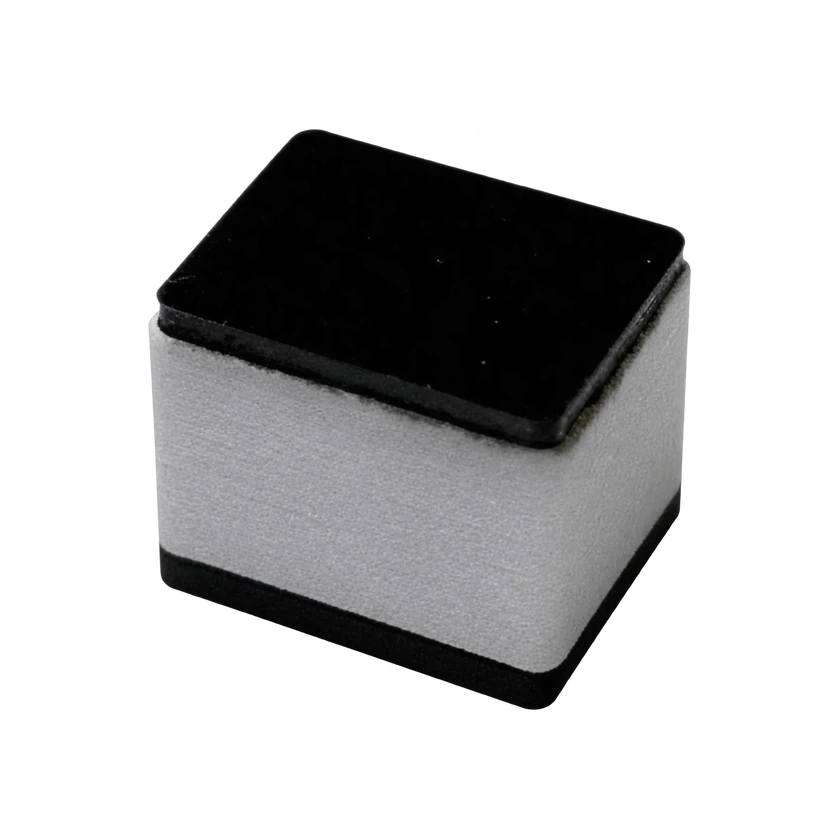
9DTact is a compact vision-based tactile prototype developed by researchers affiliated with Shanghai Qi Zhi Institute, Tsinghua University, Huazhong University of Science and Technology, and Shanghai Artificial Intelligence Laboratory. A camera captures silicone deformation under white LEDs to reconstruct 3D contact geometry and estimate three-axis force and torque. Hardware files, calibration scripts and ROS examples are public.
Technical specifications
Sensing capabilities and principle
Derived capabilities
3D contact geometry
Derived capabilities
Three-axis force and three-axis torque estimation
Direct sensing
Gel deformation
Sensing method
White LEDs and a camera image unmarked silicone gel
Sensing principle
Camera-based optical
Measurement performance
Signal frequency · Image
90 Hz
Structure and dimensions
Active sensing area
24 × 18 mm (432 mm²)
Mounting position
Robot fingers
Mounting position
Gripper jaws
Physical form
Flat tactile pad in rigid housing
Output and communication
Connector
CSI or CSI-to-USB adapter
Connector
USB Micro-B for LED power
Data output
Tactile image
Software and export
Software openness
Open source
Software, export and openness
Hardware openness
CAD and LED PCB design files
License and usage terms
MIT at repository root
First-person and visual capture
Camera intrinsics and extrinsics
Camera and depth calibration scripts
Related entities and public cases
Publicly documented uses
Allegro Hand, DoraHand, Robotiq Gripper, Franka Gripper
Publicly documented uses
Insufficient evidence
Other technical parameters
Record type
Open hardware research project
Other technical parameter
Camera input 640 × 480 px
Other technical parameter
Rectified crop 460 × 345 px
Other technical parameter
Example capture setting 30 fps
Other technical parameter
Held-out object force MAE 0.35 / 0.40 / 0.41 N
Other technical parameter
Held-out object torque MAE 0.011 / 0.010 / 0.002 N·m
Other technical parameter
Sphere-test depth MAE 0.0462 mm
Other technical parameter
Image-callback-driven wrench output
Other technical parameter
Sample acceptance window Fx/Fy ±3 N; Fz −12 to 0 N; Tx/Ty ±0.3 N·m; Tz ±0.05 N·m
Other technical parameter
Training normalization window Fx/Fy ±3 N; Fz −12 to 0 N; Tx/Ty ±0.2 N·m; Tz ±0.05 N·m
Other technical parameter
Example calibrated pixel scale 0.0510 / 0.0500 mm/px
Physical Specifications
Frame Material
Nylon base and shell
Mechanical and mounting
Height
2.55 cm
Length
3.25 cm
Mounting interface
Four M2 heat-set inserts
Weight
0.02 kg
Width
2.55 cm
Sensors
Camera
OV5647, 160° field of view
Battery and Runtime
Power Supply
5 V USB for the LED board
Power Supply
Insufficient evidence
Commercial Status
Status
Prototype
Price
Unknown
Release Date
Unknown
Related Entities
No related products recorded yet.
Video
Watch on YouTube
Submit a source or correction