Robot
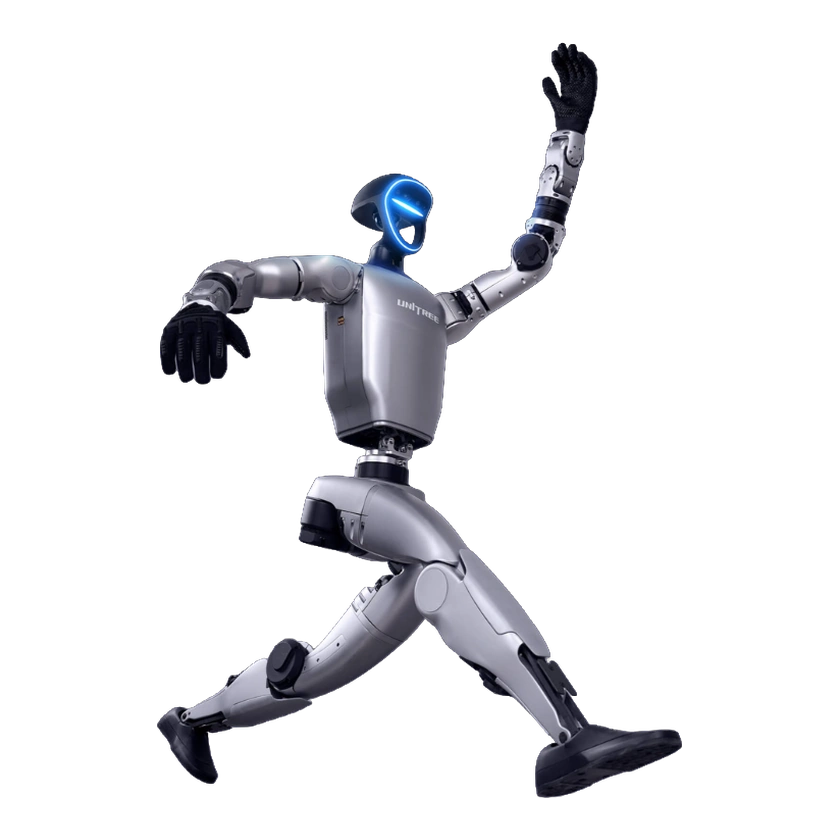
G1
Related versions 4
GR00T N1.7 ↗Support statement · Simulation / software configuration
NVIDIA documents a pretrained G1 configuration tag for the N1.7 base model. · Official G1 simulation workflow fine-tunes GR00T N1.7 on apple-to-plate demonstrations.
REAL_G1 uses relative end-effector and joint-state modalities. Input data must match the pretrained embodiment; inference hardware is not established by this configuration table.
Simulation/software configuration only; this source does not establish real-robot validation or factory-installed software.