
Unitree Robotics logoUnitree Robotics

Go1 Edu

가격
가격 비공개
유형
4족 보행 로봇 · 소비자용 4족 로봇
적용 시나리오
연구 및 교육 · Education Platform / 연구 및 교육 · 연구 플랫폼
상태
상용
구매 가능 여부
판매 중
구매 방식
미공개
공개일
2021년 6월
국가/지역
중국
6 kg
일반 페이로드
3.7 m/s
보행 속도
12 kg
무게

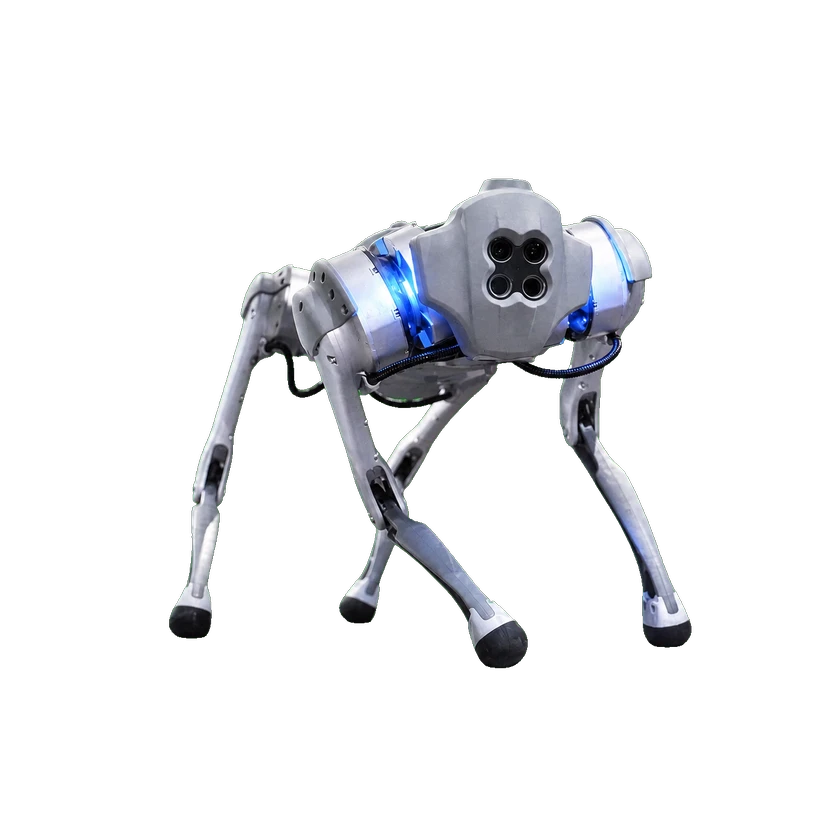
Go1 Edu는 센싱 카메라 5쌍, 6kg 적응형 적재량, 최대 3.7m/s 이동 속도, Python 및 과학 프로그래밍 인터페이스, 사람 감지 및 선택형 레이더를 갖춘 교육·개발 버전입니다.

Go1 Edu

하드웨어 사양

물리적 사양

접었을 때 치수
0.588 × 0.22 × 0.29 m
기계 관절 수
12
이동 방식
생체 모방 사족 이동

이동성 및 페이로드

최고 속도
0–3.7 m/s
일반 페이로드
6 kg
보행 속도
3.7 m/s

기계 및 장착

무게
12 kg

기계 구조

냉각 시스템
히트파이프 보조 방열
관절 유형
은 합금 정밀 관절 모터

센서

카메라
어안 양안 깊이 카메라
깊이 카메라
5쌍
센서 시야각
약 150 × 170°
위치 측정 모듈
ISS Intelligent Concomitant System
조명(감지용)
양안 깊이 감지를 위해 충분한 주변 조명을 권장합니다.
센서
SSS 슈퍼 센싱 시스템, 어안 양안 깊이 감지, 초음파 감지

배터리 및 작동 시간

배터리 유형
단일 배터리 팩
충전기
24V, 6A

컴퓨팅 플랫폼

GPU
384코어 GPU, 1.5 TFLOPS
온보드 컴퓨팅
16코어 CPU + GPU, 384코어 GPU 및 1.5 TFLOPS

상호작용 및 통신

스마트 추종
ISS 무선 벡터 위치 추정을 통한 지능형 추종
원격 컨트롤러
포함됨
영상 전송
RTT 이미지 전송

개발 지원

Go1 Edu현재 모델

조건부 개방

The manufacturer explicitly documents developer APIs for Go1. Use the model-specific SDK and compatible firmware. Navigation requires the separately delivered navigation stack and applicable sensor configuration.

개발 구성: Go1 SDK v3.8.6

Firmware and developer-access prerequisites apply. This SDK profile does not include the optional navigation software.

개발 기능

관절 수준 제어조건부 지원
Python SDK조건부 지원
C++ SDK조건부 지원
위치 명령조건부 지원
속도 명령조건부 지원
PD + 피드포워드 토크조건부 지원
직접 토크 명령조건부 지원

Only the model-specific SDK revision, compatible firmware/sport package, and authorized low-level developer access. Torque example explicitly sets Kp/Kd=0 and applies commanded torque; no claim about all motor operating ranges or purchased edition.

문서화된 제약

  • Navigation interfaces are not part of this public GitHub locomotion SDK; obtain the manufacturer-delivered navigation software and matching LiDAR configuration.
출처 · 5

오픈 소스 및 제작 자료

소프트웨어

일부 공개

예제나 보조 도구만 공개되어 있으며 핵심 시스템의 공개를 의미하지 않습니다.

하드웨어 설계

미검증

이 항목을 판단할 검증된 근거가 부족합니다.

제작 자료

미검증

이 항목을 판단할 검증된 근거가 부족합니다.

유형자료라이선스적용 버전열기
코드Go1 legacy SDK examples and wrappers

GitHub · unitreerobotics/unitree_legged_sdk

Repository license applies to these files. Prebuilt core, dependencies, firmware, hardware and access rights are separate; this link does not assert whole-robot open source.

BSD-3-Clauselegged_sdk_v3_8_6열기 GitHub

상용화 상태

상태
상용
가격
가격 비공개
공개일
2021년 6월

배치 기록

상태는 과거 자료에 기반하며 이후 운영 상황은 알 수 없습니다.

배치 기록 1 · 시범 운영 1 · 프로젝트 실제 대수 · 미공개

협력 주체
Carnegie Mellon University · 운영사
적용 분야
연구 플랫폼
주요 작업
Integrate sensing and compute equipment with a Unitree Go1 Edu and test autonomous exploration and navigation in narrow, cluttered indoor environments for an assistive search-and-rescue research project.이동 시험
위치
미공개
시작
2023
최근 검증
2026-10-13
근거 범위

The 2023 MRSD project identifies the exact Go1 Edu model, distinguishes real-world robot control from simulation, and reports autonomous exploration tests in narrow, cluttered environments. This is a university research field test, not a rescue operation or customer deployment. The exact test site and dates, payment, unit count, and current operation are not disclosed.

배치 타임라인 · 1

  1. Autonomous indoor exploration tests with the Go1 Edu
검증된 자료 기준이며 실시간 운영 상태가 아닙니다.2026-10-13

타임라인

  1. 로봇 공개
    Go1 Edu
출처 또는 수정 제안 보내기