
 Unitree Robotics
GO-M8010-6
- 출력 회전 속도 · 최대
- ≤286.4789 rpm
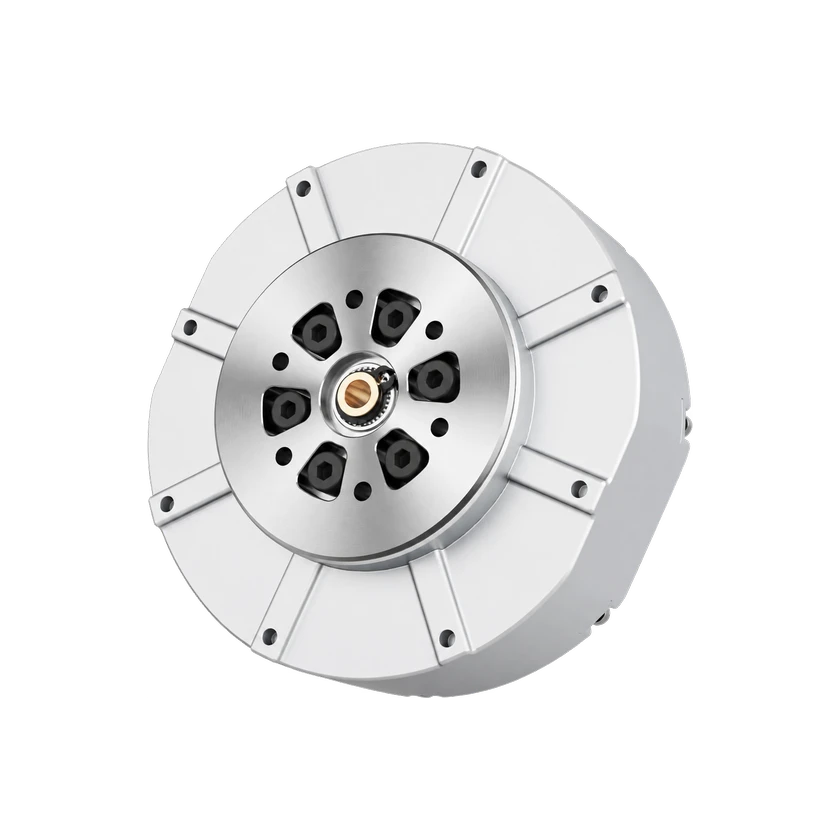
GO-M8010-6은 Unitree의 일체형 영구자석 동기 관절 모터입니다. 감속기, FOC 제어, 온도 센서와 절대형 엔코더를 통합하고 RS-485 통신을 지원하여 로봇 개발, 대회, 연구 및 교육에 활용할 수 있습니다.
기술 사양
출력 및 전달
- 출력 토크 · 최대
≤23.7 N·m
범위 미지정
- 출력 회전 속도 · 최대
≤286.4789 rpm
범위 미지정
24 V DC
전기 사양
- 동작 전류 · 최대
≤40 A
범위 미지정
엔코더 및 피드백
- 엔코더 유형
절대형 엔코더
범위 미지정
- 엔코더 분해능
15 bit
범위 미지정
- 피드백 신호
토크 / 각도 / 각속도 / 온도
범위 미지정
통신 및 제어
- 통신 인터페이스
RS-485
범위 미지정
- 제어 모드
토크 / 위치 / 속도
범위 미지정
- 명령 주기
6000 Hz
범위 미지정
구조 및 통합 부품
- 모터 유형
영구자석 동기 모터
범위 미지정
- 모터 통합 상태
내장
범위 미지정
- 감속기 통합 상태
내장
범위 미지정
- 엔코더 통합 상태
내장
범위 미지정
- 제어기 통합 상태
내장
범위 미지정
기타 사양
- SDK 언어
C++
범위 미지정
- SDK 언어
Python
범위 미지정
모델 기록 · 구성 적용 범위 미확인
- 개발 접근 권한
- 조건부 지원
- 무게
- 0.53 kg
- 감속비
- 6.33:1
- 작동 전압
- 12–30 V
- 작동 전압
- 24 V
- 소프트웨어 알고리즘
- 자속 지향 제어(FOC)
- 작동 온도
- -5–40 °C
- 통신
- 4 Mbps
출처 · 3
2026-09-23
명령 주기 · 通信控制频率6000Hz
통신 인터페이스 · RS-485
제어 모드 · 토크
제어 모드 · 위치
제어 모드 · 속도
피드백 신호 · 토크
피드백 신호 · 각도
피드백 신호 · 각속도
피드백 신호 · 온도
엔코더 분해능 · 15 bit
엔코더 유형 · 절대형 엔코더
제어기 통합 상태 · 내장
엔코더 통합 상태 · 내장
모터 통합 상태 · 내장
감속기 통합 상태 · 내장
모터 유형 · 영구자석 동기 모터
동작 전류 · 最大相电流 · ≤40 A
출력 회전 속도 · 30rad/s (24V供电时)
출력 토크 · 最大扭矩23.7NM;减速比6.33;24℃下测得
무게 · 约530g
감속비 · 1:6.33
작동 전압 · 12–30 V
작동 전압 · 24 V
소프트웨어 알고리즘 · 자속 지향 제어(FOC)
작동 온도 · -5–40 °C
통신 · 通信波特率 4Mbps
개발 지원
GO-M8010-6현재 모델
조건부 개방GO-M8010-6: official unitree_actuator_sdk 5b79a42d C++ and Python examples, compatible motor firmware, high-speed RS485 adapter, power and configured ID are required. The older manufacturer-authored manual is hosted by distributor TechShare; the former official dev-motor site failed DNS lookup. Its legacy Go2/T/W/Pos identifiers are not the current API. Commands use motor-rotor coordinates before the reducer.
GO-M8010-6 cpp profile at 5b79a42d. Manufacturer manual gives rotor torque = feedforward + Kp position error + Kd velocity error; Kp=Kd=0 is direct rotor Nm torque and Kp=0/Kd>0 is velocity tracking. Current GO examples select the exact motor enum and queried FOC mode; C++ uses negative and Python positive example velocity, so they are not identical motion programs. Convert output position/speed using the model gear ratio and output-side gains using ratio squared per README; header output-coordinate wording conflicts with README/manual rotor wording. Verify actual firmware/binary convention before calibrated output-side Nm use; packet fixed-point encodings differ from SDK floats. Older manual API/Go2 symbol and A1/B1 gain factors must not be copied. Prebuilt core/ABI and callback validity/error handling require matching delivery; sleep200us is not measured control frequency, send/feedback is not arrival. No SDK build or motor command was executed.
개발 기능
출처 · 3
- 공식raw.githubusercontent.com ↗확인일: 2026-11-06
- 공식raw.githubusercontent.com ↗확인일: 2026-11-06
- 공식techshare.co.jp ↗확인일: 2026-11-06
오픈 소스 및 제작 자료
소프트웨어
일부 공개예제나 보조 도구만 공개되어 있으며 핵심 시스템의 공개를 의미하지 않습니다.
하드웨어 설계
미검증이 항목을 판단할 검증된 근거가 부족합니다.
제작 자료
미검증이 항목을 판단할 검증된 근거가 부족합니다.
| 유형 | 자료 | 라이선스 | 적용 버전 | 열기 |
|---|---|---|---|---|
| 코드 | unitree_actuator_sdk · scoped primary-code license GitHub · unitreerobotics/unitree_actuator_sdk Complete pinned BSD3 grant for the reviewed visible primary Unitree examples/headers/wrapper source. No independent claim is made for prebuilt core binaries, device firmware/hardware, manual redistribution or dependencies; match their delivery terms and ABI. No whole-motor open-source assertion. | BSD-3-Clause | go_m8010_6_cpp_5b79a42d, go_m8010_6_python_5b79a42d | 열기 GitHub |
| 코드 | GO-M8010-6 모터 SDK 및 예제 GitHub · unitreerobotics/unitree_actuator_sdk 공식 SDK는 GO-M8010-6과 C++·Python 예제를 제공합니다. 모터 유형과 회전자·출력 측 변환 규칙을 확인해야 합니다. 모터 펌웨어나 제조 설계는 포함하지 않습니다. | BSD-3-Clause | GO-M8010-6 | 열기 GitHub |
상용화 상태
관련 항목
등록된 관련 제품이 없습니다.