Universal Robots logoUniversal Robots

g-Series

Price
Price not disclosed
Type
Robot Arms
Status
Commercial
Availability
Not disclosed
Release Date
Sep 14, 2026
Country/Region
Denmark
15 kg
General Payload
130 cm
Reach
±0.05 mm
Repeatability
6 DOF
Total degrees of freedom

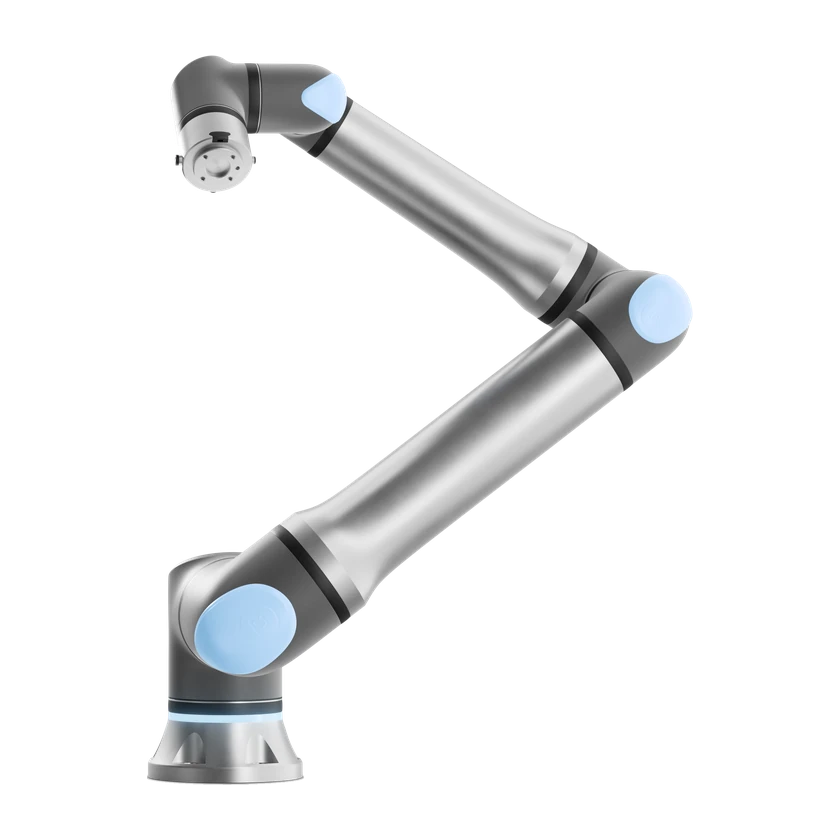
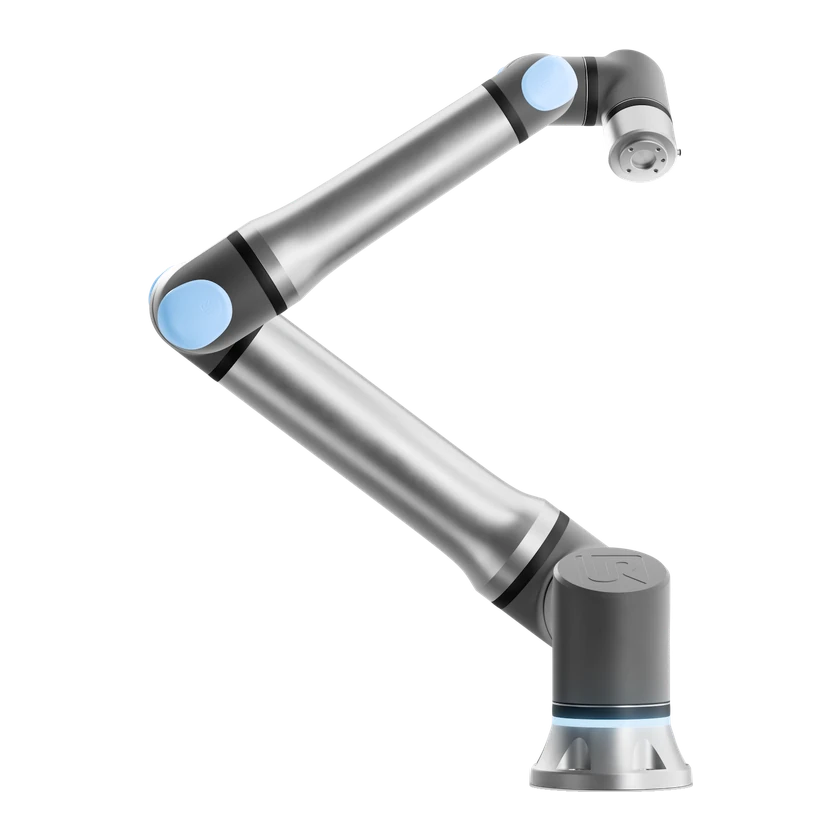
The UR17g-1300 is a Gen 7 industrial collaborative robot arm and the successor to the UR15. Its six rotary joints provide 1,300 mm of reach and a rated payload of 15 kg. The tool flange integrates force and torque sensing, Ethernet and dedicated power.

UR17g-1300

Configurations

Robot arm

Communication and control

Control loop rate
500 Hz
Hardware Specification

Connectivity and development

API and protocol documentation
RTDE

Physical specifications and power

Mounting or wearing method
Any orientation
Typical power consumption
350 W

Software, export and openness

Companion software
PolyScope X · CB7 Core / Core Compact / Core Compact 0.55 m
Companion software
URSim Desktop 1.10 · PolyScope X 10.15 (simulation)
Companion software
Universal Robots ROS 2 Driver 7.3.0 · ROS Rolling
Companion software
Universal Robots ROS 1 Driver
License and usage terms
ROS 2 URDF / g-Series meshes
SDK versions and download links
PolyScope X SDK 0.22.142-preview · PolyScope X 10.15

Force, touch and feedback

Force measurement range
-150 N – 150 N
Force and torque sensor setup
Per axis: force precision ±7.5 N, accuracy ±8.3 N. Torque precision ±0.2 N·m, accuracy ±0.5 N·m.
Torque measurement range
-10 N·m – 10 N·m

Degrees of freedom and drive

Ingress Protection (IP)
IP65
Mechanical joint count
6
Materials
Aluminium, plastic, steel
A-weighted Noise Level
<55 dB(A)
Total degrees of freedom
6 DOF

Mobility & Payload

Max Speed
5 m/s
General Payload
15 kg
General Payload
17.5 kg
Reach
130 cm

Mechanical and mounting

Mounting flange standard
ISO 9409-1-50-4-M6
Mounting interface
6 × M10, 45 Nm, flat and clean mounting surface
Weight
43.4 kg
Weight
40.7 kg

Mechanical Structure

Joint Motion Range
-360° – 360°
Joint Type
Rotary joints

Sensors

Force/Torque Sensor
Integrated tool-flange force/torque sensor

Battery and Runtime

Max Power
550 W

Performance and tasks

Repeatability
±0.05 mm

Reliability and environment

Certifications
TÜV Rheinland EN ISO 13849-1
Certifications
TÜV Rheinland EN ISO 10218-1
Operating humidity
≤90 %RH
Operating temperature
0–50 °C
Safety System
23 configurable safety functions

Interaction and Communication

Communication
Modbus TCP / EtherNet/IP Adapter / PROFINET
Communication
PROFIsafe
Communication
OPC UA
Remote Controller
TP7 teach pendant
Remote Controller
Optional tool-side SP7 Smart Panel

Development and Expansion

Integration Interface
M8-8 A-coded I/O, M8-4 A-coded power, M12 X-coded 1 GbE
Integration Interface
M8 I/O: 2 DI or 1 safety input, 2 DO, 2 AI or 1 RS-485, 0/12/24 V DC
Mounting Dimensions
20.4 cm
Payload Power Supply
Dedicated M8: 24/48 V DC, 3 A continuous, 5 A peak for up to 2 s
Workflow Integration
UR+ ecosystem
Workflow Integration
SCHUNK EZU gripper
Workflow Integration
Inbolt Standard 3D vision
Workflow Integration
PSYONIC Ability Hand

Commercial Status

Status
Commercial
Price
Price not disclosed
Release Date
Sep 14, 2026

Timeline

  1. Robot release
    UR17g-1300
Submit a source or correction