
Unitree Robotics logoUnitree Robotics

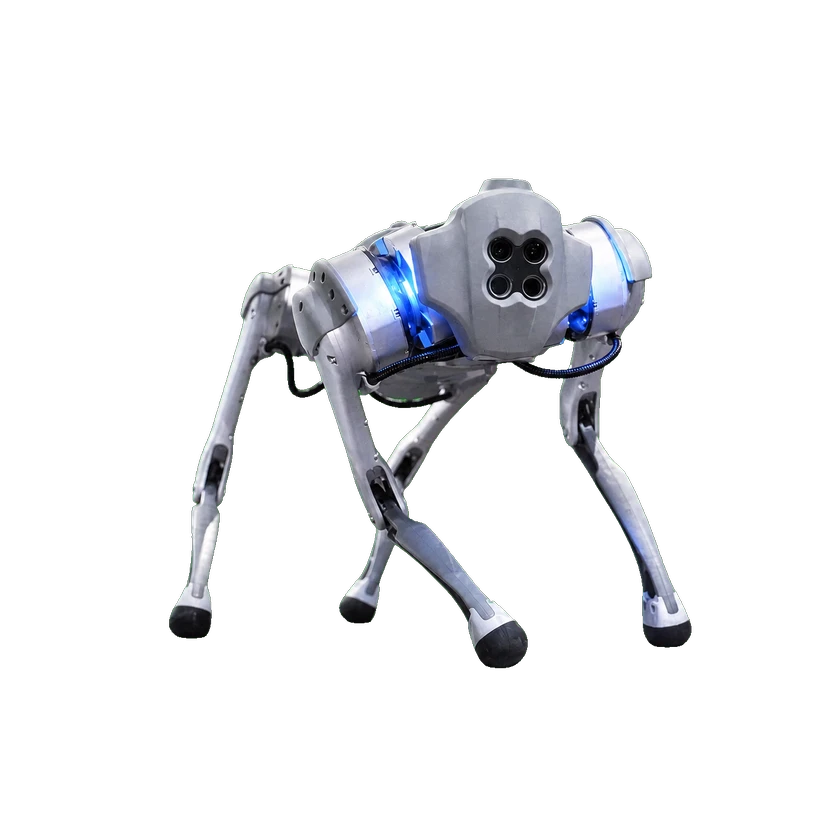
Go1 Edu

Price
Price not disclosed
Type
Quadruped Robots · Consumer Quadruped
Applications
Research & Education · Education Platform / Research & Education · Research Platform
Status
Commercial
Availability
On sale
Purchase
Not disclosed
Release Date
Jun 2021
Country/Region
China
6 kg
General Payload
3.7 m/s
Walking Speed
12 kg
Weight

Go1 Edu is the education and development version with five pairs of sensing cameras, a 6 kg adaptive load, motion speed up to 3.7 m/s, Python and scientific programming interfaces, human sensing and optional radar.

Go1 Edu

Hardware Specification

Physical Specifications

Folded Dimensions
0.588 × 0.22 × 0.29 m
Mechanical joint count
12
Locomotion Type
Bionic quadruped locomotion

Mobility & Payload

Max Speed
0–3.7 m/s
General Payload
6 kg
Walking Speed
3.7 m/s

Mechanical and mounting

Weight
12 kg

Mechanical Structure

Cooling System
Heat-pipe-assisted heat dissipation
Joint Type
Silver-alloy precision joint motor

Sensors

Camera
Fisheye binocular depth camera
Depth Camera
5 pairs
Sensor Field of View
Approximately 150 × 170°
Positioning Module
ISS Intelligent Concomitant System
Lighting (sensing)
Good ambient lighting recommended for binocular depth sensing
Sensors
SSS super-sensing system; fisheye binocular depth sensing; ultrasonic sensing

Battery and Runtime

Battery Type
Single battery pack
Charger
24V, 6A

Compute Platform

GPU
384-core GPU, 1.5 TFLOPS
Onboard Compute
16-core CPU + GPU, 384-core GPU and 1.5 TFLOPS

Interaction and Communication

Smart Following
Intelligent following via ISS wireless vector positioning
Remote Controller
Included
Video Transmission
RTT picture transmission

Development support

Go1 EduCurrent model

Conditional access

The manufacturer explicitly documents developer APIs for Go1. Use the model-specific SDK and compatible firmware. Navigation requires the separately delivered navigation stack and applicable sensor configuration.

Development configuration: Go1 SDK v3.8.6

Firmware and developer-access prerequisites apply. This SDK profile does not include the optional navigation software.

Development capabilities

Joint-level controlConditional support
Python SDKConditional support
C++ SDKConditional support
Position commandsConditional support
Velocity commandsConditional support
PD + feedforward torqueConditional support
Direct torque commandsConditional support

Only the model-specific SDK revision, compatible firmware/sport package, and authorized low-level developer access. Torque example explicitly sets Kp/Kd=0 and applies commanded torque; no claim about all motor operating ranges or purchased edition.

Documented constraints

  • Navigation interfaces are not part of this public GitHub locomotion SDK; obtain the manufacturer-delivered navigation software and matching LiDAR configuration.
Sources · 5

Open source & build resources

Software

Partially available

Examples or supporting tools are available; this does not establish access to the core system.

Hardware design

Not verified

There is not enough verified evidence to establish this dimension.

Build resources

Not verified

There is not enough verified evidence to establish this dimension.

TypeResourceLicenseApplicable versionOpen
CodeGo1 legacy SDK examples and wrappers

GitHub · unitreerobotics/unitree_legged_sdk

Repository license applies to these files. Prebuilt core, dependencies, firmware, hardware and access rights are separate; this link does not assert whole-robot open source.

BSD-3-Clauselegged_sdk_v3_8_6Open GitHub

Commercial Status

Status
Commercial
Price
Price not disclosed
Release Date
Jun 2021

Deployment records

Statuses reflect historical reports; subsequent operating conditions are unknown.

Deployment records 1 · Pilot 1 · Project actual units · Undisclosed

Partner
Carnegie Mellon University · Operator
Primary task
Integrate sensing and compute equipment with a Unitree Go1 Edu and test autonomous exploration and navigation in narrow, cluttered indoor environments for an assistive search-and-rescue research project.Locomotion testing
Location
Undisclosed
Started
2023
Last verified
2026-10-13
Evidence scope

The 2023 MRSD project identifies the exact Go1 Edu model, distinguishes real-world robot control from simulation, and reports autonomous exploration tests in narrow, cluttered environments. This is a university research field test, not a rescue operation or customer deployment. The exact test site and dates, payment, unit count, and current operation are not disclosed.

Deployment timeline · 1

  1. Autonomous indoor exploration tests with the Go1 Edu
As of the verified evidence; this is not live operating status.2026-10-13

Timeline

  1. Robot release
    Go1 Edu
Submit a source or correction