
 Ti5 Robot
T140A
T140A Flagship
Price
Price not disclosed
Type
Humanoid Robots
Status
Unknown
Availability
Not disclosed
Purchase
Contact manufacturer
Release Date
Unknown
Country/Region
China
Last Verified
2026-10-14
42 (manufacturer-reported total)
Total degrees of freedom
140 cm
Height
45 kg
Weight
1 m/s
Walking Speed
The T140A Flagship is a Ti5 Robot bipedal humanoid for education and robotics research. It is 1.4 m tall and weighs 45 kg, with a reported 3 kg payload per arm. Its equipment includes small dexterous hands, a head depth camera, two wrist depth cameras and two six-axis force sensors.
1 / 1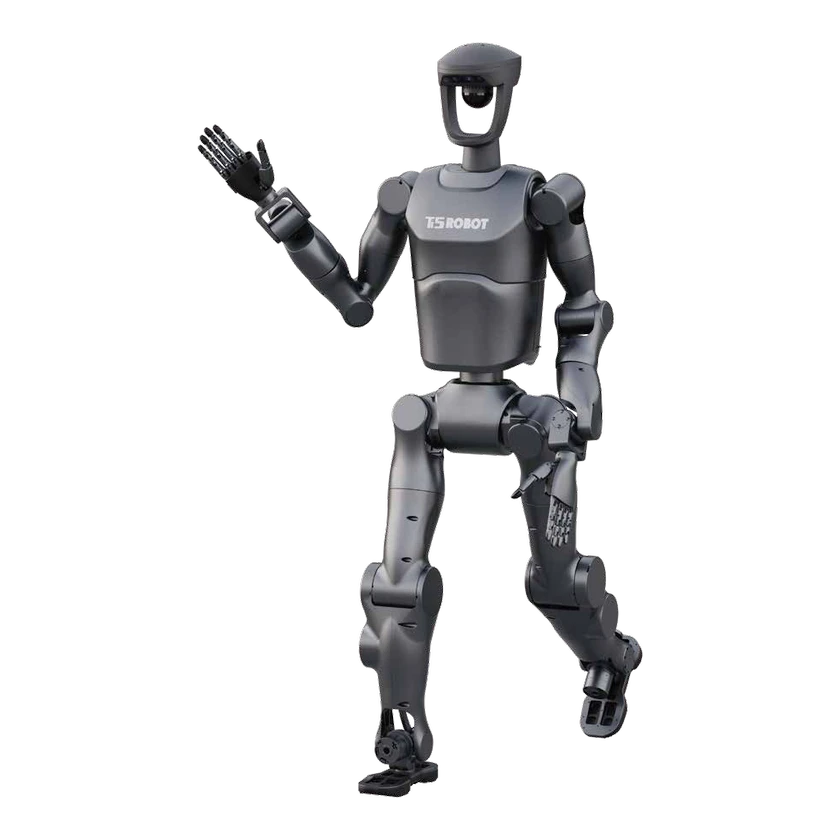
Hardware Specification
Use cases and capture workflow
Use cases
Education, training and robotics research
Physical Specifications
Actuator count
30 joint motors
Arm Span
126 cm
Frame Material
Aluminum alloy and other materials
Active degrees of freedom
6 active DOF per hand
Locomotion Type
Bipedal
Materials
Shell: ABS and other materials
Total degrees of freedom
42 (manufacturer-reported total)
Mobility & Payload
Hand Payload
3 kg
Walking Speed
1 m/s
Degrees of Freedom
Controllable DOF per Arm
7 DOF
Head DOF
1 DOF
Height
140 cm
DOF per Leg
6 DOF
Waist DOF
3 DOF
Weight
45 kg
Mechanical Structure
Dexterous Hand
High-precision dexterous hand (small)
Joint Encoder Resolution
16/18 bit
Reducer Type
Harmonic
Sensors
Depth Camera
Head: Intel RealSense D435i ×1; wrists: Intel RealSense D405 ×2
Force/Torque Sensor
Two wrist six-axis force sensors, SRI M3552D1 with M8123B2
Obstacle Avoidance
Obstacle sensing: present
Compute Platform
Onboard Compute
Jetson AGX Orin 64 GB developer kit
Repeatability
End effector: ≤0.3 mm
Software Algorithm
Standing balance, tethered walking, untethered walking
Interaction and Communication
Communication
Joints: CAN/EC; hands: 485/CAN
Development and Expansion
Secondary Development (SDK)
Body and peripheral SDKs; ROS 2 development package
Commercial Status
Status
Unknown
Price
Price not disclosed
Release Date
Unknown
Related Entities
Submit a source or correction