
 Beijing KingKong Technology Co., Ltd.
KingKong Small Robots
Tiaotiao
Price
Price not disclosed
Type
Unknown
Applications
Commercial Service · Recreation & Entertainment
Status
Prototype
Availability
Not released
Purchase
Not disclosed
Release Date
Jul 17, 2026
Country/Region
China
Last Verified
2026-08-22
Tiaotiao is a red, six-legged biomimetic crab robot publicly shown by Beijing KingKong Technology at WAIC 2026. It uses 22 self-developed miniature tactile servos and 44 high-precision encoders in a dual-encoder closed-loop architecture. Its front claws handle small items, while it supports jumping, VR first-person teleoperation, and interactive crab dancing.
1 / 1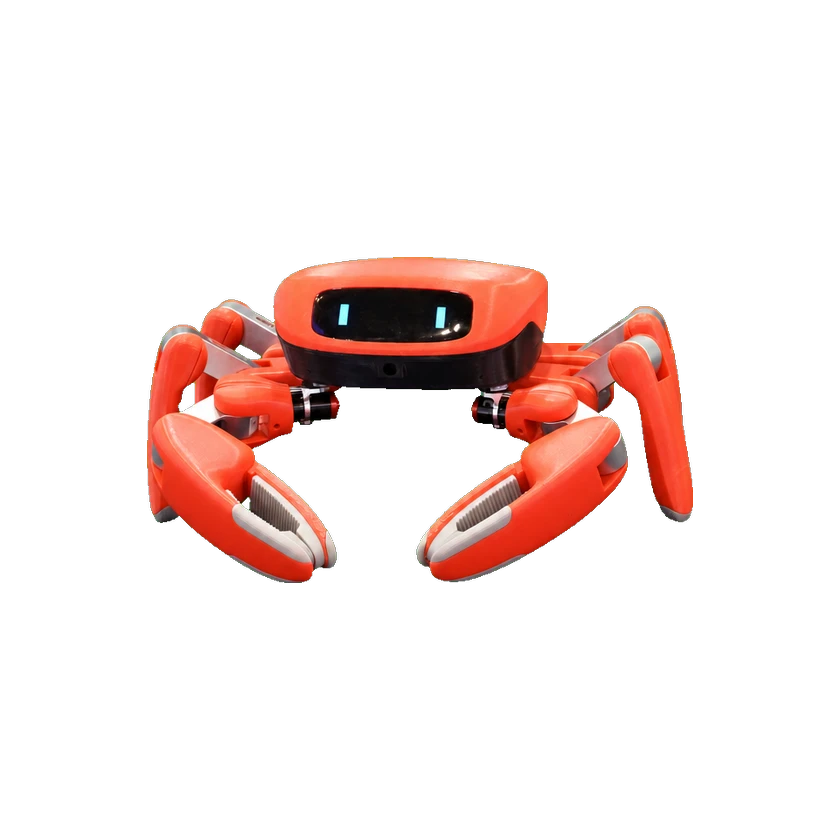
Hardware Specification
Physical Specifications
Color
Red
Mechanical joint count
22 tactile servos
Locomotion Type
Six-legged walking
Mobility & Payload
Chassis Mobility
Walking, jumping, cushioned landing, and rapid posture adjustment
Jumping Capability
Supports jumping
Mechanical Structure
Actuator Model
Self-developed high-dynamic miniature joints
Chassis
Low-profile multi-legged configuration
End-Effector
Front dual claws for grasping, pushing, and placing small items
Joint Encoder
Dual-encoder full closed-loop control architecture
Joint Sensor Type
Two high-precision patterned magnetic encoders integrated per servo
Joint Type
Self-developed miniature tactile servos
Sensors
Camera
VR control provides a first-person robot view
Force/Torque Sensor
Senses resistance during motion and provides feedback for walking, grasping, and operation
Sensors
44 high-precision encoders
Interaction and Communication
Remote Controller
VR headset and controllers
Tactile Feedback
Real-time position and force sensing through tactile servos
Development and Expansion
Dance Development
Can perform a crab dance to music
Operating Modes
Walking, jumping, grasping, VR teleoperation, and interactive performance
Teleoperation
Supports VR teleoperation of the dual claws
Commercial Status
Status
Prototype
Price
Price not disclosed
Release Date
Jul 17, 2026
Related Entities
Timeline
- Robot releaseTiaotiao
Submit a source or correction