
 DUCO Robots
BSJ11
- Output speed · Peak
- 30 rpm
- Weight
- 0.45 kg
- Outer diameter
- 65 mm
- Operating voltage · Rated
- 48 V
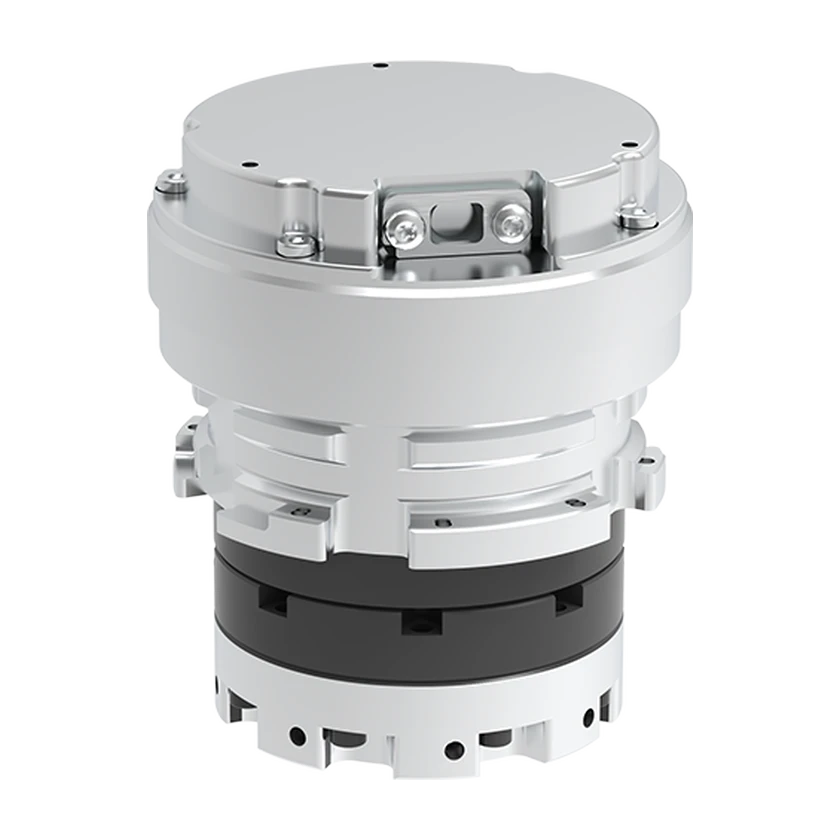
BSJ11 is a DUCO integrated joint module for humanoid robots. Its hollow design combines drive, control, transmission and sensing, with torque feedback control and full-state feedback. It weighs 0.45 kg, has a 100:1 reduction ratio, and uses a 48 V DC supply and EtherCAT communication.
Technical specifications
Output & transmission
- Output torque · Start/stop allowable
11 N·m
- Output torque · Average load
8.9 N·m
- Output torque · Maximum instantaneous
25 N·m
- Output speed · Peak
30 rpm
Dimensions & installation
- Weight
0.45 kg
- Outer diameter
65 mm
- Axial length
79.3 mm
- Hollow bore diameter
7 mm
Electrical
- Operating voltage · RatedDC power input
48 V
Encoders & feedback
- Encoder resolutionOutput-side encoder
19 bit
Communication & control
- Communication protocol
EtherCAT
Scope not bound
- Control mode
Torque closed-loop control
Scope not bound
- Control loop rate
1000 Hz
Scope not bound
Braking & environment
- IP rating
IP54
Construction & components
- Reducer integration
Integrated
Scope not bound
- Encoder integration
Integrated
Scope not bound
- Driver integration
Integrated
Scope not bound
- Controller integration
Integrated
Scope not bound
Model-level records · configuration applicability unverified
- Positioning / Application
- Humanoid robot joint
- Gear Ratio
- 100:1
- Internal Wiring
- Hollow wiring
- Joint Type
- Bionic integrated joint module
Source · 3
2026-09-16 · 2026-09-17
Weight · 0.45 · 产品参数 / bsj11
Operating voltage · 48 · 产品参数 / bsj11
Communication protocol · ethercat
Control loop rate · 控制周期 · 控制周期达到1000hz · 产品概览
IP rating · ip54 · 产品参数 / bsj11
Encoder resolution · 输出端编码器分辨率 · 19 · 产品参数
Hollow bore diameter · 7 · 产品参数 / bsj11
Outer diameter · 65 · 产品参数 / bsj11
Output speed · 30 · 产品参数 / bsj11
Output torque · 11 · 产品参数 / bsj11
Output torque · 8.9 · 产品参数 / bsj11
Output torque · 25 · 产品参数 / bsj11
Gear Ratio · 100
Joint Type · Bionic integrated joint module
2026-09-16
Control mode · torque
Controller integration · integrated
Driver integration · integrated
Encoder integration · integrated
Reducer integration · integrated
Positioning / Application · Humanoid robot joint
Internal Wiring · Hollow wiring
Compare family models
Choose 2–4 configurations
Compare selected configurations| Technical specifications | BSJ11100:1 standard configuration | BSJ17100:1 standard configuration |
|---|---|---|
| Weight | 0.45 kg | 1.35 kg |
| Operating voltage · Rated | 48 V | 48 V |
| Communication protocol | EtherCATScope not bound | EtherCATScope not bound |
| IP rating | IP54 | IP54 |
| Encoder resolution | 19 bit | 19 bit |
| Outer diameter | 65 mm | 96 mm |
| Output speed · Peak | 30 rpm | 30 rpm |
| Output torque · Start/stop allowable | 11 N·m | 66 N·m |
| Output torque · Average load | 8.9 N·m | 48.5 N·m |
| Output torque · Maximum instantaneous | 25 N·m | 107 N·m |
Commercial Status
Related Entities
No related products recorded yet.