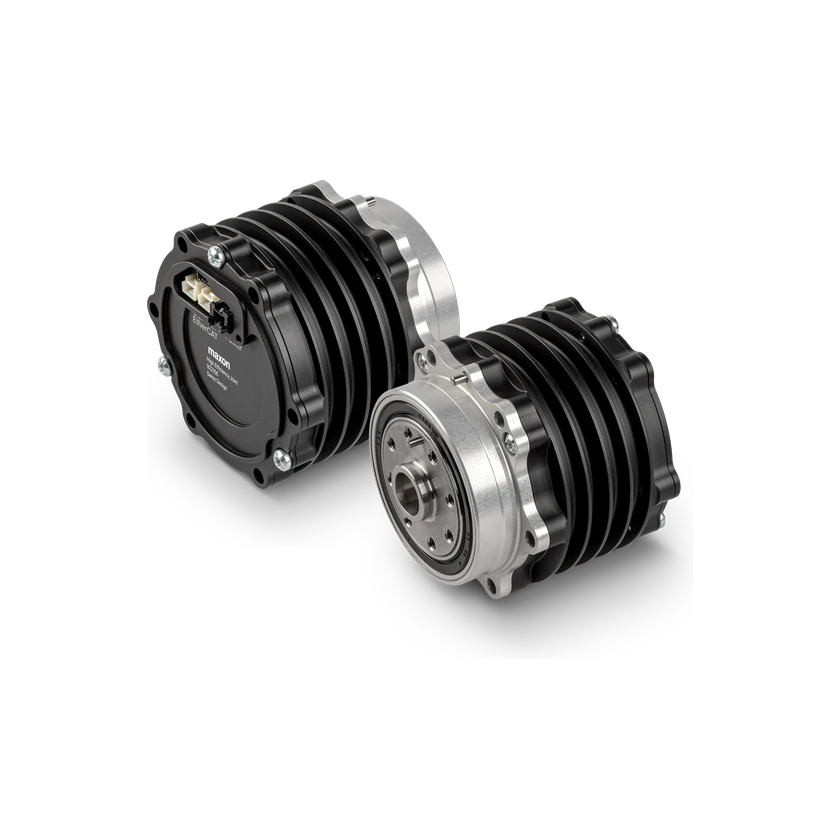
Integrated joint comparison

Compare 2–4 models or configurations. Rated, continuous and peak values use different conditions; check the sources before comparing.

2 models / configurations selected

Experiments do not imply factory configuration. Evidence applies only to the named model version.

Dimensions & installation

Rated torque density

—

37.39 N·m/kg

Based on net joint mass

dc_point · 48–48 V

Peak torque density

—

69.79 N·m/kg

Based on net joint mass

dc_point · 48–48 V

Model-level weight · configuration applicability unverified

Model-level weight · configuration applicability unverified

0.53 kg

—

Degrees of freedom and drive

Transmission mechanism

—

Planetary gearing

Mechanical and mounting

Weight

—

2.006 kg

Weightnet

0.53 kg

—

Electrical and integration

Connector typem8

—

M8

Operating voltageAllowed range

—

30–60 V

Operating voltageAllowed range

30–60 V

—

Communication and control

Communication interface

—

Ethernet

Communication interface

EtherCAT

—

Communication protocol

—

EtherCAT

Control modecurrent

Motor current (FOC)

—

Control modecurrent_foc

—

Motor current (FOC)

Control modeimpedance

Impedance

Impedance

Control modeposition

Position

Position

Control modetorque

Torque

Torque

Control modevelocity

Velocity

Velocity

Command rateMaximum

1000 Hz

1000 Hz

Control loop ratemotor_current_foc

25000 Hz

25000 Hz

Control loop rateother_control_loops

2500 Hz

—

Control loop rateother_controllers

—

2500 Hz

Software and resources

CAD availability

—

Available on request

Reliability and environment

IP rating

—

IP67

Joint specifications

Ordering code

922156 rev.01

831220

Axial lengthapproximate

about≈65 mm

—

Axial lengthapproximate

—

≈90 mm

Outer diameterapproximate

—

≈108 mm

Outer diameterapproximate

≈71.5 mm

—

Output torquePeak

28 N·m

48 V DC

—

Output torquePeak

—

140 N·m

48 V DC

Output torqueRated

11 N·m

48 V DC

—

Output torqueRated

—

75 N·m

48 V DC

Output speed± max · 48 V DC

—

99.3127 rpm

48 V DC

Output speed± max · 60 V DC

—

124.1409 rpm

60 V DC

Output speedMaximum

200.5352 rpm

48 V DC

—

Output speedMaximum

248.2817 rpm

60 V DC

—

Backdrive torqueLess than

less than<0.8 N·m

—

Backdrive torqueMaximum

—

≤1.5 N·m

Backlash

30 arcmin

—

Backlashaverage

—

30 arcmin

Output inertia

0.0056 kg·m²

0.045 kg·m²

Operating current

7.3 A

48 V DC

—

Operating current

4.7 A

—

Operating currentContinuous

—

8 A

Operating currentLess than

<40 A

—

Operating currentMaximum

—

≤40 A

Operating currentshort_duration

—

30.1 A

48 V DC

Encoder type

Absolute

—

Encoder turn mode

Single-turn

—

Encoder turn modeJoint output

—

Single-turn

Encoder resolution

14 bit

—

Torque feedback method

Compensated motor-current estimate

Compensated motor-current estimation

Protection functionsmotor_i2t

—

Configurable motor i²t protection

Protection functionsmotor_thermal_i2t

Configurable motor thermal protection (I²t)

—

Cooling methodexternal_forced_air

—

External forced air

Cooling methodforced_air

Forced-air cooling

—

Cooling methodpassive_convection

Passive convection

—

Motor integration

Integrated

Integrated

Reducer integration

Integrated

Integrated

Encoder integration

Integrated

Integrated

Driver integration

—

Integrated

Controller integration

Integrated

Integrated

Source · 3
global.maxongroup.com

High Efficiency Joints (HEJ) · HEJ 50-48-30 · 922156 rev.01

Model-level weight · configuration applicability unverified / Weight · net / Operating voltage · Allowed range / Communication interface / Control mode / Command rate · Maximum / Control loop rate / Ordering code / Axial length · approximate / Outer diameter · approximate / Output torque · Peak / Output torque · Rated / Output speed · Maximum / Backdrive torque · Less than / Backlash / Output inertia / Operating current / Operating current · Less than / Encoder type / Encoder turn mode / Encoder resolution / Torque feedback method / Protection functions / Cooling method / Motor integration / Reducer integration / Encoder integration / Controller integration

Verified · 2026-11-21

global.maxongroup.com

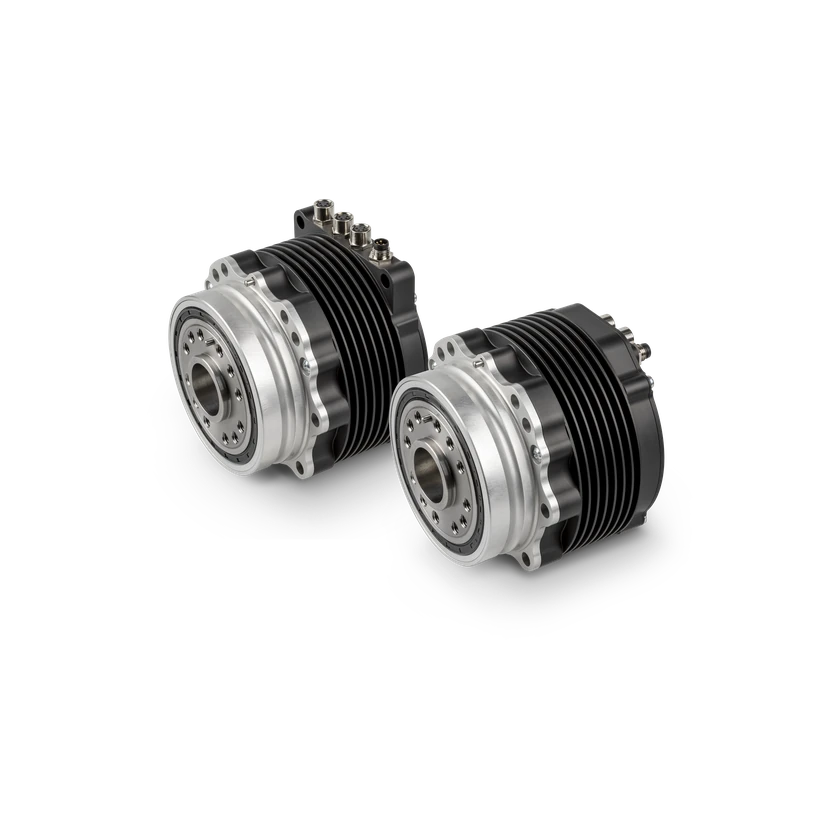
High Efficiency Joints (HEJ) · HEJ 90-48-140 · Radial connectors · 831220

Rated torque density / Peak torque density / Weight / Connector type / Operating voltage · Allowed range / Communication interface / Communication protocol / Control mode / Command rate · Maximum / Control loop rate / CAD availability / IP rating / Ordering code / Axial length · approximate / Outer diameter · approximate / Output torque · Peak / Output torque · Rated / Output speed · ± max · 48 V DC / Output speed · ± max · 60 V DC / Backdrive torque · Maximum / Backlash · average / Output inertia / Operating current · Continuous / Operating current · Maximum / Operating current · short_duration / Encoder turn mode / Torque feedback method / Protection functions / Cooling method / Motor integration / Reducer integration / Encoder integration / Driver integration / Controller integration

Verified · 2026-11-21

www.maxongroup.com

High Efficiency Joints (HEJ) · HEJ 90-48-140 · Radial connectors · 831220

Transmission mechanism

Verified · 2026-11-21
Submit a source or correction