
 Archon Robotics
Archon Whole-Body Data Collection Platform
Archon Whole-Body Data Collection Research Setup
Price
Unknown
Type
Robot Data Collection Systems
Status
Prototype
Availability
Not disclosed
Purchase
Not disclosed
Release Date
Unknown
Country/Region
China
Integrated system
Device form factor
Full-body motion
Captured data
Full body
Body coverage
Depends on configuration
Robot required during capture
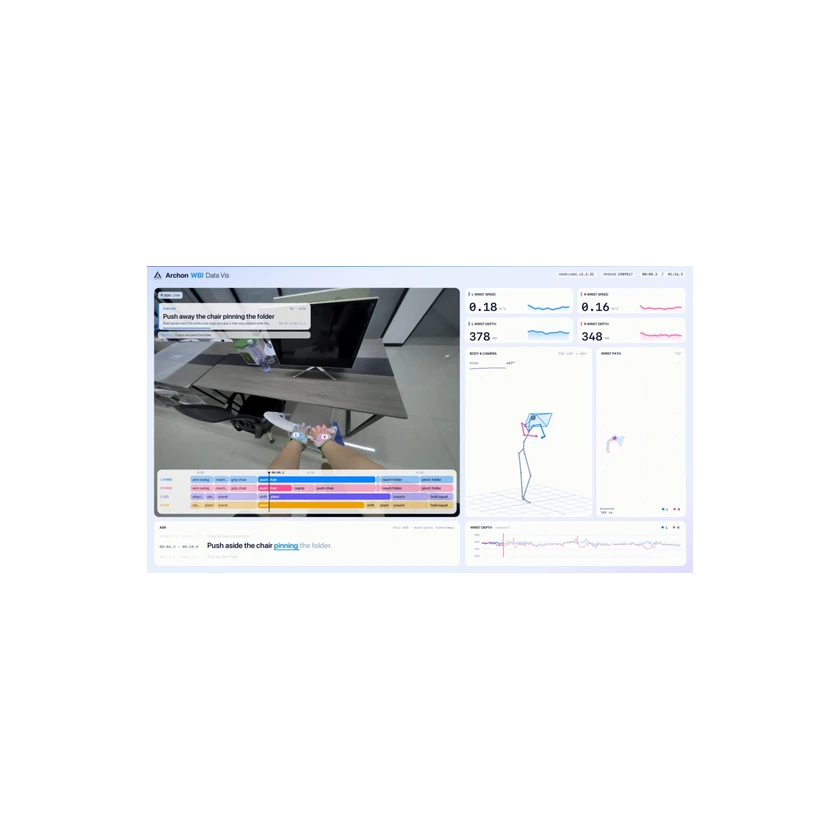
Archon Robotics uses a PICO VR headset and five trackers for whole-body motion capture. The platform aligns body motion, hand poses, stereo and depth imagery, and spatial reconstructions to one video timeline. It adds Chinese and English descriptions to action segments. The robot workflow uses Anchor 1 for beyond-line-of-sight teleoperation and records corrections and recoveries. The main image shows the official human-capture interface.
Technical specifications
Collection capabilities
Body coverage
Full body
Collection method
Human demonstration
Collection method
Motion capture
Collection method
Teleoperation
Captured data
Full-body motion
Captured data
Hand motion
Captured data
Depth
Captured data
Image
Device form factor
Integrated system
Robot required during capture
Depends on configuration
Supported robot types
Humanoid robot
Sensing and data flow
Data streams
Whole-body motion, hand poses, stereo and depth imagery, and spatial reconstruction
Sensing technology
Camera
Sensor modules
PICO VR headset and five trackers
Sensing and data flow
Synchronization
Human capture streams share the video timeline
Software and export
Annotation support
Action segments with Chinese and English descriptions
Identity and classification
Record scope
System
Use cases and capture workflow
Use cases
Pretraining humanoid models and learning recovery from correction data
Sensors, sampling and transmission
Capture modes
Wearable human demonstrations, beyond-line-of-sight robot teleoperation, and DAgger correction capture
Software, export and openness
Companion software
Anchor 1 (System-0 whole-body control model)
Data retention and sharing
Unreliable annotations and motion data are flagged at frame level
Related entities and public cases
Publicly documented uses
Anchor 1 demonstrated with PICO VR motion-tracking input
Papers and research projects
Interactive sample requires an access code from Archon Robotics
Interaction and Communication
Loop Video Recording
First-person video
Development and Expansion
Workflow Integration
Shared tagging for human and robot data, with frame-level quality flags and versioned dataset manifests
Commercial Status
Status
Prototype
Price
Unknown
Release Date
Unknown
Related Entities
No related products recorded yet.
Submit a source or correction