
Abilis — Documented tactile hardware
Sensing
Has tactile sensing
Yes
Documented Abilis hardware has 13 tactile sensors across its four fingers and palm.
 CEA-List
 dexterous robotic gripper
Abilis is a four-finger dexterous gripper developed by CEA-List within the European Tracebot project. It has 18 degrees of freedom, 14 actuators and 13 tactile sensors: three on each finger and one on the palm. According to CEA-List, the actuators measure applied force, while tactile sensors locate contacts and work with neural networks to detect slippage. An official demonstration shows one finger lifting 2 kg; this and bimanual sterile-medical-product trials illustrate its research focus on contact sensing and grasping force.
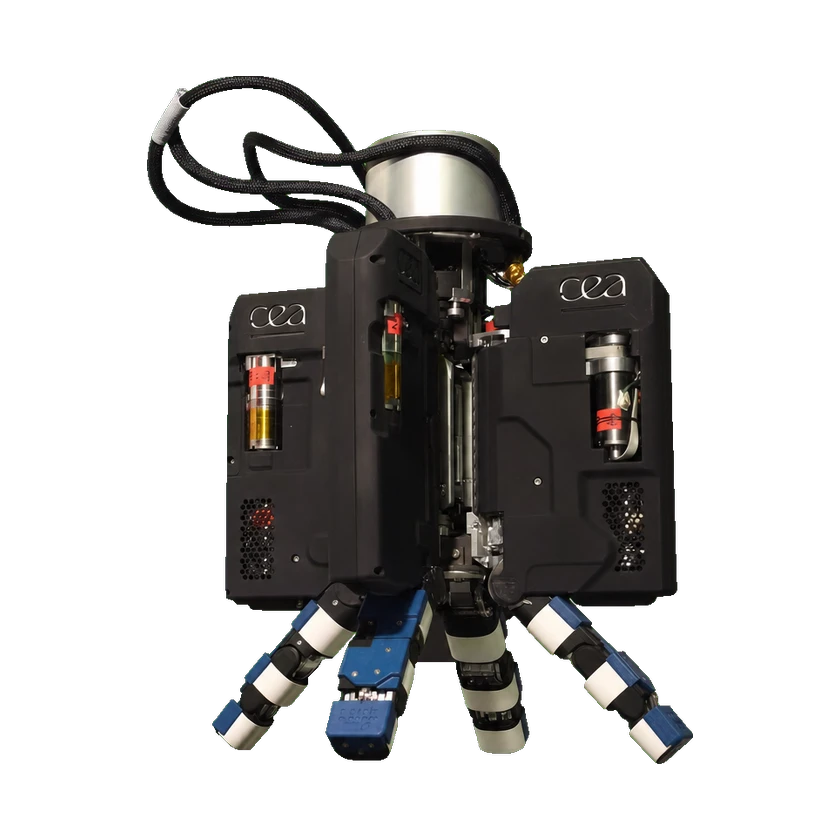
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
CEA-List research hardware: 18 total degrees of freedom, of which 14 are actuated.
CEA-List research hardware: 18 total degrees of freedom, of which 14 are actuated.
CEA-List research hardware: 18 total degrees of freedom, of which 14 are actuated.
CEA-List research hardware: 18 total degrees of freedom, of which 14 are actuated.
Documented Abilis hardware has 13 tactile sensors across its four fingers and palm.
No related products recorded yet.