Movens-Zero S

Action expert: 64.2M, 3 blocks, width 768, 12 attention heads. Movens-Zero is a humanoid motion foundation model. It uses Qwen2.5-Omni-3B and a flow-matching action expert to turn text, speech, music and video into Unitree G1 whole-body motion references. The project provides training, inference, simulation and robot deployment code.

View full model description

Papers & reports (1)

Movens-Zero: Scaling Humanoid Motion Foundation Models with Large-Scale Human Videos

Technical report

arXiv: 2610.41877
Authors & affiliations (24)

Author order: Original order

  1. Wendong BuEqual contribution

    Zhejiang University · Joint Laboratory of Embodied Intelligence, ZJU & Unitree Robotics · Bit Oasis

  2. Tinghong YeEqual contribution

    Zhejiang University

  3. Qizhou WangEqual contribution

    Unitree Robotics · Joint Laboratory of Embodied Intelligence, ZJU & Unitree Robotics

  4. Jiacheng Li

    HiThink Research

  5. Zhiqi Ge

    Zhejiang University

  6. Yuze Lin

    Zhejiang University

  7. Zhongqi Yue

    Microsoft Research

  8. Yi Su

    Unitree Robotics

  9. Jingyu Wang

    Zhejiang University

First published
Not provided
Latest paper revision
v1 · 2026-10-30
Venue
arXiv

Covered model versions

Paper ↗PDF ↗

How to access and use

Public code resources
Public access
Model files
Public access
Training data
Public access

Training / fine-tuning code

Access
Public access

SourceVerified on · 2026-11-19

Training data

Some training datasets are public; this does not establish access to the complete training mixture.

Model files

Model files
Movens-Zero S · step 29000Access
Release information

SourceVerified on · 2026-11-19

Checks before deployment

Available weights or code do not establish plug-and-play robot compatibility. Check the required configuration, data and interfaces in the source documentation.

Deployment and usage resources

Runtime and frameworks
PyTorch / Transformers

Control and inputs / outputs

Model type
Motion & whole-body control
Backbone
Qwen2.5-Omni-3B
Input
audio / Language / Robot state / Video
Output
root40_v1

Scope and training

Functional purpose

action_generation

Prediction output

Unitree G1 whole-body reference trajectories

Training data scale

5000000 sequences

Training data sources

https://huggingface.co/datasets/wendell0218/Movens-5M

Training data

  • Movens-5M

    PretrainingAvailable

    Companion dataset with five million physically executable humanoid motion sequences.

    5000000 sequences · other

Related robots

Selected checkpoint compatibility

G1 EDU ↗

Supported · Reported

Unitree G1 EDU, 29 actuated joints. Official deployment uses a GPU inference server and the GR00T whole-body controller; the real-robot server enforces a 180 ms per-chunk deadline.

Full parameters and verification notes (model card)

Action expert: 64.2M, 3 blocks, width 768, 12 attention heads.

Weight upload: 2026-10-25 19:02:13 UTC+8. Training step: 29,000.

The safetensors header contains 4,767,655,696 stored tensor elements across the backbone and action expert.

The project has not specified a code or checkpoint license. The Qwen2.5-Omni-3B backbone has its own Qwen Research License.

Paper affiliations: Zhejiang University, Unitree Robotics, Joint Laboratory of Embodied Intelligence, ZJU & Unitree Robotics, Bit Oasis, HiThink Research, Microsoft Research, East China Normal University, Peking University, National University of Singapore.

Cover: Figure 7 by Bu et al., arXiv:2610.41877, CC BY 4.0. Converted to WebP.

5e229e1e398b · 18448482152 bytes · SHA-256 aa852c32613a55ba0a49425e615d06a4b2281f3543c537300e512fe10c95c569

Qwen Research License

Deployment evidence points to the 29-DOF Unitree G1 EDU configuration. The authors provide a real-robot deployment path, with no separate on-robot validation disclosed for every checkpoint.

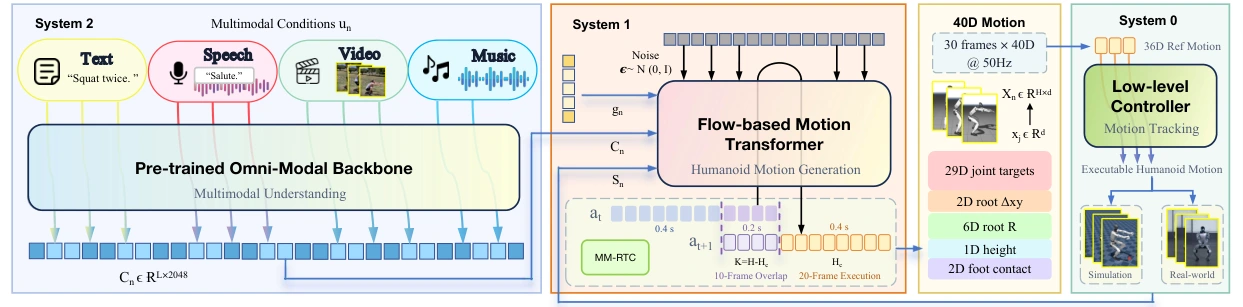
Movens-Zero architecture

Submit a source or correction