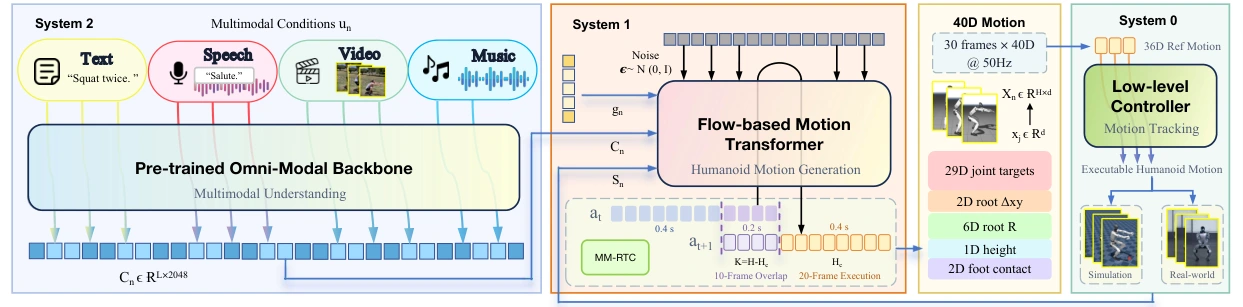
Action expert: 500.1M, 6 blocks, width 1536, 24 attention heads. Movens-Zero is a humanoid motion foundation model. It uses Qwen2.5-Omni-3B and a flow-matching action expert to turn text, speech, music and video into Unitree G1 whole-body motion references. The project provides training, inference, simulation and robot deployment code.
Available weights or code do not establish plug-and-play robot compatibility. Check the required configuration, data and interfaces in the source documentation.
Unitree G1 EDU, 29 actuated joints. Official deployment uses a GPU inference server and the GR00T whole-body controller; the real-robot server enforces a 180 ms per-chunk deadline.
Weight upload: 2026-10-25 19:05:02 UTC+8. Training step: 99,000.
The safetensors header contains 5,203,572,496 stored tensor elements across the backbone and action expert.
The project has not specified a code or checkpoint license. The Qwen2.5-Omni-3B backbone has its own Qwen Research License.
Paper affiliations: Zhejiang University, Unitree Robotics, Joint Laboratory of Embodied Intelligence, ZJU & Unitree Robotics, Bit Oasis, HiThink Research, Microsoft Research, East China Normal University, Peking University, National University of Singapore.
Cover: Figure 7 by Bu et al., arXiv:2610.41877, CC BY 4.0. Converted to WebP.
Deployment evidence points to the 29-DOF Unitree G1 EDU configuration. The authors provide a real-robot deployment path, with no separate on-robot validation disclosed for every checkpoint.