
 Purdue University
VTAP Gripper
가격
가격 비공개
유형
구성 요소 · 그리퍼
상태
Research prototype
구매 가능 여부
미공개
구매 방식
미공개
공개일
알 수 없음
국가/지역
미국
최근 확인
2026-09-15
VTAP Gripper는 퍼듀대학교와 컬럼비아대학교가 공동 연구한 세 손가락 그리퍼로, 자유도 13개와 최대 스트로크 50 mm의 선형 액추에이터로 구동하는 시각·촉각 손바닥을 갖춥니다. 손끝 촉각 어레이와 손바닥 움직임을 결합해 접촉을 조정합니다. 원 논문은 원격 조작으로 주사기 방향을 바꾸고 플런저를 누르는 실험과 시각·촉각 결합 삽입 실험을 통해 가동 손바닥과 손가락이 접촉을 재분배하는 설계를 보여 줍니다.
1 / 1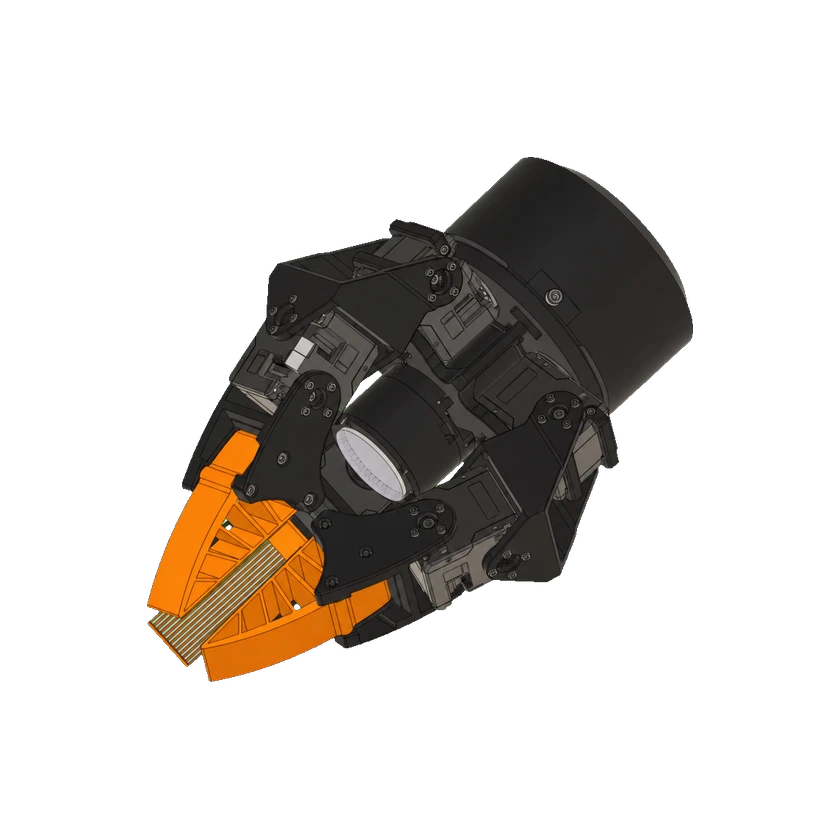
하드웨어 사양
자유도 및 구동
액추에이터 기술
Electric servo and linear actuation
능동 자유도
13 DOF
소재
TPU Fin-Ray fingers; silicone palm sensing layer; acrylic sensing substrate
총 자유도
13 DOF
동작 및 협응
협응 아키텍처
Three fully actuated four-DOF fingers coordinated with a one-DOF active palm
에너지 영역
Electrical
기계 구조
액추에이터 모델
Dynamixel 2XC430-W250-T; Dynamixel 2XL430-W250-T; Actuonix L8-P-50
관절 가동 범위
-60–60°
관절 가동 범위
-25–90°
관절 가동 범위
-55–55°
관절 가동 범위
-60–90°
관절 유형
Four revolute joints per finger and a prismatic palm axis
센서
카메라
GalaxyCore GC0307 USB camera integrated in the palm
조명(감지용)
Red, green, blue and white LED ring; LEDs off for vision and on for tactile sensing
촉각 센서
FlexiTac piezoresistive fingertip arrays and an optical tactile palm
컴퓨팅 플랫폼
소프트웨어 알고리즘
Gesture-conditioned subspace retargeting with fingertip position, orientation and temporal smoothness objectives
상호작용 및 통신
햅틱 피드백
Fingertip contact distribution and intensity support reactive grasping; palm deformation supports hole localization
시각 인식
ArUco marker pose estimation and object orientation detection
개발 및 확장
작동 모드
Teleoperation; autonomous peg-in-hole insertion
원격 조작
Meta Quest 3 hand tracking and gesture-conditioned gripper retargeting
상용화 상태
상태
Research prototype
가격
가격 비공개
공개일
알 수 없음
관련 항목
등록된 관련 제품이 없습니다.
출처 또는 수정 제안 보내기