
 Robotis
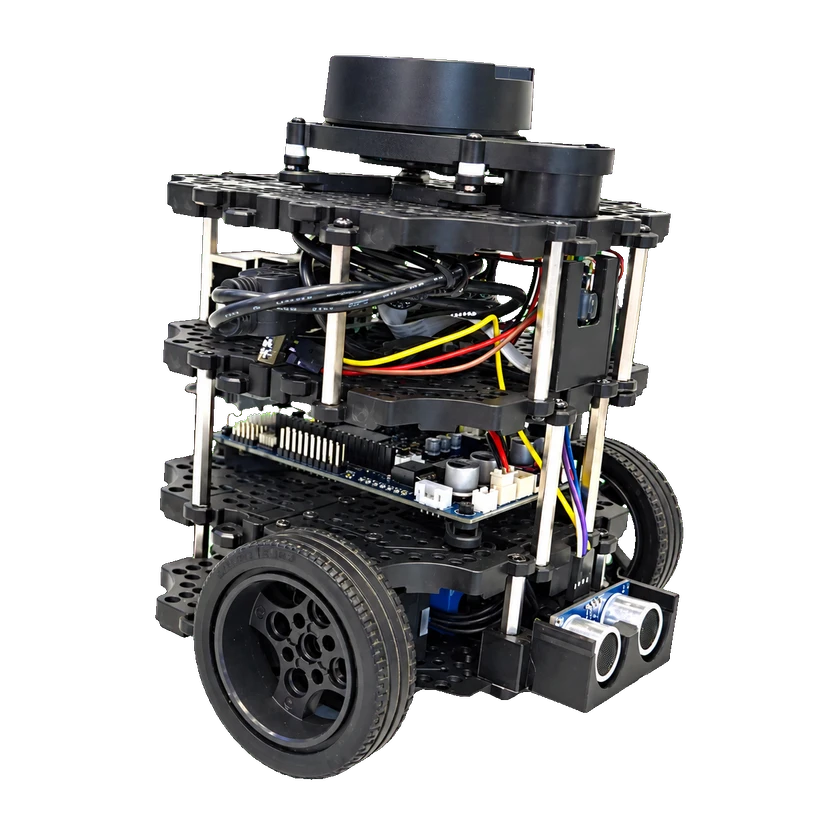
TurtleBot3 Burger
15 kg
일반 페이로드
2.5 h
작동 시간
1 kg
무게
19.2 cm
높이
TurtleBot3 이동 로봇 플랫폼의 Burger 모델입니다.
하드웨어 사양
이동성 및 적재량
최고 속도
0.22 m/s
일반 페이로드
15 kg
기계 및 장착
높이
19.2 cm
길이
13.8 cm
무게
1 kg
너비
17.8 cm
기계 구조
액추에이터 모델
2 DYNAMIXEL XL430-W250 wheel actuators
센서
LiDAR
360° LDS-02 laser distance sensor
배터리 및 작동 시간
작동 시간
2.5 h
컴퓨팅 플랫폼
온보드 컴퓨팅
Raspberry Pi 4
개발 지원
TurtleBot3 Burger현재 모델
조건부 개방TurtleBot3 Burger has model-specific bringup, keyboard teleoperation, navigation and Gazebo packages. Match Burger SBC/OpenCR firmware, sensors, model selector and the installed ROS distribution. This batch separates active Humble from legacy Noetic and the virtual Gazebo configuration. The standard reviewed Burger model is a wheeled base with zero execution arms; optional OpenMANIPULATOR/Waffle hardware is not included.
Pinned Humble simulation uses gazebo_ros with gzserver/gzclient and the complete turtlebot3_burger SDF. Set model=burger and match Humble/Gazebo Classic dependencies and simulated-time configuration. This is a virtual Burger without execution arms; optional manipulation models and camera-equipped Waffle are separate. ROS2 SLAM/teleop procedures are documented for this simulator, but no separate MuJoCo/Isaac support or automatic motion-demo recording is established.
개발 기능
시뮬레이션 개발조건부 지원
ROS 2조건부 지원
Gazebo조건부 지원
출처 · 4
- 공식raw.githubusercontent.com ↗확인일: 2026-11-06
- 공식emanual.robotis.com ↗확인일: 2026-11-06
- 공식raw.githubusercontent.com ↗확인일: 2026-11-06
- 공식raw.githubusercontent.com ↗확인일: 2026-11-06

오픈 소스 및 제작 자료
TurtleBot3 Burger 조립 설명서
적용 버전: TurtleBot3 Burger키트를 구매해 조립
소프트웨어일부 공개
예제나 보조 도구만 공개되어 있으며 핵심 시스템의 공개를 의미하지 않습니다.
제작 자료조립 안내만 제공
공식 하드웨어 설정 페이지에서 Burger 전용 조립 설명서와 영상을 확인할 수 있습니다.
관련 자료
- 열기
turtlebot3_simulations · pinned Apache2 software files
코드적용 버전: burger_humble_gazebo_classic_a35a56c8Apache-2.0
- 열기
turtlebot3 · pinned Apache2 software files
코드적용 버전: burger_ros1_noetic_4ae959eaApache-2.0
- 열기
turtlebot3 · pinned Apache2 software files
코드적용 버전: burger_ros2_humble_90a68bd2Apache-2.0
- 열기
TurtleBot3 Burger 부품 목록
하드웨어

상용화 상태
상태
상용화
가격
알 수 없음
공개일
2017년
관련 항목
등록된 관련 제품이 없습니다.
동영상
YouTube에서 보기
타임라인
- 로봇 공개TurtleBot3 Burger
출처 또는 수정 제안 보내기