
 Unitree Robotics
GO-M8010-6
- 出力回転速度 · 最大
- ≤286.4789 rpm
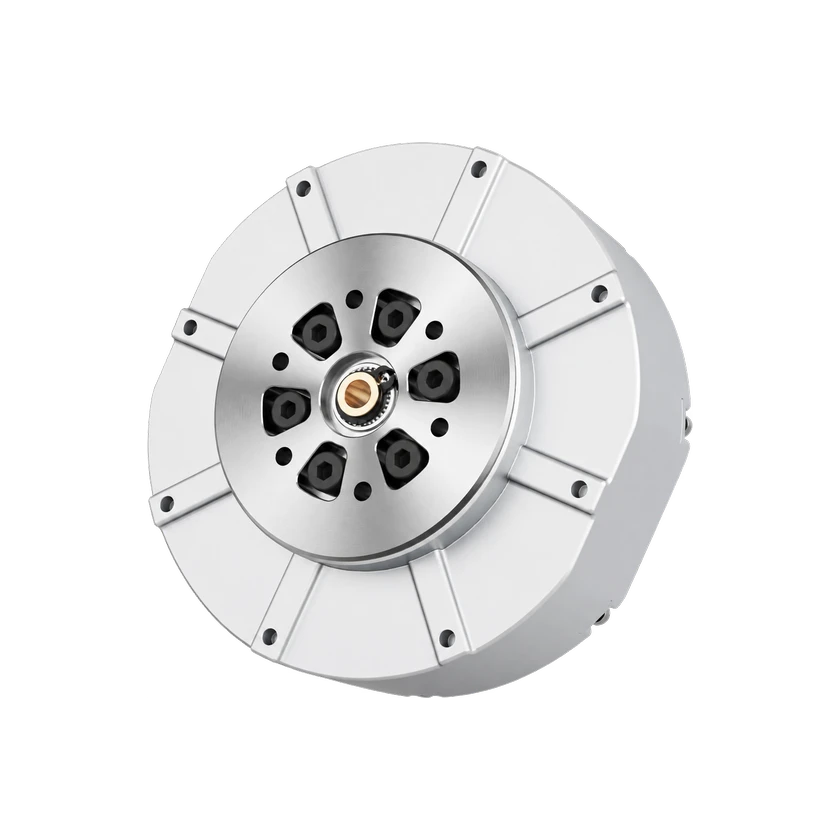
GO-M8010-6はUnitreeの一体型永久磁石同期関節モーターです。減速機、FOC制御、温度センサー、絶対値エンコーダーを備え、RS-485通信でロボット開発、競技、研究・教育に対応します。
技術仕様
出力・伝達
- 出力トルク · 最大
≤23.7 N·m
範囲未指定
- 出力回転速度 · 最大
≤286.4789 rpm
範囲未指定
24 V DC
電気仕様
- 動作電流 · 最大
≤40 A
範囲未指定
エンコーダー・フィードバック
- エンコーダー種類
絶対値エンコーダー
範囲未指定
- エンコーダー分解能
15 bit
範囲未指定
- フィードバック信号
トルク / 角度 / 角速度 / 温度
範囲未指定
通信・制御
- 通信インターフェース
RS-485
範囲未指定
- 制御モード
トルク / 位置 / 速度
範囲未指定
- コマンド周波数
6000 Hz
範囲未指定
構造・内蔵部品
- モーター種類
永久磁石同期モーター
範囲未指定
- モーター内蔵状態
内蔵
範囲未指定
- 減速機内蔵状態
内蔵
範囲未指定
- エンコーダー内蔵状態
内蔵
範囲未指定
- コントローラー内蔵状態
内蔵
範囲未指定
その他の仕様
- SDK言語
C++
範囲未指定
- SDK言語
Python
範囲未指定
モデル共通記録 · 構成への適用は未確認
- 二次開発の提供状況
- 条件付き対応
- 重量
- 0.53 kg
- 減速比
- 6.33:1
- 動作電圧
- 12–30 V
- 動作電圧
- 24 V
- ソフトウェアアルゴリズム
- ベクトル制御(FOC)
- 動作温度
- -5–40 °C
- 通信
- 4 Mbps
出典 · 3
2026-09-23
コマンド周波数 · 通信控制频率6000Hz
通信インターフェース · RS-485
制御モード · トルク
制御モード · 位置
制御モード · 速度
フィードバック信号 · トルク
フィードバック信号 · 角度
フィードバック信号 · 角速度
フィードバック信号 · 温度
エンコーダー分解能 · 15 bit
エンコーダー種類 · 絶対値エンコーダー
コントローラー内蔵状態 · 内蔵
エンコーダー内蔵状態 · 内蔵
モーター内蔵状態 · 内蔵
減速機内蔵状態 · 内蔵
モーター種類 · 永久磁石同期モーター
動作電流 · 最大相电流 · ≤40 A
出力回転速度 · 30rad/s (24V供电时)
出力トルク · 最大扭矩23.7NM;减速比6.33;24℃下测得
重量 · 约530g
減速比 · 1:6.33
動作電圧 · 12–30 V
動作電圧 · 24 V
ソフトウェアアルゴリズム · ベクトル制御(FOC)
動作温度 · -5–40 °C
通信 · 通信波特率 4Mbps
二次開発
GO-M8010-6現在のモデル
条件付きで開発可能GO-M8010-6 officialSDK/CppPython、firmware/高速RS485/ID電源整合。旧メーカー資料は販売店ホスト、旧APIは現行と別。減速機前 rotor座標。
GO-M8010-6 cpp profile at 5b79a42d. Manufacturer manual gives rotor torque = feedforward + Kp position error + Kd velocity error; Kp=Kd=0 is direct rotor Nm torque and Kp=0/Kd>0 is velocity tracking. Current GO examples select the exact motor enum and queried FOC mode; C++ uses negative and Python positive example velocity, so they are not identical motion programs. Convert output position/speed using the model gear ratio and output-side gains using ratio squared per README; header output-coordinate wording conflicts with README/manual rotor wording. Verify actual firmware/binary convention before calibrated output-side Nm use; packet fixed-point encodings differ from SDK floats. Older manual API/Go2 symbol and A1/B1 gain factors must not be copied. Prebuilt core/ABI and callback validity/error handling require matching delivery; sleep200us is not measured control frequency, send/feedback is not arrival. No SDK build or motor command was executed.
開発機能
GO型固有cpp、PD+FF は rotor Nm。gain0 の直接torque/velocity条件、gear比変換とgain比二乗が必要。header座標表記とREADME/manual相違、実firmware確認。Cpp/Python例の回転符号は逆、旧API/A1B1係数非継承、send非到達、未実行。
確認済みの制約
- GO型固有cpp、PD+FF は rotor Nm。gain0 の直接torque/velocity条件、gear比変換とgain比二乗が必要。header座標表記とREADME/manual相違、実firmware確認。Cpp/Python例の回転符号は逆、旧API/A1B1係数非継承、send非到達、未実行。
情報源 · 3
- 公式raw.githubusercontent.com ↗確認日: 2026-11-06
- 公式raw.githubusercontent.com ↗確認日: 2026-11-06
- 公式techshare.co.jp ↗確認日: 2026-11-06
オープンソースと製作資料
ソフトウェア
一部公開例や補助ツールのみ公開されています。中核システムの公開を意味しません。
ハードウェア設計
未検証この項目について十分な検証済みの根拠がありません。
製作資料
未検証この項目について十分な検証済みの根拠がありません。
| 種類 | 資料 | ライセンス | 対象バージョン | 開く |
|---|---|---|---|---|
| コード | unitree_actuator_sdk · scoped primary-code license GitHub · unitreerobotics/unitree_actuator_sdk Complete pinned BSD3 grant for the reviewed visible primary Unitree examples/headers/wrapper source. No independent claim is made for prebuilt core binaries, device firmware/hardware, manual redistribution or dependencies; match their delivery terms and ABI. No whole-motor open-source assertion. | BSD-3-Clause | go_m8010_6_cpp_5b79a42d, go_m8010_6_python_5b79a42d | 開く GitHub |
| コード | GO-M8010-6 モーター SDK・サンプル GitHub · unitreerobotics/unitree_actuator_sdk 公式 SDK は GO-M8010-6 に対応し、C++・Python のサンプルを提供します。モーター型式と回転子側・出力側の換算規則を確認してください。モーターファームウェアや製造設計は対象外です。 | BSD-3-Clause | GO-M8010-6 | 開く GitHub |
商用ステータス
関連エンティティ
関連製品はまだ登録されていません。