

MobilityOfficial claim
Walking
Unitree states that A2 can walk continuously for up to 3 hours / 12.5 km fully loaded, or 5 hours / 20 km unloaded.
Unitree A2 is an industrial quadruped for logistics, industrial inspection and emergency rescue. It weighs about 42 kg with battery and supports hot-swappable dual batteries, local air cooling and secondary development. It carries about 25 kg continuously and walks over 5 hours or about 20 km unloaded; it has one industrial LiDAR and one HD camera.
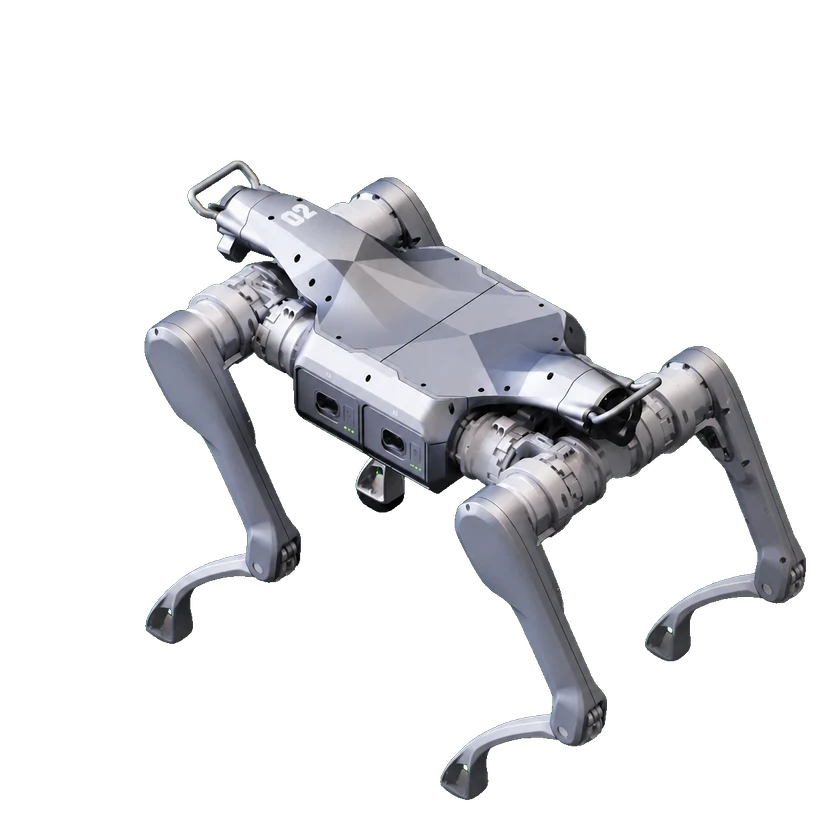
Unitree states that A2 can walk continuously for up to 3 hours / 12.5 km fully loaded, or 5 hours / 20 km unloaded.
Development configuration: A2 SDK2 sport interface
Exact documented development profile. Hardware, firmware and access conditions are recorded per capability.
Documented a2 Python sport client, with compatible firmware and developer network access. Velocity is body motion, not low-level joint velocity. No permissions transferred to another SKU.
Examples or supporting tools are available; this does not establish access to the core system.
There is not enough verified evidence to establish this dimension.
There is not enough verified evidence to establish this dimension.
| Type | Resource | License | Applicable version | Open |
|---|---|---|---|---|
| Code | Unitree SDK2 Python GitHub · unitreerobotics/unitree_sdk2_python Pinned source revision 814556d15970dd2ecf1c9984e845ca02ab07e206. License applies to this repository; hardware, firmware, dependencies and robot access have separate terms. | BSD-3-Clause | sdk2_sport | Open GitHub |
| Simulation | A2 ROS robot-description and simulation assets GitHub · unitreerobotics/unitree_ros Official ROS repository lists this robot model. These robot-description assets support visualization and simulation; they do not establish published manufacturing drawings or complete onboard software. Match the model configuration before use. | BSD-3-Clause | A2 | Open GitHub |
No related products recorded yet.
