
 SAMHYUN CO., LTD.
AXLON-IP
- Output torque · Continuous
- 4.3 N·m
- Output speed · No load
- 358 rpm
- Outer diameter
- 62 mm
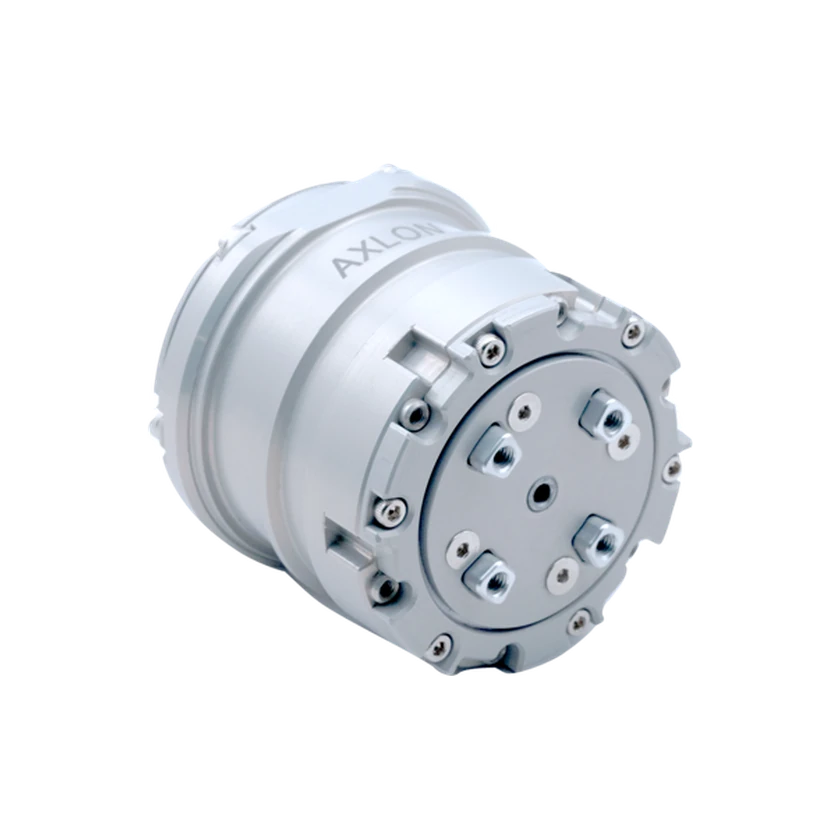
The 50x08 is a 48 V integrated robot joint from Samhyun with a brushless motor and a 15.8:1 planetary reducer. It delivers 4.3 N·m of continuous torque and reaches 358 rpm at no load. It supports CAN and CAN FD and position, velocity, torque and impedance control.
Technical specifications
Output & transmission
- Output torque · Continuous
4.3 N·m
Scope not bound
- Output torque · Maximum
13.9 N·m
Scope not bound
- Output speed · No load
358 rpm
Scope not bound
- Backlash
≤10 arcmin
Scope not bound
Dimensions & installation
- Outer diameter
62 mm
Scope not bound
- Axial length
60.6 mm
Scope not bound
Electrical
- Operating current · Continuous
3.4 A
Scope not bound
- Operating current · Maximum
10 A
Scope not bound
Encoders & feedback
- Encoder type
Dual magnetic angle sensors
Scope not bound
- Encoder resolution
15 bit
Scope not bound
- Feedback signals
Position
Scope not bound
Communication & control
- Communication interface
CAN Bus / CAN FD Bus
Scope not bound
- Communication protocol
CAN / CAN FD
Scope not bound
- Control mode
Position control / Velocity control / Torque control / Impedance control
Scope not bound
Construction & components
- Motor type
BLDC
Scope not bound
- Motor integration
Integrated
Scope not bound
- Reducer integration
Integrated
Scope not bound
- Encoder integration
Integrated
Scope not bound
- Driver integration
Integrated
Scope not bound
- Controller integration
Integrated
Scope not bound
Model-level records · configuration applicability unverified
- Weight
- 0.44 kg
- Gear Ratio
- 15.8:1
- Joint Type
- Rotary
- Operating voltage
- 48 V
- Reducer Type
- Planetary
- Processor
- ARM Cortex-M4, 170 MHz, 32 bit
- Operating temperature
- -5–55 °C
Source · 3
2026-11-23
Communication interface · Physical Connection · CAN Bus · Applied Product / IP 50x08
Communication interface · Physical Connection · CAN FD Bus · Applied Product / IP 50x08
Controller integration · AXLON I-Series / IP 50x08 · Controller · Applied Product / IP 50x08
Encoder integration · AXLON I-Series / IP 50x08 · Encoder Specification / Position Sensor · Applied Product / IP 50x08
Motor integration · AXLON I-Series / IP 50x08 · Motor · Applied Product / IP 50x08
Reducer integration · AXLON I-Series / IP 50x08 · Reducer · Applied Product / IP 50x08
Joint Type · Rotary
Reducer Type · Planetary
2026-11-23
Communication protocol · Communication · CAN · PDF p. 4 / AXLON-IP Model Specifications
Communication protocol · Communication · CAN FD · PDF p. 4 / AXLON-IP Model Specifications
Control mode · Operating Mode · Position Control Mode · PDF p. 4 / AXLON-IP Model Specifications
Control mode · Operating Mode · Velocity Control Mode · PDF p. 4 / AXLON-IP Model Specifications
Control mode · Operating Mode · Torque Control Mode · PDF p. 4 / AXLON-IP Model Specifications
Control mode · Operating Mode · Impedance Control Mode · PDF p. 4 / AXLON-IP Model Specifications
Feedback signals · Position Sensor · Dual Magnetic Angle Sensor · PDF p. 4 / AXLON-IP Model Specifications
Axial length · Dimensions D×H [mm] · 62×60.6 mm · PDF p. 4 / AXLON-IP Model Specifications
Backlash · Backlash · < 10 arcmin · PDF p. 4 / AXLON-IP Model Specifications
Encoder resolution · Encoder Specification · 15 bit · PDF p. 4 / AXLON-IP Model Specifications
Encoder type · Position Sensor · Dual Magnetic Angle Sensor · PDF p. 4 / AXLON-IP Model Specifications
Motor type · Motor · BLDC · PDF p. 4 / AXLON-IP Model Specifications
Operating current · Continuous Current [A] · 3.4 A · PDF p. 4 / AXLON-IP Model Specifications
Operating current · Maximum Current [A] · 10.0 A · PDF p. 4 / AXLON-IP Model Specifications
Outer diameter · Dimensions D×H [mm] · 62×60.6 mm · PDF p. 4 / AXLON-IP Model Specifications
Output speed · No Load Speed [rpm] · 358 rpm · PDF p. 4 / AXLON-IP Model Specifications
Output torque · Continuous Torque [N·m] · 4.3 N·m · PDF p. 4 / AXLON-IP Model Specifications
Output torque · Maximum Torque [N·m] · 13.9 N·m · PDF p. 4 / AXLON-IP Model Specifications
Weight · 440 g
Gear Ratio · 15.8:1
Operating voltage · 48 V
Processor · ARM Cortex-M4, 170 MHz, 32 bit
Operating temperature · -5 ~ +55 °C
2026-11-23
Driver integration · AXLON integrated architecture / Model Specifications · ARM Cortex-M4 기반 FOC 드라이버 · PDF p. 2 / AXLON series overview; PDF p. 4 / IP 50x08 MCU, Control Method, PWM Frequency
Compare family models
Choose 2–4 configurations
Compare selected configurations| Technical specifications | AXLON-IP 70x1022.5:1 planetary gearbox | AXLON-IP 50x08AXLON-IP 50x08 |
|---|---|---|
| Communication interface | CANScope not bound | CAN BusScope not bound |
| Communication interface | CAN FDScope not bound | — |
| Backlash | ≤10 arcminScope not bound | ≤10 arcminScope not bound |
| Outer diameter | 88 mmScope not bound | 62 mmScope not bound |
| Communication interface | — | CAN FD BusScope not bound |
| Communication protocol | — | CANScope not bound |
| Communication protocol | — | CAN FDScope not bound |
Commercial Status
Related Entities
No related products recorded yet.