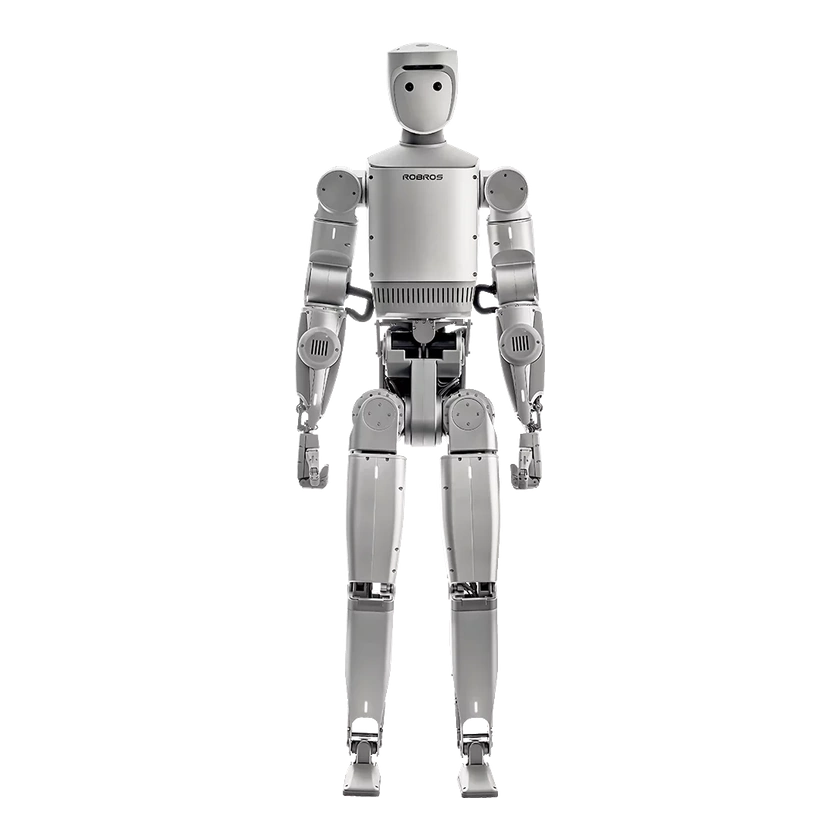
IGRIS-C2.1.1: five-finger hand API
Communication and control
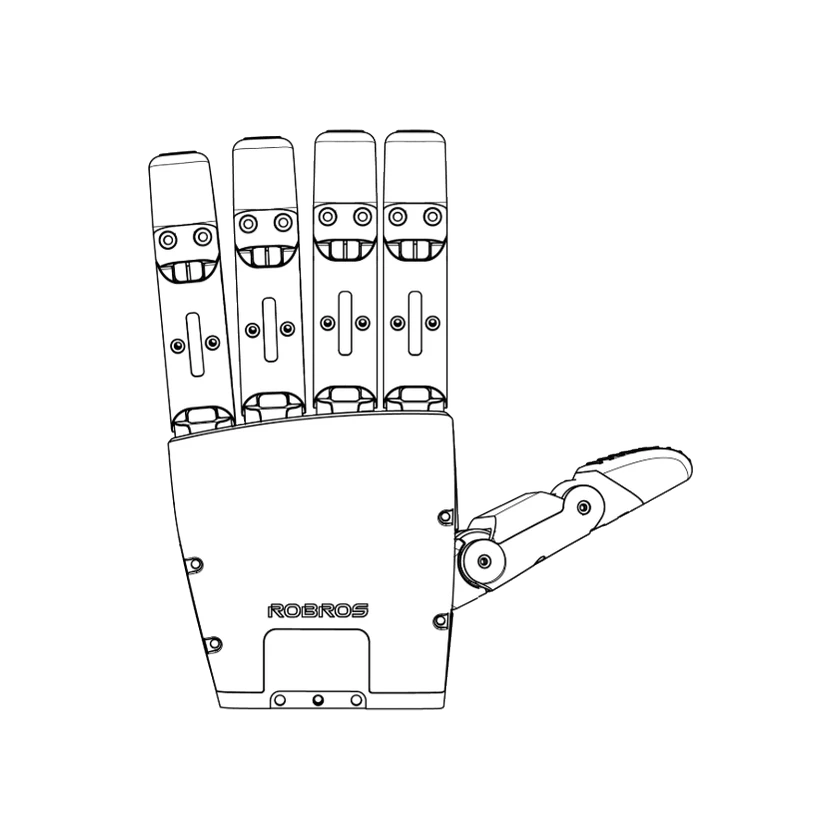
The manufacturer H5_C product section and the same IGRIS-C five-finger hand chapter agree on a2-DoF thumb plus four coupled1-DoF fingers. This scope is software2.1.1 through the robot bridge, not the1-DoF/magnet alternatives or a native physical hand bus. Transport modes are alternatives, not simultaneous interfaces. No Ethernet/CAN/RS485/USB hand connector is inferred.
The manufacturer H5_C product section and the same IGRIS-C five-finger hand chapter agree on a2-DoF thumb plus four coupled1-DoF fingers. This scope is software2.1.1 through the robot bridge, not the1-DoF/magnet alternatives or a native physical hand bus. 2.1.1 external commands take effect only in LOW_LEVEL_MODE/LOW_LEVEL_WALK_MODE. High-level presets override; other modes ignore the command. Not an angle or torque unit.
Software and resources
The manufacturer H5_C product section and the same IGRIS-C five-finger hand chapter agree on a2-DoF thumb plus four coupled1-DoF fingers. This scope is software2.1.1 through the robot bridge, not the1-DoF/magnet alternatives or a native physical hand bus. A real ROS2 service exists in ros mode; DDS ros-compatible request/response topics are not automatically ROS2 services. No distro/native standalone-hand ROS node is asserted.
The manufacturer H5_C product section and the same IGRIS-C five-finger hand chapter agree on a2-DoF thumb plus four coupled1-DoF fingers. This scope is software2.1.1 through the robot bridge, not the1-DoF/magnet alternatives or a native physical hand bus. Documented examples, not built or run in this review. SDK and robot software versions must match.
The manufacturer H5_C product section and the same IGRIS-C five-finger hand chapter agree on a2-DoF thumb plus four coupled1-DoF fingers. This scope is software2.1.1 through the robot bridge, not the1-DoF/magnet alternatives or a native physical hand bus. Documented examples, not built or run in this review. SDK and robot software versions must match.
Sensing
The manufacturer H5_C product section and the same IGRIS-C five-finger hand chapter agree on a2-DoF thumb plus four coupled1-DoF fingers. This scope is software2.1.1 through the robot bridge, not the1-DoF/magnet alternatives or a native physical hand bus. tau_est is motor current in mA despite its name/message torque annotation. It is not measured torque or tactile sensing. No handIMU support is added; bridge publication cadence is not the native sensor/control rate.