Matrix Robotics logoMatrix Robotics

Matrix-3

Third generation

Price
Unknown
Type
Humanoid Robots · Human-scale Humanoid
Applications
Household · Domestic Assistance / Industrial · Manufacturing / Healthcare & Elderly Care · Medical Assistance
Status
Prototype
Availability
Pilot only
Purchase
Not disclosed
Release Date
Jan 10, 2026
Country/Region
China
Last Verified
2026-07-26
How classification and status work

Category describes physical structure and function; wheels alone do not determine whether a robot is humanoid. Product stage describes demonstrated maturity. Commercial availability describes current access: a commercial product may still be limited to pilot customers. Neither stage nor availability alone proves that a product can be purchased. Unknown facts remain unknown.

1.7 m
Height
30 kg
General Payload
1.08 m/s
Walking Speed

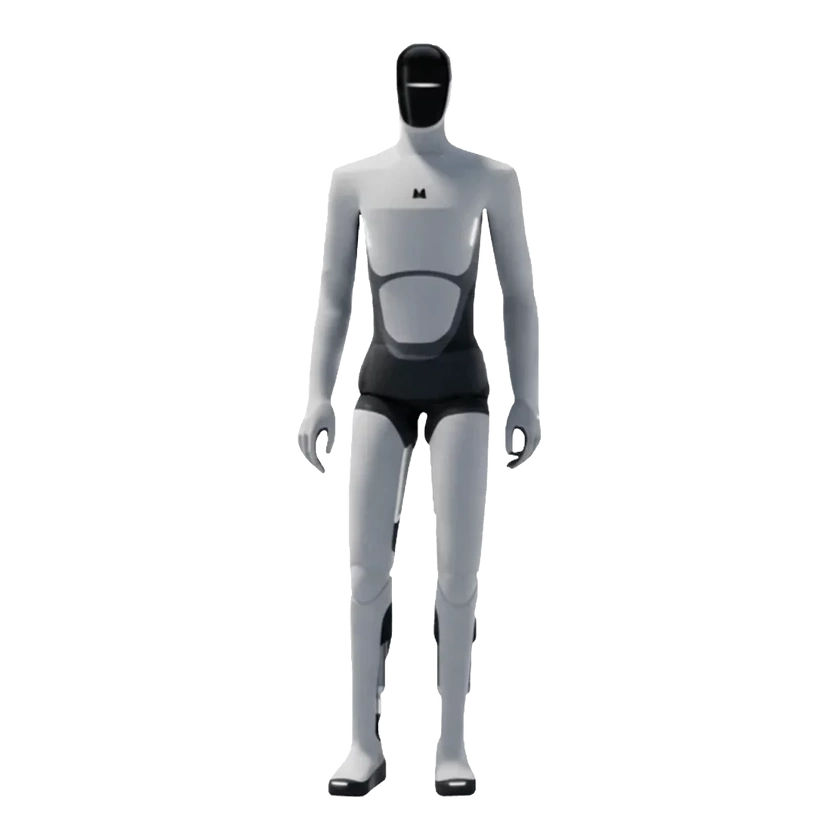
MATRIX-3 is Matrix Robotics’ third-generation humanoid platform, combining biomimetic skin, tactile perception, a 27-DoF dexterous hand, natural gait, and a proprietary neural architecture for safe autonomous work across industry and daily environments.

1 / 1Matrix-3

Capability Map

MobilityOfficial claim
Walking

Matrix Robotics states that MATRIX-3 has a natural humanoid gait built on a general motion-control model.
MobilityOfficial claim
Navigation

Matrix Robotics states that MATRIX-3 independently plans obstacle-avoidance paths.

ManipulationOfficial claim
Grasping

Matrix Robotics states that MATRIX-3 independently plans grasping strategies and adjusts force and posture in real time.

ManipulationOfficial claim
Tool use

Matrix Robotics states that MATRIX-3's dexterous hand can use standard tools and operate delicate instruments.

AutonomyOfficial claim
Autonomous operation

Matrix Robotics describes MATRIX-3 as an autonomous physical-intelligence platform capable of complex human-like tasks.

Hardware Specification

Degrees of freedom and drive

Active degrees of freedom
27 DOF
Locomotion Type
Natural humanoid gait
Materials
3D woven flexible fabric
Surface Fabric
3D woven biomimetic skin

Mobility & Payload

End-effector Linear Speed
High-speed precision manipulation
General Payload
30 kg
Terrain Types
Unfamiliar and complex environments
Walking Speed
1.08 m/s

Mechanical and mounting

Height
1.7 m

Mechanical Structure

Actuator Model
Integrated linear actuators
Dexterous Hand
27-DoF dexterous hand
Dexterous Hand Model
Intuitive Hand
End-Effector
High-fidelity end-effectors
Internal Wiring
Cable-driven hand system
Joint Type
Biomimetic joints

Sensors

Force/Torque Sensor
Fingertip pressure sensing down to 0.1 N
Sensors
Multimodal perception fusion
Tactile Sensor
High-sensitivity tactile sensor array
Vision Sensor
Large-scale spatial perception foundation model

Compute Platform

AI Model
Proprietary neural network architecture
LLM
Natural-language task instructions with zero-shot generalization
Software Algorithm
General motion control model

Safety and Protection

Human-Robot Safety
Safe autonomous physical intelligence platform

Interaction and Communication

Smart Navigation
Real-time obstacle avoidance path planning
Voice Interaction
Natural-language instruction following

Commercial Status

Status
Prototype
Price
Unknown
Release Date
Jan 10, 2026

Deployment records

Progress, changes and sources from real-world projects.

Partner
大连国际会议中心 · Venue
Scenario
Hospitality
Primary task
At the conference coffee counter, take a guest order, operate the coffee machine, prepare the drink, and hand it to the guest.
Location
First-floor catering area, Dalian International Conference Center, Dalian, Liaoning, China
Started
Undisclosed
Last verified
2026-10-13

Deployment timeline · 1

  1. MATRIX-3 serves coffee to a guest at Summer Davos
As of the verified evidence; this is not live operating status.2026-10-13

Video

Timeline

  1. Robot release
    Matrix-3
Submit a source or correction