
 Suzhou Honpine Precision Industry Co., Ltd.
TCHL Harmonic Joint Modules
- Output torque · Rated
- 3.6 N·m
- Weight
- 0.37 kg
- Outer diameter
- 52 mm
- Operating voltage
- 48 V
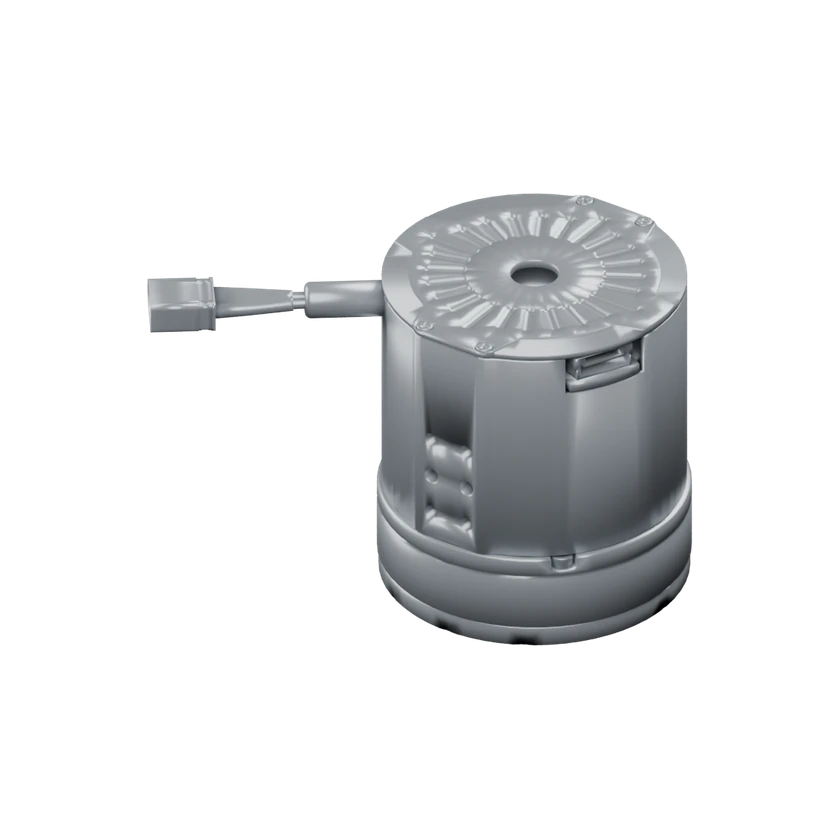
Honpine's TCHL modules combine a strain-wave reducer, frameless torque motor, drive and dual absolute encoders in one housing. The series offers multiple sizes and ratios for compact robot joints. Some sizes can be ordered with a brake or an output torque sensor. CAN FD and EtherCAT variants are available.
Technical specifications
Output & transmission
- Output torque · Rated
3.6 N·m
48 V DC
- Output torque · Peak
25 N·m
48 V DC
- Output speed · Rated
30 rpm
- Output speed · Maximum
40 rpm
- Output inertia
0.048 kg·m²
Scope not bound
Dimensions & installation
- Weight
0.37 kg
- Rated torque density
9.73 N·m/kg
Based on net joint mass
dc_point · 48–48 V
- Peak torque density
67.57 N·m/kg
Based on net joint mass
dc_point · 48–48 V
- Outer diameter
52 mm
Scope not bound
- Axial length
57 mm
Scope not bound
- Hollow bore diameter
8 mm
Scope not bound
- Tilting moment
25 N·m
Scope not bound
Electrical
- Operating voltageDC power input
48 V
Communication & control
- Communication interface
CAN / Ethernet
- Communication protocol
EtherCAT / CAN FD
Scope not bound
Model-level records · configuration applicability unverified
- Gear Ratio
- 100:1
- Gear Ratio
- 81:1
- Gear Ratio
- 51:1
- Gear Ratio
- 101:1
- IP rating
- IP54
Source · 2
2026-11-22
Weight · 0.37 kg
Operating voltage · 48 V
Communication interface · CAN
Communication interface · Ethernet
Communication protocol · EtherCAT
Communication protocol · CAN FD
Axial length · 57 mm
Hollow bore diameter · 8 mm
Outer diameter · 52 mm
Output inertia · 0.048 kg·m²
Output speed · 30 rpm
Output speed · 40 rpm
Output torque · 3.6 N·m
Output torque · 25 N·m
Tilting moment · 25 N·m
Rated torque density · 3.6 N·m
Rated torque density · 0.37 kg
Peak torque density · 25 N·m
Peak torque density · 0.37 kg
Gear Ratio · 100:1
2026-11-22
Weight · 0.37 kg
Operating voltage · 48 V
Communication interface · CAN
Communication interface · Ethernet
Communication protocol · CAN FD
Communication protocol · EtherCAT
Axial length · 57 mm
Encoder resolution · 17 bit
Hollow bore diameter · 8 mm
Driver integration · Integrated
Encoder integration · Integrated
Motor integration · Integrated
Reducer integration · Integrated
Outer diameter · 52 mm
Output inertia · 0.012 kg·m²
Output speed · 80 rpm
Output speed · 60 rpm
Output torque · 3.6 N·m
Output torque · 12.5 N·m
Tilting moment · 25 N·m
Rated torque density · 3.6 N·m
Rated torque density · 0.37 kg
Peak torque density · 12.5 N·m
Peak torque density · 0.37 kg
Output inertia · 0.03 kg·m²
Output speed · 50 rpm
Output speed · 37.5 rpm
Output torque · 5.1 N·m
Output torque · 20 N·m
Rated torque density · 5.1 N·m
Peak torque density · 20 N·m
Output inertia · 0.048 kg·m²
Output speed · 40 rpm
Output speed · 30 rpm
Output torque · 5.3 N·m
Output torque · 25 N·m
Rated torque density · 5.3 N·m
Peak torque density · 25 N·m
Gear Ratio · 81:1
Gear Ratio · 51:1
Gear Ratio · 101:1
IP rating · IP54
Compare family models
Choose 2–4 configurations
Compare selected configurations| Technical specifications | TCHL-11100:1 | TCHL-1151:1 |
|---|---|---|
| Weight | 0.37 kg | 0.37 kg |
| Operating voltage | 48 V | 48 V |
| Communication interface | CAN | CAN |
| Communication interface | Ethernet | — |
| Communication protocol | EtherCATScope not bound | CAN FDScope not bound |
| Communication protocol | CAN FDScope not bound | — |
| Outer diameter | 52 mmScope not bound | 52 mmScope not bound |
| Output speed · Rated | 30 rpm | 60 rpm |
| Output speed · Maximum | 40 rpm | 80 rpm |
| Output torque · Rated | 3.6 N·m 48 V DC | 3.6 N·m 48 V DC |
| Output torque · Peak | 25 N·m 48 V DC | 12.5 N·m 48 V DC |
| Rated torque density | 9.73 N·m/kg Based on net joint mass dc_point · 48–48 V | 9.73 N·m/kg Based on net joint mass dc_point · 48–48 V |
| Peak torque density | 67.57 N·m/kg Based on net joint mass dc_point · 48–48 V | 33.78 N·m/kg Based on net joint mass dc_point · 48–48 V |
| Communication interface | — | Ethernet |
| Communication protocol | — | EtherCATScope not bound |
Commercial Status
Related Entities
No related products recorded yet.