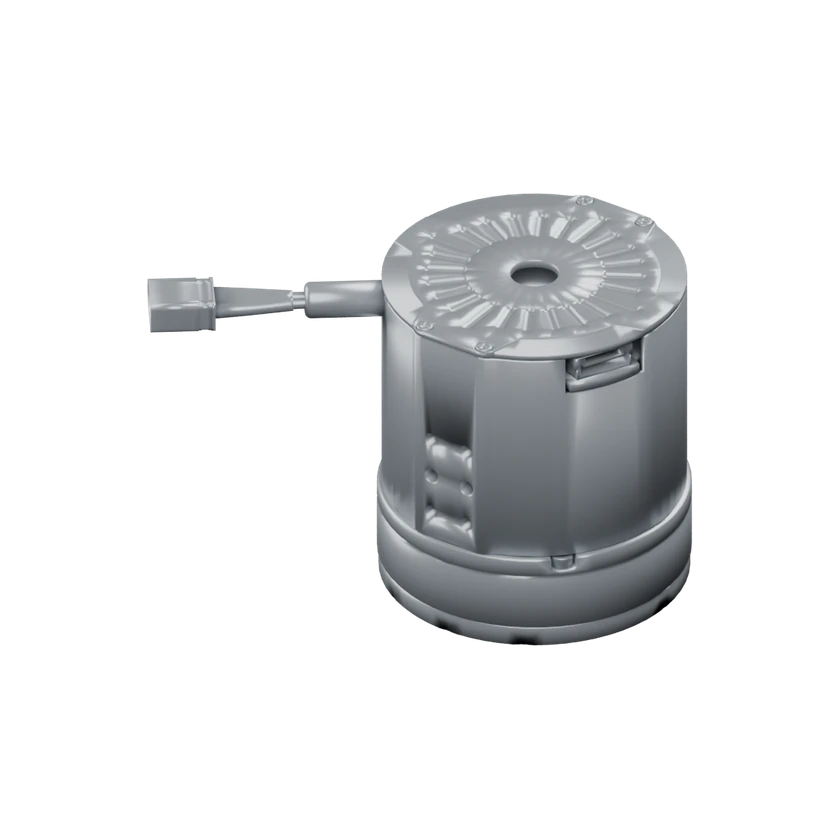
Integrated joint comparison

Compare 2–4 models or configurations. Rated, continuous and peak values use different conditions; check the sources before comparing.

2 models / configurations selected

Experiments do not imply factory configuration. Evidence applies only to the named model version.

Dimensions & installation

Rated torque density

9.73 N·m/kg

Based on net joint mass

dc_point · 48–48 V

9.73 N·m/kg

Based on net joint mass

dc_point · 48–48 V

Peak torque density

67.57 N·m/kg

Based on net joint mass

dc_point · 48–48 V

33.78 N·m/kg

Based on net joint mass

dc_point · 48–48 V

Mechanical and mounting

Weight

0.37 kg

0.37 kg

Electrical and integration

Operating voltagenominal

48 V

48 V

Communication and control

Communication interface

—

CAN

Communication interface

—

Ethernet

Communication interface

CAN

—

Communication interface

Ethernet

—

Communication protocol

—

CAN FD

Communication protocol

—

EtherCAT

Communication protocol

EtherCAT

—

Communication protocol

CAN FD

—

Joint specifications

Axial lengthwithout_brake

57 mm

57 mm

Outer diameter

52 mm

52 mm

Hollow bore diameter

8 mm

8 mm

Output torquePeak

25 N·m

48 V DC

12.5 N·m

48 V DC

Output torqueRated

3.6 N·m

48 V DC

3.6 N·m

48 V DC

Output speedMaximum

40 rpm

80 rpm

Output speedRated

30 rpm

60 rpm

Tilting moment

25 N·m

25 N·m

Output inertia

0.048 kg·m²

0.012 kg·m²

Motor integration

—

Integrated

Reducer integration

—

Integrated

Encoder integration

—

Integrated

Driver integration

—

Integrated

Source · 2
www.honpine.com

TCHL Harmonic Joint Modules · TCHL-11 · 100:1

Rated torque density / Peak torque density / Weight / Operating voltage · nominal / Communication interface / Communication protocol / Axial length / Outer diameter / Hollow bore diameter / Output torque · Peak / Output torque · Rated / Output speed · Maximum / Output speed · Rated / Tilting moment / Output inertia

Verified · 2026-11-22

hkimg.bjyyb.net

TCHL Harmonic Joint Modules · TCHL-11 · 51:1

Rated torque density / Peak torque density / Weight / Operating voltage · nominal / Communication interface / Communication protocol / Axial length / Outer diameter / Hollow bore diameter / Output torque · Peak / Output torque · Rated / Output speed · Maximum / Output speed · Rated / Tilting moment / Output inertia / Motor integration / Reducer integration / Encoder integration / Driver integration

Verified · 2026-11-22

Submit a source or correction