
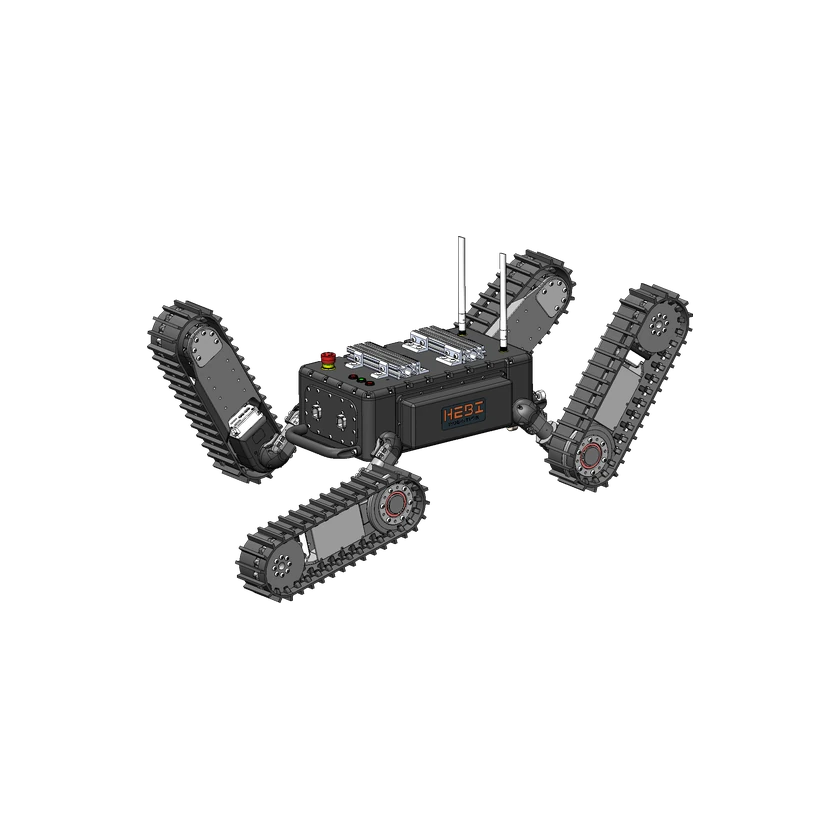
RobotStandard
Tready
Relationship notesStandard track drive. Four R8-9+ actuators drive the tracks. The chassis is specified at 15 m/min and 25 kg payload in this configuration.
Quantity × 4
 HEBI Robotics
The HEBI R8-9+ is a series-elastic joint actuator with a brushless motor, reduction gearing, spring, encoders and integrated control electronics. It supports position, velocity and torque control. Continuous torque is 10 N·m, peak torque is 23 N·m, and top speed is 39 rpm. One Tready track-drive configuration uses four R8-9+ actuators.
10 N·m
23 N·m
39 rpm
-15–15 arcmin
Scope not bound
70–700 N·m/rad
Scope not bound
0.685 kg
15 mm
Scope not bound
24–48 V
1 A
36 V DC
2.5 A
36 V DC
Multi-turn absolute
Scope not bound
Calibrated spring deflection
Scope not bound
Ethernet
Position / Velocity / Torque
Scope not bound
IP67
Scope not bound
A-2200-08-09P
Scope not bound
Brushless motor
Scope not bound
Integrated
Scope not bound
Integrated
Scope not bound
Integrated
Scope not bound
Integrated
Scope not bound
Integrated
Scope not bound
ROS
Scope not bound
ROS 2
Scope not bound
Python
Scope not bound
C
Scope not bound
C++
Scope not bound
MATLAB
Scope not bound
2026-11-19
Weight · 0.685 kg
Operating voltage · 24–48 V
Communication interface · Ethernet
ROS compatibility · ROS
ROS compatibility · ROS 2
SDK languages · Python
SDK languages · C
SDK languages · C++
SDK languages · MATLAB
Backlash · +/- 0.25°
Encoder turn mode · Multi-turn absolute
Hollow bore diameter · 15 mm
Controller integration · Integrated
Driver integration · Integrated
Encoder integration · Integrated
Motor integration · Integrated
Reducer integration · Integrated
Motor type · Brushless motor
Operating current · 1.0 A @ 36V
Operating current · 2.5 A @ 36V
Output speed · Max Speed: 39 RPM
Output torque · Cont. Torque: 10 N·m
Output torque · Peak Torque: 23 N·m
Transmission mechanism · Gear reduction
Peak Joint Output Torque · 23 N·m
Depth · 5.1 cm
Dimension reference frame · With connector cover
Length · 15.6 cm
Width · 7.8 cm
Internal Wiring · Hollow bore for daisy-chained wiring
Joint Encoder · Multi-turn absolute position (±4 turns)
Joint Encoder Resolution · 0.005° resolution, ±0.2° accuracy
Max RPM · 39 rpm
Force/Torque Sensor · Output torque, 0.01 N·m resolution
IMU · 3-axis accelerometer and gyroscope
Sensors · Angular position and velocity, output torque, IMU, temperature, voltage, current and internal pressure
Operating temperature · -10–50 °C
Communication · 2 × 100 Mbps plastic optical fiber (OptoLock)
Package Contents · A-2456-02 R/T-Series Standard Wiring Kit when purchased individually
Secondary Development (SDK) · Python, C/C++, ROS / ROS 2, MATLAB
2026-11-19
Control mode · Position
Control mode · Velocity
Control mode · Torque
Torque feedback method · Calibrated spring deflection
Torsional stiffness · Min: ~70 Nm / rad; Max: ~700 Nm / rad
Gear Ratio · 762.222:1
2026-11-19
IP rating · IP67
Ordering code · A-2200-08-09P
Ingress Protection (IP) · IP67 (straight or right-angle cover fully installed)
Choose 2–4 configurations
Compare selected configurations| Technical specifications | R8-9+Straight connector cover | R8-9+Right-angle connector cover |
|---|---|---|
| Weight | 0.685 kg | 0.685 kg |
| Operating voltage · Allowed range | 24–48 V | 24–48 V |
| Communication interface | Ethernet | Ethernet |
| IP rating | IP67Scope not bound | IP67Scope not bound |
| Backlash | -15–15 arcminScope not bound | -15–15 arcminScope not bound |
| Operating current · Continuous | 1 A 36 V DC | 1 A 36 V DC |
| Operating current · Peak | 2.5 A 36 V DC | 2.5 A 36 V DC |
| Output speed · Maximum | 39 rpm | 39 rpm |
| Output torque · Continuous | 10 N·m | 10 N·m |
| Output torque · Peak | 23 N·m | 23 N·m |
R25-8 is explicitly listed in the official series datasheet with C/C++ and Python API support. Use compatible module firmware, matching API distribution, Ethernet discovery, exact family/name, calibrated actuator limits and model-specific gains. The reviewed native profile uses strategy 4. Use the exact actuator gains and output effort feedback; do not transfer gains between gear ratios.