Columbia University logoColumbia University

FlexiTac-V2

Price
Unknown
Type
Components · Tactile sensors
Status
Prototype
Availability
Not disclosed
Purchase
Not disclosed
Release Date
Mar 2026
Country/Region
United States
Physical taxels
384

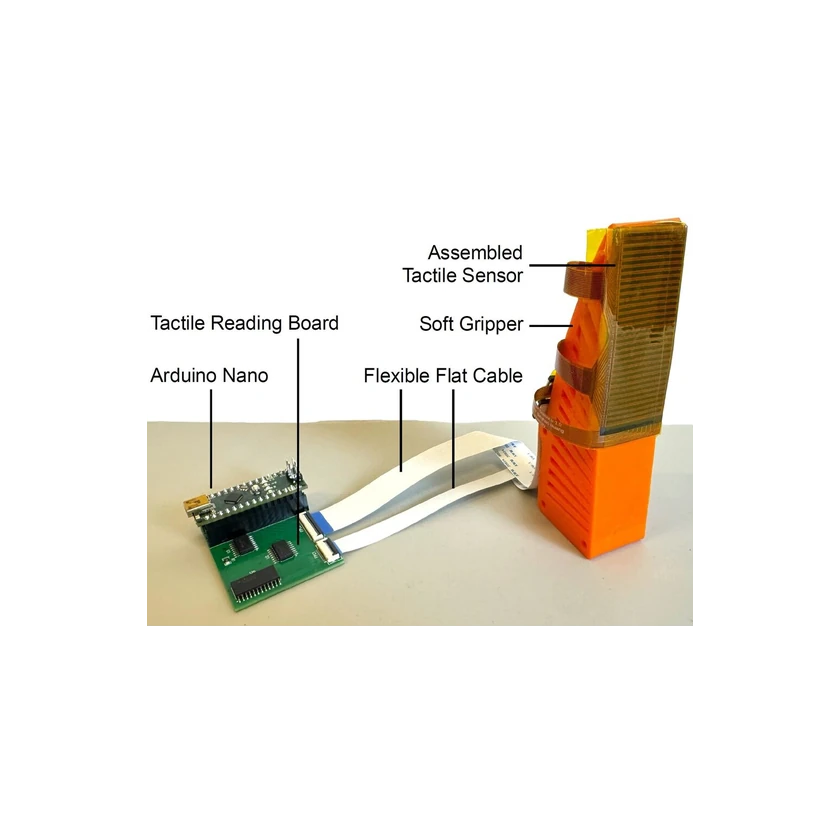
FlexiTac-V2 is a flexible piezoresistive tactile array developed by Binghao Huang and Yunzhu Li at Columbia University. Its standard fingertip pad records contact pressure patterns with 384 taxels on a 2 mm grid. Two flexible circuits enclose a Velostat film, and an Arduino Nano readout streams synchronized data at 100 Hz.
FlexiTac-V2

Technical specifications

Sensing capabilities and principle

Direct sensing
Normal contact pressure distribution
Sensing method
FPC–Velostat–FPC
Sensing principle
Piezoresistive
Measurement resolution
2 mm
Force range · approximate
Approx. 0.2–10 N
Signal frequency · Pressure
23 Hz

Structure and dimensions

Mounting position
Gripper fingertips
Physical form
Flexible tactile pad
Physical taxels
384
Sensing layout
Passive row-column matrix

Output and communication

Communication interface
USB serial
Connector
0.5 mm-pitch FFC
Connector
32-pin + 16-pin FFC (32 × 16 reader)
Connector
Mini-USB (host)
Connector
FPC1 pins 1–16: SR1–SR16; FPC2 pins 1–32: SC1–SC32
Data output
Per-taxel digital readings

Physical specifications and power

Mounting or wearing method
Pad mounted on the contact face of a soft fin-shaped finger

Software, export and openness

License and usage terms
CC BY-NC 4.0
License and usage terms
CC BY-NC 4.0
License and usage terms
CC BY-NC 4.0
License and usage terms
MIT

Other technical parameters

Record type
Research hardware project
Other technical parameter
Array 12 × 32
Other technical parameter
Pad thickness <1 mm
Other technical parameter
Arduino Nano
Other technical parameter
Nominal pad region 24 mm × 64 mm
Other technical parameter
Routed electrode field 23 mm × 63 mm
Other technical parameter
Polyimide stiffener 0.2 mm
Other technical parameter
FPC thickness 0.2 mm
Other technical parameter
Gold finger thickness 0.3 mm
Other technical parameter
32 × 16 readout board internal Arduino Nano rail +5 V
Other technical parameter
32 × 16 readout board schematic Rev 1.0

Communication and control

Calibration method
Pad-to-gripper rigid transform

Development and Expansion

Secondary Development (SDK)
PyFlexiTac 0.3.1

Commercial Status

Status
Prototype
Price
Unknown
Release Date
Mar 2026

Timeline

  1. Robot release
    FlexiTac-V2
Submit a source or correction